Compare commits
| Author | SHA1 | Date | |
|---|---|---|---|
 just-some-entity |
cae322f312 | ||
|
just-some-entity
|
7eeb18af94 | ||
|
Christian
|
093663c4e6 | ||
|
Christian
|
1b2d6df459 | ||
|
Christian
|
cd2e15cb29 | ||
|
Christian
|
f1571c0daa | ||
|
Christian
|
96e0fb83ef | ||
|
Christian
|
94cffbf717 | ||
|
EinsPommes
|
38b2e907f9 | ||
|
ᴏxᴏ.ᴍɪᴋᴀ
|
7e5498751a | ||
|
Christian
|
eef9d63de2 | ||
|
Christian
|
d9d9b9d344 | ||
|
Christian
|
2ff3d8df56 | ||
|
Christian
|
462672bb6a | ||
|
dependabot[bot]
|
84d539a4fa | ||
|
Robin Krämer
|
850b2d411d | ||
|
kraemr
|
008efe6ba1 | ||
|
Robin KrämerandOshgnacknak
|
3bd248b9fe | ||
|
Oshgnacknak
|
d73cfe7a02 | ||
|
EinsPommes
|
6a6c09e283 | ||
|
dependabot[bot]
|
6d2279d44b | ||
|
Oshgnacknak
|
61b9ac8a39 | ||
|
Oshgnacknak
|
728dd6eb26 | ||
|
Hans Sebastian Pöhlmann
|
742fd35d5f | ||
|
Milan von dem Bussche
|
5e1126e896 | ||
|
Milan von dem Bussche
|
e91719f902 | ||
|
Milan von dem Bussche
|
0efa9bcb07 | ||
|
Milan von dem Bussche
|
37d897d240 | ||
|
Robin Krämer
|
7488e1d97a | ||
|
Christian
|
bb169e3b33 | ||
|
Christian
|
3d735f8abd | ||
|
Christian
|
0a87e45901 | ||
|
Renosch
|
6205189b14 | ||
|
Renosch
|
9d7da4f0af | ||
|
Renosch
|
241b24be43 | ||
|
Renosch
|
aa77d12879 | ||
|
Renosch
|
78f183a8e5 | ||
|
Renosch
|
9f6fc8184e | ||
|
Renosch
|
ec3bdcb1df | ||
|
Renosch
|
30292650bc | ||
|
Renosch
|
1e9bcf9b19 | ||
|
Robin Krämer
|
1e88979ced | ||
|
Christian
|
a9a973e336 | ||
|
Oshgnacknak
|
1112fbaae2 | ||
|
Oshgnacknak
|
1abe0bbbdb | ||
|
Oshgnacknak
|
3644d16cb5 | ||
|
Christian
|
cbd82ee7c3 | ||
|
Christian
|
b66a59dba9 | ||
|
Christian
|
9dbc962dbc | ||
|
Christian
|
93e2558803 | ||
|
Christian
|
8cf7480833 | ||
|
Christian
|
08d655effc | ||
|
Christian
|
c1c867fca1 | ||
|
Hamid-el
|
1378c00e1a | ||
|
Hamid-el
|
85f17befbe | ||
|
Hamid-el
|
f2e764f93a | ||
|
Hamid-el
|
9adeeda490 | ||
|
Hamid-el
|
68bf075172 | ||
|
Hamid-el
|
7d23190939 | ||
|
Hamid-el
|
5c68e2c78a | ||
|
Hamid-el
|
980e14a96e | ||
|
Hamid-el
|
d5fb45e4e3 | ||
|
Hamid-el
|
cdb7ab1e0c | ||
|
Hamid-el
|
da934e0bb3 | ||
|
Christian
|
06ea89d500 | ||
|
Christian
|
0868a90513 | ||
|
Christian
|
39fb295b02 | ||
|
Christian
|
85dbae7458 | ||
|
Christian
|
6ce2174e25 | ||
|
Christian
|
3ccaa1cd26 | ||
|
Christian
|
72fec6dc9e | ||
|
Christian
|
547e4ac2bd | ||
|
Robin Krämer
|
5fbdf7b9ab | ||
|
kraemr
|
85bd4b0d96 | ||
|
kraemr
|
dfce760521 | ||
|
kraemr
|
30c97bf9aa | ||
|
Oshgnacknak
|
2c8373adcf | ||
|
kraemr
|
d08972254c | ||
|
Christian
|
a76d39e0cd | ||
|
Christian
|
a74d0dbb80 | ||
|
Christian
|
17ab24739d | ||
|
Christian
|
09f0ea3454 | ||
|
Christian
|
0dd2494ea0 | ||
|
Oshgnacknak
|
502c6d010e | ||
|
Robin Krämer
|
57c1cda229 | ||
|
Oshgnacknak
|
8c2b20b148 | ||
|
Oshgnacknak
|
12e7f245ce | ||
|
Oshgnacknak
|
671e36fa0f | ||
|
Oshgnacknak
|
1ffd7eade6 | ||
|
Oshgnacknak
|
703bbfc9e6 | ||
|
Oshgnacknak
|
057afb0b2e | ||
|
Robin Krämer
|
94bd29c734 | ||
|
Oshgnacknak
|
d078b7b143 | ||
|
dependabot[bot]
|
acbeb98f4f | ||
|
Robin Krämer
|
cab8bf062d | ||
|
kraemr
|
9e04a7fa33 | ||
|
Robin Krämer
|
c92d4847ca | ||
|
kraemr
|
aceeaa08c2 | ||
|
kraemr
|
35946d0c88 | ||
|
Oshgnacknak
|
e864a91caa | ||
|
Oshgnacknak
|
a5b9a0b1d5 | ||
|
Oshgnacknak
|
412d625138 | ||
|
Oshgnacknak
|
1ec20074e9 | ||
|
|
4d796f8422 | ||
|
Robin Krämer
|
1406d6c724 | ||
|
rob
|
33441b95a5 | ||
|
kraemr
|
8a3f312675 | ||
|
Robin Krämer
|
5c327428d6 | ||
|
rob
|
4e4d31cad1 | ||
|
rob
|
031fdf25a9 | ||
|
Oshgnacknak
|
857cda1455 | ||
|
OshgnacknakandThomas Symalla
|
de5f3a5cfc | ||
|
Oshgnacknak
|
2da7af522c | ||
|
Robin Krämer
|
712284e2f0 | ||
|
rob
|
402c47a81b | ||
|
rob
|
54a000a280 | ||
|
rob
|
41fe118144 | ||
|
rob
|
aaa6ff604f | ||
|
rob
|
a350bb378f | ||
|
rob
|
aa2212820e | ||
|
Robin Krämer
|
578e70119d | ||
|
dependabot[bot]
|
e8796e00af | ||
|
Christian
|
735f27770a | ||
|
Christian
|
700a255157 | ||
|
nixos-install.sh
|
ec06275c08 | ||
|
nixos-install.sh
|
11d0c8bb53 | ||
|
nixos-install.sh
|
535f24f1d1 | ||
|
nixos-install.sh
|
172913d8ec | ||
|
nixos-install.sh
|
0f99c54587 | ||
|
nixos-install.sh
|
f89d70c5f6 | ||
|
Oshgnacknak
|
0fc070be69 | ||
|
Oshgnacknak
|
b93eaf530e | ||
|
Oshgnacknak
|
76d8504651 | ||
|
Oshgnacknak
|
06acd43ff9 | ||
|
Oshgnacknak
|
870090c950 | ||
|
Oshgnacknak
|
65777f10ab | ||
|
Oshgnacknak
|
67d145de56 | ||
|
93094049+kraemr@users.noreply.github.com
|
d45d1ed01a | ||
|
93094049+kraemr@users.noreply.github.com
|
0d6c7bc0a5 | ||
|
93094049+kraemr@users.noreply.github.com
|
15f013f710 | ||
|
93094049+kraemr@users.noreply.github.com
|
a32e26a041 | ||
|
93094049+kraemr@users.noreply.github.com
|
41c7e1f74e | ||
|
93094049+kraemr@users.noreply.github.com
|
5a856e6e2b | ||
|
93094049+kraemr@users.noreply.github.com
|
8ca16d447e | ||
|
93094049+kraemr@users.noreply.github.com
|
b99549895b | ||
|
Christian
|
07cbaa4518 | ||
|
Oshgnacknak
|
c78f5ff5a0 | ||
|
nixos-install.sh
|
33946a6fa3 | ||
|
Milan von dem Bussche
|
02dc67bb85 | ||
|
Christian
|
b5ae86b19c | ||
|
Christian
|
35567b967f | ||
|
Hamid-el
|
c45718e670 | ||
|
Hamid-el
|
74dcd027e0 | ||
|
Oshgnacknak
|
c793d3fa50 | ||
|
Snacj
|
04fdc8a9d1 | ||
|
Oshgnacknak
|
fd702ff0bc | ||
|
Hamid-el
|
f25bf71753 | ||
|
Hamid-el
|
4c33873095 | ||
|
Hamid-el
|
8dbcb5efc3 | ||
|
Hamid-el
|
36426aafe0 | ||
|
Hamid-el
|
21cf9314be | ||
|
Hamid-el
|
4f2af7b90d | ||
|
Hamid-el
|
06795dcf78 | ||
|
Hamid-el
|
1241d0a4a7 | ||
|
Oshgnacknak
|
f36723f435 | ||
|
ChristianandCopilot
|
e96854a6bc | ||
|
Christian
|
04c5a673da | ||
|
Oshgnacknak
|
40e17ef5f1 | ||
|
Christian
|
39200aac12 | ||
|
Christian
|
43a405eec4 | ||
|
Christian
|
0206a4ddca | ||
|
Christian
|
34da7178f8 | ||
|
Christian
|
2726c47280 | ||
|
Christian
|
63cf25b3d6 | ||
|
Christian
|
eae13207e4 | ||
|
Oshgnacknak
|
f65d100cd5 | ||
|
ThatsMe
|
13e4ea1ac7 | ||
|
ᴏxᴏ.ᴍɪᴋᴀ
|
49788246c8 | ||
|
Christian
|
d4e849d588 | ||
|
Christian
|
2689d19928 | ||
|
Christian
|
968e9327f6 | ||
|
Christian
|
3cbb74b3b0 | ||
|
Christian
|
50fcfd6e30 | ||
|
Christian
|
ce0f27787c | ||
|
Christian
|
08ab7fd404 | ||
|
Christian
|
f138b61a45 | ||
|
Christian
|
0ad0a58d46 | ||
|
MLobsien
|
2d2415a801 | ||
|
MLobsien
|
b4cce1dba4 | ||
|
MLobsien
|
f80cdb05d5 | ||
|
MLobsien
|
f24f31259b | ||
|
EinsPommes
|
3d13e6cee2 | ||
|
EinsPommes
|
86915c2987 | ||
|
MLobsien
|
6411f9ff80 | ||
|
EinsPommes
|
ada8d0f12c | ||
|
EinsPommes
|
735456b6eb | ||
|
EinsPommes
|
b46a528adb | ||
|
EinsPommes
|
80f2343a60 | ||
|
EinsPommes
|
e030fbe23e | ||
|
Oshgnacknak
|
1ef0cb608c | ||
|
Christian
|
789a84e511 | ||
|
ChristianandCopilot
|
28620b6a23 | ||
|
Christian
|
01609513fb | ||
|
Christian
|
379a4ec417 | ||
|
MLobsien
|
8b462d5a1d | ||
|
JalleliAchraf
|
d8a0039db3 | ||
|
Achraf Jalleli
|
dec8ea481c | ||
|
EinsPommes
|
0c8b8388d0 | ||
|
MLobsien
|
d3a56710d6 | ||
|
MLobsien
|
f9f67d3309 | ||
|
MLobsien
|
66122ad957 | ||
|
MLobsien
|
95feaf46bf | ||
|
MLobsien
|
88f14e0329 | ||
|
15i1i-s7v
|
5bf19af844 | ||
|
MLobsien
|
19e2a337cf | ||
|
MLobsien
|
0fd47cfcb1 | ||
|
15i1i-s7v
|
e0548d9a65 | ||
|
15i1i-s7v
|
259ed30dd5 | ||
|
MLobsien
|
2e028f0c0f | ||
|
MLobsien
|
1328c6ce03 | ||
|
Robin Krämer
|
28d898e780 | ||
|
dependabot[bot]
|
daabb170f5 | ||
|
MLobsien
|
adc06623cd | ||
|
Robin Krämer
|
c4803e63dd | ||
|
rob
|
0022d86035 | ||
|
MLobsien
|
172ad0ab28 | ||
|
MLobsien
|
bfabb5aa13 | ||
|
15i1i-s7v
|
94d5a844cf | ||
|
MLobsien
|
75c528a430 | ||
|
MLobsien
|
36045455db | ||
|
15i1i-s7v
|
bb12f96723 | ||
|
15i1i-s7v
|
8151c99944 | ||
|
MLobsien
|
6408010aff | ||
|
MLobsien
|
c96c96217a | ||
|
MLobsien
|
93d179a81d | ||
|
15i1i-s7v
|
0f6f2240fc | ||
|
15i1i-s7v
|
74505c6c22 | ||
|
15i1i-s7v
|
3dfb879101 | ||
|
Hans Sebastian Pöhlmann
|
dc711a820f | ||
|
MLobsien
|
44d4c650cc | ||
|
MLobsien
|
3121679205 | ||
|
MLobsien
|
9fe5e582b0 | ||
|
MLobsien
|
3e6b838757 | ||
|
Robin Krämer
|
59cf2cea2a | ||
|
MLobsien
|
3d7bcfecca | ||
|
Snacj
|
da69ad1c3e | ||
|
Snacj
|
6ff434fb47 | ||
|
Snacj
|
a63c57a0b9 | ||
|
Snacj
|
21c43adcb4 | ||
|
snacj
|
afa23666e2 | ||
|
snacj
|
245ad64426 | ||
|
snacj
|
9665971150 | ||
|
snacj
|
3b056c8f26 | ||
|
snacj
|
62b35e0237 | ||
|
snacj
|
11bc62f40e | ||
|
snacj
|
116c76d218 | ||
|
snacj
|
4dcedb537d | ||
|
snacj
|
09022c9c86 | ||
|
snacj
|
80cf98b11d | ||
|
snacj
|
644e750353 | ||
|
Robin Krämer
|
aecabfde43 | ||
|
Oshgnacknak
|
686678a1fe | ||
|
Oshgnacknak
|
7ac0b788c2 | ||
|
Snacj
|
3791ee785d | ||
|
snacj
|
7341dee976 | ||
|
MLobsien
|
63a472a1ba | ||
|
MLobsien
|
df6b9e72c0 | ||
|
MLobsien
|
6ad4b9c8bb | ||
|
15i1i-s7v
|
4fcc8dfe12 | ||
|
MLobsien
|
1da64c9cea | ||
|
MLobsien
|
9b6912be8d | ||
|
15i1i-s7v
|
3beed9478c | ||
|
15i1i-s7v
|
3715728fc6 | ||
|
MLobsien
|
5beee78cad | ||
|
MLobsien
|
32fe774e62 | ||
|
MLobsien
|
dead77b49c | ||
|
MLobsien
|
d7aa976eb1 | ||
|
15i1i-s7v
|
6f9e89d616 | ||
|
MLobsien
|
bb3f6c0d5a | ||
|
15i1i-s7v
|
620974ac59 | ||
|
15i1i-s7v
|
6c78ff95e4 | ||
|
15i1i-s7v
|
a814236bfa | ||
|
MLobsien
|
2bee030410 | ||
|
Hamid-el
|
285ad59b08 | ||
|
Hamid-el
|
f8b861cb39 | ||
|
MLobsien
|
f6a3aa6458 | ||
|
MLobsien
|
dd5f3e8e73 | ||
|
EinsPommes
|
f50e32af02 | ||
|
MLobsien
|
345e083edd | ||
|
MLobsien
|
5660ddd05f | ||
|
rob
|
c4360850af | ||
|
rob
|
ce2123c88c | ||
|
Christian
|
520f33bf29 | ||
|
Christian
|
c620f1db7f | ||
|
Christian
|
d352e88d6f | ||
|
EinsPommes
|
cc009b31f3 | ||
|
EinsPommes
|
b5c189ab49 | ||
|
EinsPommes
|
64f57277f2 | ||
|
EinsPommes
|
af8ee60fe8 | ||
|
EinsPommes
|
beb2e3cc2d | ||
|
EinsPommes
|
0e2bcfd7bc | ||
|
EinsPommes
|
417ffb23c2 | ||
|
EinsPommes
|
a57d4cdf36 | ||
|
Robin Krämer
|
b8168c6b43 | ||
|
rob
|
6026d2a658 | ||
|
Achraf Jalleli
|
a301f3e228 | ||
|
JalleliAchraf
|
0b6bd68a24 | ||
|
Christian
|
e7fd390263 | ||
|
JalleliAchraf
|
eab675795a | ||
|
Christian
|
8c2dc9a507 | ||
|
Robin Krämer
|
f6c0744efa | ||
|
rob
|
8c7e810359 | ||
|
Christian
|
f0fd9e8ce6 | ||
|
Christian
|
c5579a4471 | ||
|
Christian
|
de7a65bf12 | ||
|
rob
|
e4d0b3c5be | ||
|
Robin Krämer
|
dad029ab0d | ||
|
EinsPommes
|
9c780799d1 | ||
|
EinsPommes
|
27a33f9def | ||
|
Robin Krämer
|
f44cd029f9 | ||
|
EinsPommes
|
9abb7629fb | ||
|
EinsPommes
|
a161d85a63 | ||
|
EinsPommes
|
9df9e6df4a | ||
|
EinsPommes
|
29d465c13e | ||
|
EinsPommes
|
622c94f2d9 | ||
|
EinsPommes
|
f31a2789ca | ||
|
Robin Krämer
|
e7632e8d1b | ||
|
Achraf Jalleli
|
2f4f3de32a | ||
|
Achraf Jalleli
|
c9f49198c7 | ||
|
Achraf Jalleli
|
e2c12a0168 | ||
|
Achraf Jalleli
|
cb6e066512 | ||
|
Achraf Jalleli
|
1dd0421f96 | ||
|
Achraf Jalleli
|
64855f2e7a | ||
|
Achraf Jalleli
|
855ae7b3cf | ||
|
Robin Krämer
|
5f9a8605c9 | ||
|
rob
|
567730a8d4 | ||
|
rob
|
6b2164b88b | ||
|
rob
|
930ea10409 | ||
|
Robin Krämer
|
24b703e262 | ||
|
JalleliAchraf
|
152dd3efa0 | ||
|
Milan von dem Bussche
|
ebc5bae55f | ||
|
Robin Krämer
|
88214c46a8 | ||
|
rob
|
c9485a92e9 | ||
|
rob
|
9df42c4d13 | ||
|
rob
|
fc9a439ae8 | ||
|
rob
|
e451153406 | ||
|
rob
|
500e2fe481 | ||
|
rob
|
a5884d93e7 | ||
|
rob
|
d2e32cdd78 | ||
|
rob
|
f66c6d4f65 | ||
|
Oshgnacknak
|
fb85cc6db7 | ||
|
Robin Krämer
|
4e128ded36 | ||
|
Oshgnacknak
|
f50388b141 | ||
|
ChristianandCopilot
|
4025a68fe1 | ||
|
ChristianandCopilot
|
7a05fa206f | ||
|
Christian
|
8594b06c3b | ||
|
Christian
|
17523574d8 | ||
|
Christian
|
7971797178 | ||
|
Christian
|
a8b0837e58 | ||
|
Oshgnacknak
|
e419974844 | ||
|
Oshgnacknak
|
773d0f6c15 | ||
|
Oshgnacknak
|
afc4e0d8b4 | ||
|
Robin Krämer
|
5e86988ac4 | ||
|
snacj
|
2d28c18b1a | ||
|
snacj
|
b19764281a | ||
|
snacj
|
c25d63f781 | ||
|
Robin Krämer
|
d79efc412f | ||
|
rob
|
7ad74cf089 | ||
|
rob
|
6073d37892 | ||
|
rob
|
c04937553f | ||
|
rob
|
e08bdfa3c7 | ||
|
rob
|
d282678b19 | ||
|
Robin Krämer
|
9ff4243350 | ||
|
rob
|
6c79b33752 | ||
|
rob
|
861b5da7a3 | ||
|
Robin Krämer
|
7dd3d50653 | ||
|
kraemr
|
ba8e04c641 | ||
|
kraemr
|
cece245a55 | ||
|
kraemr
|
fab4d2810e | ||
|
Robin Krämer
|
5bff3ca929 | ||
|
kraemr
|
afe1d3b80e | ||
|
kraemr
|
6c8005dba9 | ||
|
kraemr
|
9f399ca6f3 | ||
|
kraemr
|
a7574dd348 | ||
|
kraemr
|
b39f3597c8 | ||
|
Robin Krämer
|
bb9a86d52e | ||
|
kraemr
|
e5329e40c6 | ||
|
kraemr
|
319611f69d | ||
|
Robin Krämer
|
4b16253c8c | ||
|
kraemr
|
b60423fde6 | ||
|
kraemr
|
5d3399c72e | ||
|
kraemr
|
d247bafcbb | ||
|
kraemr
|
5227aad4c6 | ||
|
kraemr
|
da4c54a99e | ||
|
kraemr
|
8d42bd93f7 | ||
|
kraemr
|
37e467272b | ||
|
Oshgnacknak
|
ed0b9cd5ae | ||
|
Oshgnacknak
|
8045f799f0 | ||
|
Robin Krämer
|
ca6ea16f89 | ||
|
snacj
|
452614abf1 | ||
|
snacj
|
f63c797cd1 | ||
|
snacj
|
de791f6ea8 | ||
|
Robin Krämer
|
024f751ef1 | ||
|
kraemr
|
d4c82bfd7d | ||
|
Robin Krämer
|
a49f19133d | ||
|
snacj
|
a94009514c | ||
|
Snacj
|
d1d3724f52 | ||
|
Snacj
|
9f4177aff9 | ||
|
Snacj
|
e323fd76f8 | ||
|
Snacj
|
b0d24d8502 | ||
|
Snacj
|
8ae20c2aae | ||
|
Snacj
|
89843514b8 | ||
|
Robin Krämer
|
1a9e39a49e | ||
|
Christian
|
f4d5e74c59 | ||
|
Oshgnacknak
|
eb1301df99 | ||
|
Oshgnacknak
|
2885fa91cc | ||
|
dependabot[bot]
|
d89e4681db | ||
|
Oshgnacknak
|
dedcd76241 | ||
|
Oshgnacknak
|
e987dd07f9 | ||
|
dependabot[bot]
|
6747433100 | ||
|
Robin Krämer
|
3ffd67918c | ||
|
Snacj
|
3fe6556037 | ||
|
snacj
|
5ccc65241d | ||
|
Robin Krämer
|
be92fd0665 | ||
|
Snacj
|
8a6d4d1385 | ||
|
Robin Krämer
|
13117a5d94 | ||
|
kraemr
|
6b74c7ec7a | ||
|
kraemr
|
e8b561f722 | ||
|
Robin Krämer
|
75ee5af180 | ||
|
kraemr
|
29f924f6cc | ||
|
kraemr
|
6e058c8e95 | ||
|
Robin Krämer
|
6822da80cf | ||
|
dependabot[bot]
|
37e3302f61 | ||
|
Robin Krämer
|
9b369d71ee | ||
|
dependabot[bot]
|
cf58f0db6f | ||
|
Robin Krämer
|
299f23c796 | ||
|
kraemr
|
b58e4333a0 | ||
|
kraemr
|
f76cb9c381 | ||
|
kraemr
|
e93e10d14d | ||
|
kraemr
|
025464ebff | ||
|
kraemr
|
ae8f77f070 | ||
|
Robin Krämer
|
97811a12d1 | ||
|
kraemr
|
1f7e01820a | ||
|
Robin Krämer
|
2f73771bbd | ||
|
Christian
|
503ac18e7b | ||
|
Christian
|
6a99b21c15 | ||
|
Christian
|
170667f2b4 | ||
|
Robin Krämer
|
314b7f2484 | ||
|
Christian
|
9353b12707 | ||
|
Christian
|
063810f906 | ||
|
Christian
|
ac7ce126e6 | ||
|
Christian
|
a920830dcf | ||
|
Christian
|
15d74fcee0 | ||
|
Robin Krämer
|
c598e3fc9f | ||
|
snacj
|
0dba0f2774 | ||
|
snacj
|
e2cdb6a94c | ||
|
snacj
|
5dd2011e78 | ||
|
snacj
|
7bc142dc83 | ||
|
snacj
|
1931f00806 | ||
|
snacj
|
253336b02c | ||
|
snacj
|
b0c3a97f7f | ||
|
snacj
|
22887d4f7a | ||
|
Robin Krämer
|
00dbc90c85 | ||
|
kraemr
|
9ade1d8993 | ||
|
Robin Krämer
|
b2fb803033 | ||
|
nixos-install.sh
|
988ed5b959 | ||
|
Oshgnacknak
|
2e62f99724 | ||
|
Oshgnacknak
|
530327b1e8 | ||
|
Robin Krämer
|
2f75b31fa9 | ||
|
kraemr
|
ce8f0a8c4b | ||
|
Robin Krämer
|
321aae5b86 | ||
|
kraemr
|
7712ea2d1f | ||
|
Robin Krämer
|
175f64f784 | ||
|
ChristianandCopilot
|
9357960463 | ||
|
Christian
|
4d043906bc | ||
|
Christian
|
b99b7f796b | ||
|
Christian
|
a7b0414613 | ||
|
Christian
|
13c608b11a | ||
|
Oshgnacknak
|
d14fb91736 | ||
|
Oshgnacknak
|
6beaa444af | ||
|
Oshgnacknak
|
3b552558d4 | ||
|
Robin Krämer
|
9cc63bf8fb | ||
|
Oshgnacknak
|
70ce7625b2 | ||
|
Robin Krämer
|
9936764125 | ||
|
Christian
|
a0f09e1671 | ||
|
Christian
|
1100b880f9 | ||
|
Christian
|
6224f33ba5 | ||
|
Christian
|
b0a9b5a6d2 | ||
|
ChristianandCopilot
|
ac7247c87a | ||
|
Christian
|
2ea459f3be | ||
|
Christian
|
25250f640f | ||
|
Robin Krämer
|
57a0cc8af4 | ||
|
Christian
|
5ebb978eae | ||
|
Christian
|
d647ee6ebe | ||
|
Christian
|
fea203ae7a | ||
|
Robin Krämer
|
b5eb413d37 | ||
|
Christian
|
aa1e5c4f39 | ||
|
Christian
|
ee91934bf7 | ||
|
Milan von dem Bussche
|
1fa04eae9a | ||
|
Robin Krämer
|
98e1269f6f | ||
|
kraemr
|
8f640fcb21 | ||
|
Robin Krämer
|
6c120b7fe9 | ||
|
kraemr
|
033b93b9da | ||
|
kraemr
|
6092358e87 | ||
|
Robin Krämer
|
71de39e871 | ||
|
joe
|
54ffa193c3 | ||
|
joe
|
03164f1ceb | ||
|
Robin Krämer
|
f67a46ab4c | ||
|
kraemr
|
610790a778 | ||
|
Robin Krämer
|
6eaf451ad4 | ||
|
JanHBade
|
022e0adae3 | ||
|
Robin Krämer
|
6e6d4b31e7 | ||
|
Christian
|
0dafad3fb5 | ||
|
Christian
|
534de55239 | ||
|
Christian
|
d9f92bcdf2 | ||
|
Robin Krämer
|
1570299e38 | ||
|
kraemr
|
c95f6f3bd9 | ||
|
Robin Krämer
|
9fcde2a234 | ||
|
kraemr
|
a2ffc41e05 | ||
|
Robin Krämer
|
ff13baf257 | ||
|
kraemr
|
8f5df07c19 | ||
|
Robin Krämer
|
299b38515a | ||
|
kraemr
|
2b073aeb76 | ||
|
Robin Krämer
|
7a6f92f8a4 | ||
|
Christian
|
2e283ea95f | ||
|
Robin Krämer
|
829bb5ea1c | ||
|
Oshgnacknak
|
0be18aaed0 | ||
|
Oshgnacknak
|
ffe0f09061 | ||
|
nixos-install.sh
|
730d61a18d | ||
|
Oshgnacknak
|
fc07525976 | ||
|
Oshgnacknak
|
c48953aa6b | ||
|
Melvin Spieß
|
0c948b436d | ||
|
Robin Krämer
|
1b3f92dd1c | ||
|
dependabot[bot]
|
c29c549a1c | ||
|
kraemr
|
17622cacde | ||
|
kraemr
|
0b423454ec | ||
|
kraemr
|
81ec98f670 | ||
|
93094049+kraemr@users.noreply.github.com
|
1aed425544 | ||
|
93094049+kraemr@users.noreply.github.com
|
da080ace68 | ||
|
93094049+kraemr@users.noreply.github.com
|
ded8dd2d2d | ||
|
93094049+kraemr@users.noreply.github.com
|
edd83ba559 | ||
|
Melvin Spieß
|
7d1d8559a5 | ||
|
kraemr
|
f0bb9bfed1 | ||
|
93094049+kraemr@users.noreply.github.com
|
c6ea057736 | ||
|
93094049+kraemr@users.noreply.github.com
|
90a00198a7 | ||
|
Melvin Spieß
|
f8241547fe | ||
|
Melvin Spieß
|
1cb5d51c13 | ||
|
Melvin Spieß
|
c42cdf8db1 | ||
|
Melvin Spieß
|
69014ef8c6 | ||
|
Melvin Spieß
|
5faab29a2b | ||
|
dependabot[bot]
|
9a8b16ca69 | ||
|
Melvin Spieß
|
53f3c66214 | ||
|
dependabot[bot]
|
432bf0d6ba | ||
|
dependabot[bot]
|
f3990f35f1 | ||
|
dependabot[bot]
|
6f17412363 | ||
|
dependabot[bot]
|
68907b9750 | ||
|
dependabot[bot]
|
e7007e1980 | ||
|
Melvin Spieß
|
3bcd96d73c | ||
|
dependabot[bot]
|
8a77c62a5e | ||
|
kraemr
|
93add82ab5 | ||
|
Robin Krämer
|
690b1f7ab3 | ||
|
kraemr
|
3c07b94e3a | ||
|
Robin Krämer
|
3b63b55859 |
No files matched your search
@@ -3,50 +3,73 @@ name: Electron
|
||||
on:
|
||||
push:
|
||||
branches:
|
||||
- "**"
|
||||
- master
|
||||
pull_request:
|
||||
branches:
|
||||
- "*"
|
||||
- master
|
||||
|
||||
defaults:
|
||||
run:
|
||||
working-directory: electron
|
||||
|
||||
jobs:
|
||||
build-electron:
|
||||
build:
|
||||
runs-on: ubuntu-latest
|
||||
defaults:
|
||||
run:
|
||||
working-directory: electron
|
||||
|
||||
steps:
|
||||
- name: Setup Node.js
|
||||
- &checkout
|
||||
name: Checkout
|
||||
uses: actions/checkout@v4
|
||||
|
||||
- &setup-node
|
||||
name: Setup Node.js
|
||||
uses: actions/setup-node@v4
|
||||
with:
|
||||
node-version: "18" # or '20' for latest LTS
|
||||
node-version: 20
|
||||
cache: "npm"
|
||||
cache-dependency-path: |
|
||||
electron/package-lock.json
|
||||
|
||||
- uses: actions/checkout@v4
|
||||
- &install
|
||||
name: Install dependencies
|
||||
run: npm ci
|
||||
|
||||
- name: Cache NPM dependencies
|
||||
uses: actions/cache@v3
|
||||
with:
|
||||
path: |
|
||||
~/.npm
|
||||
node_modules/
|
||||
key: ${{ runner.os }}-npm-${{ hashFiles('**/package-lock.json') }}
|
||||
restore-keys: |
|
||||
${{ runner.os }}-npm-
|
||||
|
||||
- name: Install
|
||||
run: npm i
|
||||
|
||||
- name: Build
|
||||
- name: Compile
|
||||
run: tsc
|
||||
|
||||
- name: Format
|
||||
run: npm run format
|
||||
- name: Build
|
||||
run: npm run build
|
||||
|
||||
- name: Lint
|
||||
run: npm run lint
|
||||
test:
|
||||
runs-on: ubuntu-latest
|
||||
needs: build
|
||||
|
||||
steps:
|
||||
- *checkout
|
||||
- *setup-node
|
||||
- *install
|
||||
|
||||
- name: Test
|
||||
run: npm run test
|
||||
|
||||
- name: Package
|
||||
run: npm run package
|
||||
format:
|
||||
runs-on: ubuntu-latest
|
||||
|
||||
steps:
|
||||
- *checkout
|
||||
- *setup-node
|
||||
- *install
|
||||
|
||||
- name: Format
|
||||
run: npm run format
|
||||
|
||||
lint:
|
||||
runs-on: ubuntu-latest
|
||||
|
||||
steps:
|
||||
- *checkout
|
||||
- *setup-node
|
||||
- *install
|
||||
|
||||
- name: Lint
|
||||
run: npm run lint
|
||||
@@ -0,0 +1,96 @@
|
||||
name: Nix CI
|
||||
|
||||
on:
|
||||
push:
|
||||
branches:
|
||||
- master
|
||||
pull_request:
|
||||
branches:
|
||||
- master
|
||||
|
||||
env:
|
||||
NIX_PATH: nixpkgs=channel:nixos-25.05
|
||||
|
||||
jobs:
|
||||
electron:
|
||||
runs-on: ubuntu-latest
|
||||
|
||||
steps:
|
||||
- &checkout
|
||||
name: Check out repository
|
||||
uses: actions/checkout@v4
|
||||
|
||||
- &nix-install
|
||||
uses: nixbuild/nix-quick-install-action@v34
|
||||
with:
|
||||
nix_conf: |
|
||||
keep-env-derivations = true
|
||||
keep-outputs = true
|
||||
|
||||
- uses: nix-community/cache-nix-action@v6
|
||||
with:
|
||||
primary-key: nix-electron-${{ runner.os }}-${{ hashFiles('**/*.nix', '**/flake.lock', './electron/package-lock.json') }}
|
||||
restore-prefixes-first-match: nix-${{ runner.os }}-
|
||||
purge: true
|
||||
purge-prefixes: nix-electron-${{ runner.os }}-
|
||||
|
||||
- name: Build Electron in Nix
|
||||
run: nix build ".#packages.x86_64-linux.electron"
|
||||
|
||||
rust:
|
||||
runs-on: ubuntu-latest
|
||||
|
||||
steps:
|
||||
- *checkout
|
||||
- *nix-install
|
||||
|
||||
- uses: nix-community/cache-nix-action@v6
|
||||
with:
|
||||
primary-key: nix-server-${{ runner.os }}-${{ hashFiles('**/*.nix', '**/flake.lock', './Cargo.lock') }}
|
||||
restore-prefixes-first-match: nix-${{ runner.os }}-
|
||||
purge: true
|
||||
purge-prefixes: nix-server-${{ runner.os }}-
|
||||
|
||||
- name: Build Server in Nix
|
||||
run: nix build ".#packages.x86_64-linux.server"
|
||||
|
||||
build:
|
||||
runs-on: ubuntu-latest
|
||||
needs: [electron, rust]
|
||||
|
||||
steps:
|
||||
- *checkout
|
||||
- *nix-install
|
||||
|
||||
- name: Use both Electron and Server Nix Store
|
||||
uses: nix-community/cache-nix-action@v6
|
||||
with:
|
||||
primary-key: nix-${{ runner.os }}-${{ hashFiles('**/*.nix', '**/flake.lock', './Cargo.lock', './electron/package-lock.json') }}
|
||||
|
||||
# if no hit on the primary key, merge individual caches
|
||||
restore-prefixes-all-matches: |
|
||||
nix-electron-${{ runner.os }}-
|
||||
nix-server-${{ runner.os }}-
|
||||
|
||||
- name: Build Flake and System Configuration
|
||||
run: nix build ".#nixosConfigurations.nixos.config.system.build.toplevel" --impure
|
||||
|
||||
format:
|
||||
runs-on: ubuntu-latest
|
||||
|
||||
steps:
|
||||
- *checkout
|
||||
- *nix-install
|
||||
|
||||
- name: Format
|
||||
run: nix run 'nixpkgs#nixfmt-classic' $(find . nixos -name '*.nix')
|
||||
|
||||
check:
|
||||
runs-on: ubuntu-latest
|
||||
|
||||
steps:
|
||||
- *checkout
|
||||
- *nix-install
|
||||
|
||||
- name: Build Flake and Configuration.nix
|
||||
run: nix flake check "." --impure
|
||||
@@ -3,9 +3,10 @@ name: Rust
|
||||
on:
|
||||
push:
|
||||
branches:
|
||||
- "**"
|
||||
- master
|
||||
pull_request:
|
||||
branches: "*"
|
||||
branches:
|
||||
- master
|
||||
|
||||
env:
|
||||
CARGO_TERM_COLOR: always
|
||||
@@ -16,14 +17,24 @@ jobs:
|
||||
runs-on: ubuntu-latest
|
||||
|
||||
steps:
|
||||
- name: Install libudev development package
|
||||
- &udev-install
|
||||
name: Install libudev development package
|
||||
run: sudo apt-get update && sudo apt-get install -y libudev-dev
|
||||
- uses: actions/checkout@v4
|
||||
- name: Set Rust version
|
||||
run: rustup override set ${{ env.RUST_VERSION }}
|
||||
- name: Install Formatter
|
||||
run: rustup component add rustfmt
|
||||
- name: Cache Rust dependencies
|
||||
|
||||
- &checkout
|
||||
uses: actions/checkout@v4
|
||||
|
||||
- &setup-rust
|
||||
name: Install Rust toolchain
|
||||
uses: actions-rs/toolchain@v1
|
||||
with:
|
||||
toolchain: ${{ env.RUST_VERSION }}
|
||||
profile: minimal
|
||||
override: true
|
||||
components: rustfmt
|
||||
|
||||
- &cargo-cache
|
||||
name: Cache Rust dependencies
|
||||
uses: actions/cache@v3
|
||||
with:
|
||||
path: |
|
||||
@@ -41,8 +52,36 @@ jobs:
|
||||
RUSTFLAGS: "-D warnings"
|
||||
run: cargo build --verbose
|
||||
|
||||
format:
|
||||
runs-on: ubuntu-latest
|
||||
|
||||
steps:
|
||||
- *checkout
|
||||
- *setup-rust
|
||||
|
||||
- name: Format
|
||||
run: cargo fmt --check --verbose
|
||||
|
||||
test:
|
||||
runs-on: ubuntu-latest
|
||||
|
||||
steps:
|
||||
- *udev-install
|
||||
- *checkout
|
||||
- *setup-rust
|
||||
- *cargo-cache
|
||||
|
||||
- name: Run tests
|
||||
run: cargo test --verbose
|
||||
|
||||
mock:
|
||||
runs-on: ubuntu-latest
|
||||
|
||||
steps:
|
||||
- *udev-install
|
||||
- *checkout
|
||||
- *setup-rust
|
||||
- *cargo-cache
|
||||
|
||||
- name: Mock Machine
|
||||
run: cargo build --features "development-build,mock-machine"
|
||||
@@ -3,3 +3,9 @@ dist/
|
||||
.DS_Store
|
||||
Cargo.lock
|
||||
dhat-heap.json
|
||||
build.sh
|
||||
shell.nix
|
||||
node_modules/
|
||||
runtime_metrics.csv
|
||||
compile_metrics.csv
|
||||
.idea/
|
||||
@@ -1,3 +1,116 @@
|
||||
# `2.14.1`
|
||||
_26.01.2026_
|
||||
|
||||
## Laser
|
||||
-[#1079](https://github.com/qitechgmbh/control/pull/1079) Fixed Overflowing of buffer for Graphs causing crashes
|
||||
|
||||
# `2.14.0`
|
||||
_22.01.2026_
|
||||
|
||||
## General
|
||||
- [#1040](https://github.com/qitechgmbh/control/pull/1040) Added API for reading Machine Data
|
||||
|
||||
# `2.13.0`
|
||||
_07.01.2026_
|
||||
|
||||
## General
|
||||
- [#925](https://github.com/qitechgmbh/control/pull/925) Switch to Setup when selected machine is disconnected
|
||||
- [#937](https://github.com/qitechgmbh/control/pull/937) Added minimal Support for WAGO
|
||||
- [#945](https://github.com/qitechgmbh/control/pull/945) Improvements for On-Screen Keyboard usage in Ethercat Setup Page
|
||||
|
||||
## Extruder V3
|
||||
- [#930](https://github.com/qitechgmbh/control/pull/930) Added Extruder V3
|
||||
|
||||
## Laser
|
||||
- [#924](https://github.com/qitechgmbh/control/pull/924) Roundness is now displayed as a percentage
|
||||
- [#885](https://github.com/qitechgmbh/control/pull/885) Added Min and Max Diameter
|
||||
- [#849](https://github.com/qitechgmbh/control/pull/849) Added a Warning if Filament is out of Spec
|
||||
|
||||
## Aquapath
|
||||
- [#976](https://github.com/qitechgmbh/control/pull/976) Improved Stability
|
||||
|
||||
|
||||
# `2.12.0`
|
||||
_17.11.2025_
|
||||
|
||||
## General
|
||||
- [#847](https://github.com/qitechgmbh/control/pull/847) Improved discovery and initialization
|
||||
- [#859](https://github.com/qitechgmbh/control/pull/859) Improved update speed
|
||||
- [#897](https://github.com/qitechgmbh/control/pull/897), [#899](https://github.com/qitechgmbh/control/pull/899), [#852](https://github.com/qitechgmbh/control/pull/852) Improved system stability
|
||||
- [#817](https://github.com/qitechgmbh/control/pull/817) Added an update bar
|
||||
|
||||
## Laser
|
||||
- [#857](https://github.com/qitechgmbh/control/pull/857) Fixed potential issues with 2 Axis Laser
|
||||
|
||||
## Extruder V2
|
||||
- [#881](https://github.com/qitechgmbh/control/pull/881) Extended Temperature PID Configuration
|
||||
|
||||
|
||||
# `2.11.0`
|
||||
_21.10.2025_
|
||||
|
||||
## General
|
||||
- [#829](https://github.com/qitechgmbh/control/pull/829), [#834](https://github.com/qitechgmbh/control/pull/834), Improved overall system stability
|
||||
|
||||
## Winder V2
|
||||
- [#840](https://github.com/qitechgmbh/control/pull/840) Added XL Winder option
|
||||
- [#827](https://github.com/qitechgmbh/control/pull/827) Spool can now be run in reverse
|
||||
|
||||
## Extruder V2
|
||||
- [#826](https://github.com/qitechgmbh/control/pull/826) Fine grained Temperature-PID configuration now possible
|
||||
|
||||
|
||||
# `2.10.0`
|
||||
_16.10.2025_
|
||||
|
||||
## Winder V2
|
||||
- [#776](https://github.com/qitechgmbh/control/pull/776) Added explanation for padding in winder manual
|
||||
- [#804](https://github.com/qitechgmbh/control/pull/804) Added gearbox conversion
|
||||
|
||||
## General
|
||||
- [#717](https://github.com/qitechgmbh/control/pull/717) Show from option for graphs added
|
||||
- [#805](https://github.com/qitechgmbh/control/pull/805) Graphs run better now
|
||||
|
||||
|
||||
|
||||
# `2.9.1`
|
||||
_10.10.2025_
|
||||
|
||||
## Winder V2
|
||||
- [#796](https://github.com/qitechgmbh/control/pull/796) Winding in adaptive mode, while puller is in reverse mode is now possible
|
||||
|
||||
## General
|
||||
- [#780](https://github.com/qitechgmbh/control/pull/780) Updates are faster now
|
||||
- [#746](https://github.com/qitechgmbh/control/pull/746) Improved scrollbar styling for manuals
|
||||
|
||||
# `2.9.0`
|
||||
_06.10.2025_
|
||||
|
||||
## Winder V2
|
||||
- [#778](https://github.com/qitechgmbh/control/pull/778) Increased Winder Traverse Step size limit
|
||||
|
||||
## General
|
||||
- [#725](https://github.com/qitechgmbh/control/pull/725) Improved troubleshooting and update page
|
||||
- [#625](https://github.com/qitechgmbh/control/pull/625) Improved stability of Machine-Connections
|
||||
|
||||
|
||||
# `2.8.0`
|
||||
_30.09.2025_
|
||||
|
||||
|
||||
## Laser V1
|
||||
- [#741](https://github.com/qitechgmbh/control/pull/741) Added roundness measurement to two-axis Laser
|
||||
|
||||
|
||||
## Winder V2
|
||||
- [#745](https://github.com/qitechgmbh/control/pull/745), [#756](https://github.com/qitechgmbh/control/pull/756) improved Winder Frontend
|
||||
|
||||
## General
|
||||
- [#447](https://github.com/qitechgmbh/control/pull/447) added AquaPath Machine
|
||||
|
||||
|
||||
|
||||
|
||||
# `2.7.0`
|
||||
|
||||
_17.09.2025_
|
||||
@@ -10,9 +123,9 @@ _17.09.2025_
|
||||
|
||||
- [#727](https://github.com/qitechgmbh/control/pull/727) Removed estimated diameter
|
||||
|
||||
## Laser V1/V2
|
||||
## Laser V1
|
||||
|
||||
- [#731](https://github.com/qitechgmbh/control/pull/731) Added LaserV2 with two-axis measurements
|
||||
- [#731](https://github.com/qitechgmbh/control/pull/731) Added Laser with two-axis measurements
|
||||
|
||||
## General
|
||||
|
||||
|
||||
@@ -4,8 +4,11 @@ members = [
|
||||
"ethercat-hal",
|
||||
"ethercat-hal-derive",
|
||||
"control-core",
|
||||
"ethercat-eeprom-dump",
|
||||
"machines",
|
||||
#"ethercat-eeprom-dump",
|
||||
"control-core-derive",
|
||||
"units",
|
||||
"utils",
|
||||
]
|
||||
exclude = []
|
||||
resolver = "2"
|
||||
|
||||
@@ -2,29 +2,37 @@
|
||||
|
||||
# QiTech Control
|
||||
|
||||
QiTech Control is an industrial control panel software for the next generation of QiTech recycling machines built on top of Beckhoff Automation hardware.
|
||||
QiTech Control is an open-source framework designed to bring modern software paradigms to certified industrial hardware.
|
||||
|
||||
It frees developers from proprietary, license-heavy PLC ecosystems and rigid "point-and-click" workflows that are no longer adequate for today's complex automation challenges.
|
||||
|
||||
QiTech Control combines the modularity and reliability of standard EtherCAT terminals (e.g., WAGO, Beckhoff) with the power of a modern Rust & React stack.
|
||||
|
||||
|
||||
[](https://www.youtube.com/watch?v=KI3YeBwfV-s)
|
||||
*Click here to watch a video demo of our software.*
|
||||
|
||||
[](https://youtu.be/55egCAkQgyM)
|
||||
*Click here to watch a full explainer Video of our Software.*
|
||||
|
||||
# Repo Structure
|
||||
|
||||
Frontend
|
||||
**Frontend**
|
||||
|
||||
- `/electron`: Frontend code for the control software built with React and Electron.
|
||||
|
||||
Backend
|
||||
**Backend**
|
||||
|
||||
- `/server`: Glue between Beckhoff and Electron. Implements machine logic.
|
||||
- `/ethercat-hal`: Hardware abstraction layer for Beckhoff (and possibly other EtherCat) devices and protocols.
|
||||
- `/ethercat-hal-derive`: Macros for `ethercat-hal`
|
||||
- `/control-core`: Core control logic for the server.
|
||||
|
||||
Operating System
|
||||
**Operating System**
|
||||
|
||||
- `/nixos`: Custom Linux with realtime kernel & preconfigured for touchscreens.
|
||||
|
||||
Other
|
||||
**Other**
|
||||
|
||||
- `/docs`: Documentation for the project.
|
||||
|
||||
@@ -32,7 +40,7 @@ Other
|
||||
|
||||
## Backend
|
||||
|
||||
To interface with Beckhoff and other EtherCAT devices we need an EtherCAY master stoftware. Possibilities are [PySOEM](https://github.com/bnjmnp/pysoem) (Python), [SOEM](https://github.com/OpenEtherCATsociety/SOEM) (C) and [Ethercrab](https://github.com/ethercrab-rs/ethercrab) (Rust). For realtime operation only C and Rust are suitable. We chose Rust because of safety and confidence in the written code.
|
||||
To interface with Beckhoff and other EtherCAT devices we need an EtherCAT master software. Possibilities are [PySOEM](https://github.com/bnjmnp/pysoem) (Python), [SOEM](https://github.com/OpenEtherCATsociety/SOEM) (C) and [Ethercrab](https://github.com/ethercrab-rs/ethercrab) (Rust). For realtime operation only C and Rust are suitable. We chose Rust because of safety and confidence in the written code.
|
||||
|
||||
[SocketIO](https://socket.io/) was chosen for performant event driven communication from the backend to the server. But we still use REST with [axum](https://docs.rs/axum/latest/axum/) for the communication thet benefits from the request/response model.
|
||||
|
||||
@@ -46,106 +54,57 @@ We could combine the code of the frontend and backend using [Doxius](https://dio
|
||||
|
||||
[Developer Documentation](./docs/developer-docs/)
|
||||
|
||||
## Backend
|
||||
[API Documentation](https://github.com/qitechgmbh/control/blob/master/docs/rest-api.md)
|
||||
|
||||
-> Backend
|
||||
- Rust stable 1.86^ toolchain (install via [rustup](https://rustup.rs/))
|
||||
- `rust-analyzer` extension for VSCode
|
||||
- Set your interface in `server/src/ethercat/init.rs` like `en10`
|
||||
- Connect a Beckhoff EK1100 to your interface
|
||||
- run `cd server && cargo run` to start the server (localhost:3001)
|
||||
|
||||
## Frontend
|
||||
|
||||
-> Frontend
|
||||
- nodejs and npm installed
|
||||
- run `cd electron && npm i && npm run start` to start the frontend
|
||||
|
||||
# Machines
|
||||
|
||||
| Machine Type | Version | Release Date | Description | Change to Previous Version | Vendor ID | Machine ID | Implemented | Docs |
|
||||
| ------------ | ------- | ------------ | --------------------------- | ------------------------------------------------------ | -------------------------- | ---------- | ----------- | ------------------------------- |
|
||||
| Winder | V1 | ??? | Winding Filaments & Similar | - | 1 (Qitech Industries GmbH) | 1 | Reserved | - |
|
||||
| Winder | V2 | 2025 | Winding Filaments & Similar | Reengineered Traverse | 1 (Qitech Industries GmbH) | 2 | In Progress | [](./docs/machines/winder-1.md) |
|
||||
| Extruder | V1 | ??? | Single Screw Extruder | - | 1 (Qitech Industries GmbH) | 3 | Reserved | - |
|
||||
| Extruder | V2 | 2025 | Single Screw Extruder | PT100 Thermometers, Optional Additional Heating Zone 4 | 1 (Qitech Industries GmbH) | 4 | Not Yet | |
|
||||
| Waterway | V1 | 2025 | Filament Water Cooling | - | 1 (Qitech Industries GmbH) | 5 | Not Yet | |
|
||||
| Laser | V1 | ??? | Diameter Measuring Laser | - | 1 (Qitech Industries GmbH) | 6 | Not Yet | |
|
||||
| Mock | - | ??? | Mock Machine for Testing | - | 1 (Qitech Industries GmbH) | 7 | Not Yet | - |
|
||||
## Minimal Hardware Examples
|
||||
|
||||
# More Docs
|
||||
For complete step-by-step tutorials on setting up your first hardware, including wiring diagrams and software configuration, see the [Getting Started Guide](./docs/developer-docs/getting-started.md#minimal-hardware-examples).
|
||||
|
||||
- [x] [Architecture & Data Flow](./docs/architecture-overview.md)
|
||||
| Example | Vendor | Hardware | Description | How-To Video | Docs |
|
||||
| :----------------- | :------- | :------------ | :-------------------------------------- | :----------- | :---------------------------- |
|
||||
| **Digital Input** | WAGO | 750-402 | 4-Channel Digital Input | [ ] | - |
|
||||
| **Digital Output** | WAGO | 750-753 | 8-Channel Digital Output | [ ] | - |
|
||||
| **Analog Input** | WAGO | 750-455 | 4-Channel Analog Input | [ ] | - |
|
||||
| **Analog Output** | WAGO | 750-553 | 4-Channel Analog Output | [ ] | - |
|
||||
| **Serial Comms** | WAGO | 750-652 | RS-485 Modbus Module | [ ] | - |
|
||||
| **Stepper Drive** | WAGO | 750-67x | Stepper Controller | [ ] | - |
|
||||
| **Power Supply** | WAGO | 2787-214 | Power Supply Unit | [ ] | - |
|
||||
| **LED Control** | Beckhoff | EL2004 | Digital output control (simplest setup) | [ ] | [](./docs/hardware/el2004.md) |
|
||||
| **Analog Input** | Beckhoff | EL3021 | Reading analog current measurements | [ ] | [](./docs/hardware/el3021.md) |
|
||||
|
||||
- [x] Example Winder V2
|
||||
# QiTech Machines
|
||||
|
||||
- [ ] Electron
|
||||
| Machine Name | Description | Machine ID | Implemented | Video | Docs |
|
||||
| :---------------- | :-------------------------- | :--------- | :---------- | :-------------------------------------------------------------- | :------------------------------ |
|
||||
| Winder V1 | Winding Filaments & Similar | 1 | Legacy | [Video](https://youtu.be/4aE4cFhioKA?si=Xdj_LVnFrAYWnLm6) | - |
|
||||
| Winder V2 | Winding Filaments & Similar | 2 | Yes | [Video](https://youtu.be/f2kzh6kpQWE?si=HEYcLOaC9gWSp2Wo) | [](./docs/machines/winder-1.md) |
|
||||
| XL Winder V1 | Large Scale Winder | 3 | Yes | [Video](https://youtu.be/ynI6ioWIQQY?si=4EDVKXbgIqrvGGtY) | - |
|
||||
| Buffer V1 | Filament buffering system | 4 | In Progress | [Video](https://youtu.be/VR5mEdZDPA0?si=eip7dQXU4zaXK7Ev) | - |
|
||||
| Extruder V1 | Single Screw Extruder | 5 | Legacy | [Video](https://youtu.be/gchoG-yGczI?si=bEM4daf5eOVaU5_2) | - |
|
||||
| Extruder V2 | Single Screw Extruder | 6 | Yes | [Video](https://youtu.be/mexRYGDNWa4?si=h7JBz_XKMwKLPenG) | |
|
||||
| Waterway V1 | Filament Water Cooling | 7 | In Progress | [Video](https://youtu.be/_T5z1J8bl_k?si=uOC1hIQ1EAP0cHIF) | |
|
||||
| Laser V1 | Diameter Measuring Laser | 8 | Yes | [Video](https://youtu.be/WDM34lj4afM?si=MZzUKkHCrzH4P0aA) | |
|
||||
| 2-Axis-Laser V1 | Dual Axis Laser | 9 | Yes | [Video](https://youtu.be/WDM34lj4afM?si=MZzUKkHCrzH4P0aA) | - |
|
||||
| Mock | Mock Machine for Testing | 10 | Yes | | - |
|
||||
| Extruder V3 | Single Screw Extruder | 11 | Yes | [Video](https://youtu.be/ipHHuPzCvn4?si=hkZ1b93rVuwDxhFD) | |
|
||||
| Mini Schredder V1 | mini plastic crusher | 12 | Legacy | [Video](https://youtu.be/m8NplNqdu2Q?si=x6zjDktJtpbSMSmu) | - |
|
||||
| Pro Schredder V1 | large plastic crusher | 13 | Legacy | [Video](https://youtu.be/pSaVMqp06pU?si=y61enutRpxKscBm4) | - |
|
||||
| Dryer V1 | polymer dryer | 14 | Reserved | [Video](https://youtu.be/6hdmUUAdZp0?si=eKOW1WlgkqTpnfdS) | - |
|
||||
| Pelletizier V1 | Filament chopper | 15 | Reserved | | - |
|
||||
|
||||
- Folder Structure
|
||||
- Routing with TanStack Router
|
||||
- Design with Tailwind & Shadcn
|
||||
- ...
|
||||
# Current Restructuring Efforts
|
||||
|
||||
- [ ] Interfacing with Electron/Server
|
||||
|
||||
- [ ] SocketIO
|
||||
- Machine Namespace
|
||||
- Main Namespace
|
||||
- [ ] REST
|
||||
- Machine Mutations
|
||||
- Write Device Identification
|
||||
|
||||
- Server
|
||||
|
||||
- [x] [Threading](./docs/control-loop.md)
|
||||
- [x] [Logging](./docs/logging.md)
|
||||
- [ ] Control Loop Setup
|
||||
- Control Loop Thread
|
||||
- [ ] realtime
|
||||
- Maindevice
|
||||
- Group
|
||||
- Extracting Device Identifications
|
||||
- Identifying Groups
|
||||
- Validating Machines
|
||||
- Run Control Loop
|
||||
- [x] [Control Loop](./docs/control-loop.md)
|
||||
- [x] [Machine/Device Identification](./docs/identification.md)
|
||||
- [ ] Machines
|
||||
- When to create a new Machine?
|
||||
- Versioning
|
||||
- Code sharing
|
||||
- Creating/Validating a Machine
|
||||
- Validation
|
||||
- Configuration
|
||||
- [ ] Machine Implementation Guide
|
||||
- Link: How to create a Device
|
||||
- Link: How to create an Actor
|
||||
- Link: How to create a Machine
|
||||
- API (SocketIO + REST)
|
||||
- Creation/Validation Logic
|
||||
- Optional/Mandatory Devices
|
||||
- Validate Devices
|
||||
- Business Logic
|
||||
- Link: How to create Machine Abstraction (Like Traverse/Puller/...)
|
||||
- Forward `act` in winder.
|
||||
|
||||
- [ ] Control Core
|
||||
|
||||
- [x] [Actors](./docs/actors.md)
|
||||
- [ ] SocketIO
|
||||
- Namespaces & Caching
|
||||
- Joining leaving namespaces
|
||||
- NamespaceId
|
||||
- Caching
|
||||
- Serverside Caching
|
||||
- Clientside Caching
|
||||
- [ ] REST
|
||||
|
||||
- [x] Ethercat HAL
|
||||
|
||||
- [x] [Devices](./docs/devices.md)
|
||||
- [x] [Configuration (CoE)](./docs/coe.md)
|
||||
- [x] [IO](./docs/io.md)
|
||||
- [x] [PDO](./docs/pdo.md)
|
||||
|
||||
- [x] [Ethercat Basics](./docs/ethercat-basics.md)
|
||||
|
||||
- [x] [NixOS Operating System](./docs/nixos/README.md)
|
||||
[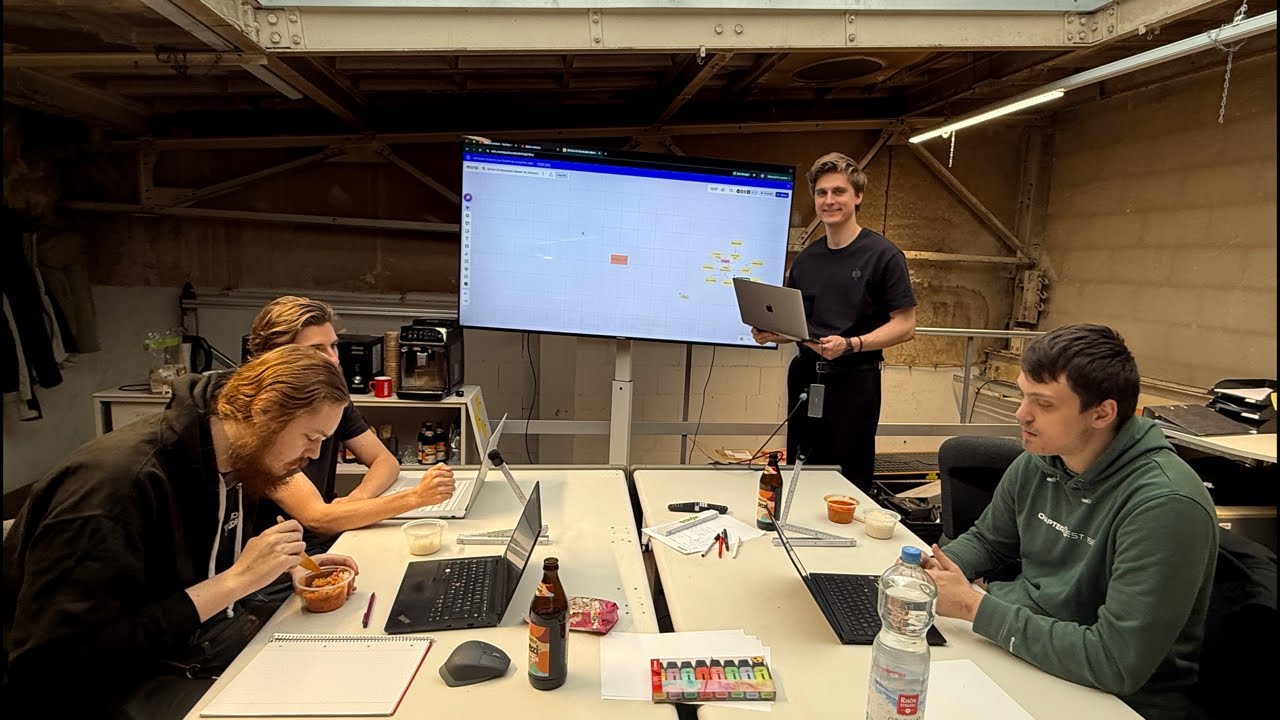](https://www.youtube.com/live/UlbnSVIhfLI?si=ZTotC5B7gd87tUim)
|
||||
*Video: Live stream of software dev meeting*
|
||||
@@ -15,16 +15,18 @@ if [[ "$1" == "release" ]]; then
|
||||
cargo build --release
|
||||
else
|
||||
echo "Building Debug Code"
|
||||
cargo build $FEATURE
|
||||
cargo build $FEATURE --features development-build
|
||||
fi
|
||||
|
||||
# Only setcap if not building with mock-machine
|
||||
if [ "$1" != "mock-machine" ]; then
|
||||
echo "Setting capabilities for server executable"
|
||||
sudo setcap 'cap_net_raw,cap_sys_nice=eip' ./target/debug/server
|
||||
sudo setcap 'cap_dac_override,cap_net_raw,cap_sys_nice,cap_ipc_lock=eip' ./target/debug/server
|
||||
|
||||
echo "Setting permissions for serial ports"
|
||||
# sudo chown "root:$(groups | cut -f1 -d' ')" /dev/ttyUSB*
|
||||
if compgen -G "/dev/ttyUSB*" > /dev/null; then
|
||||
echo "Setting permissions for serial ports"
|
||||
sudo chown "root:$(groups | cut -f1 -d' ')" /dev/ttyUSB*
|
||||
fi
|
||||
fi
|
||||
|
||||
# run
|
||||
|
||||
@@ -0,0 +1,67 @@
|
||||
#!/usr/bin/env bash
|
||||
set -euo pipefail
|
||||
|
||||
BUILD_DIR="${BUILD_DIR:-target}"
|
||||
CSV_FILE="${CSV_FILE:-compile_metrics.csv}"
|
||||
DEFAULT_PKG="server"
|
||||
|
||||
if [ "$#" -eq 0 ]; then
|
||||
set -- cargo build
|
||||
fi
|
||||
|
||||
if [ "${1:-}" = "cargo" ] && [ "${2:-}" = "build" ]; then
|
||||
cargo clean
|
||||
BUILD_CMD=(cargo rustc -p "$DEFAULT_PKG")
|
||||
shift 2
|
||||
BUILD_CMD+=("$@")
|
||||
BUILD_CMD+=(-- --emit=llvm-ir -C debuginfo=0)
|
||||
else
|
||||
BUILD_CMD=("$@")
|
||||
fi
|
||||
|
||||
compile_start_ns=$(date +%s%N)
|
||||
"${BUILD_CMD[@]}"
|
||||
compile_end_ns=$(date +%s%N)
|
||||
compile_ms=$(( (compile_end_ns - compile_start_ns) / 1000000 ))
|
||||
|
||||
if [ -d "$BUILD_DIR" ]; then
|
||||
llvm_ir_lines=$(
|
||||
find "$BUILD_DIR" -type f -name '*.ll' -print0 \
|
||||
| xargs -0 cat \
|
||||
| wc -l
|
||||
)
|
||||
else
|
||||
llvm_ir_lines=0
|
||||
fi
|
||||
|
||||
bin_path=""
|
||||
|
||||
if [ -n "${BINARY_PATH:-}" ] && [ -f "$BINARY_PATH" ]; then
|
||||
bin_path="$BINARY_PATH"
|
||||
elif [ -f "./target/release/server" ]; then
|
||||
bin_path="./target/release/server"
|
||||
elif [ -f "./target/debug/server" ]; then
|
||||
bin_path="./target/debug/server"
|
||||
elif [ -f "./server/target/release/server" ]; then
|
||||
bin_path="./server/target/release/server"
|
||||
elif [ -f "./server/target/debug/server" ]; then
|
||||
bin_path="./server/target/debug/server"
|
||||
fi
|
||||
|
||||
if [ -n "$bin_path" ]; then
|
||||
binary_size_bytes=$(stat -c '%s' "$bin_path")
|
||||
else
|
||||
binary_size_bytes=0
|
||||
fi
|
||||
|
||||
finished_timestamp_ms=$(($(date +%s%N) / 1000000))
|
||||
finished_datetime=$(date -Iseconds)
|
||||
|
||||
if [ ! -f "$CSV_FILE" ]; then
|
||||
echo "datetime,finished_timestamp_ms,compile_ms,llvm_ir_lines,binary_size_bytes" > "$CSV_FILE"
|
||||
fi
|
||||
|
||||
echo "${finished_datetime},${finished_timestamp_ms},${compile_ms},${llvm_ir_lines},${binary_size_bytes}" \
|
||||
>> "$CSV_FILE"
|
||||
|
||||
echo "Metrics recorded in $CSV_FILE"
|
||||
@@ -40,10 +40,15 @@ fn machine_derive2(item: TokenStream2) -> Result<TokenStream2, Error> {
|
||||
let ast: DeriveInput = syn::parse2(item)?;
|
||||
|
||||
let ident = &ast.ident;
|
||||
|
||||
let (impl_generics, ty_generics, where_clause) = ast.generics.split_for_impl();
|
||||
|
||||
let expanded = quote! {
|
||||
impl #impl_generics control_core::machines::Machine for #ident #ty_generics #where_clause {}
|
||||
impl #impl_generics control_core::machines::Machine for #ident #ty_generics #where_clause {
|
||||
fn get_machine_identification_unique(&self) -> control_core::machines::identification::MachineIdentificationUnique {
|
||||
self.machine_identification_unique.clone()
|
||||
}
|
||||
}
|
||||
|
||||
impl #impl_generics control_core::machines::AnyGetters for #ident #ty_generics #where_clause {
|
||||
fn as_any(&self) -> &dyn std::any::Any {
|
||||
|
||||
@@ -7,31 +7,29 @@ edition = "2024"
|
||||
workspace = true
|
||||
|
||||
[dependencies]
|
||||
anyhow = "1.0.99"
|
||||
anyhow = "1.0.100"
|
||||
|
||||
axum = "0.8.4"
|
||||
axum = "0.8.6"
|
||||
|
||||
ethercat_hal = { path = "../ethercat-hal" }
|
||||
units = { path = "../units" }
|
||||
ethercrab = "0.6"
|
||||
interfaces = "0.0.9"
|
||||
serde = "1.0.219"
|
||||
serde_json = "1.0.143"
|
||||
serialport = "4.7.3"
|
||||
smol = "2.0.2"
|
||||
socketioxide = "0.17.2"
|
||||
uom = "0.36.0"
|
||||
bitvec = { version = "1.0.1", features = ["alloc"] }
|
||||
crc = "3.3.0"
|
||||
serial = "0.4.0"
|
||||
tracing = "0.1.41"
|
||||
erased-serde = "0.4.6"
|
||||
tracing = "0.1.44"
|
||||
erased-serde = "0.4.8"
|
||||
core_affinity = "0.8.3"
|
||||
control_core_derive = { version = "0.1.0", path = "../control-core-derive" }
|
||||
tokio = { version = "1.45.1", features = ["sync"], optional = true }
|
||||
|
||||
|
||||
[target.'cfg(unix)'.dependencies]
|
||||
libc = "0.2.175"
|
||||
libc = "0.2.176"
|
||||
|
||||
[dev-dependencies]
|
||||
approx = "0.5.1"
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
use std::time::Instant;
|
||||
|
||||
use uom::si::{
|
||||
use units::{
|
||||
angular_acceleration::radian_per_second_squared,
|
||||
angular_velocity::radian_per_second,
|
||||
f64::{AngularAcceleration, AngularVelocity},
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
use std::time::Instant;
|
||||
|
||||
use uom::si::{
|
||||
use units::{
|
||||
acceleration::meter_per_second_squared,
|
||||
f64::{Acceleration, Velocity},
|
||||
velocity::meter_per_second,
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
use std::time::Instant;
|
||||
|
||||
use uom::si::{
|
||||
use units::{
|
||||
angle::radian,
|
||||
angular_acceleration::radian_per_second_squared,
|
||||
angular_velocity::radian_per_second,
|
||||
@@ -199,8 +199,8 @@ impl AngularAccelerationPositionController {
|
||||
/// # Example
|
||||
/// ```ignore
|
||||
/// use control_core::controllers::second_degree_motion::angular_acceleration_position_controller::AngularAccelerationPositionController;
|
||||
/// use uom::si::f64::Angle;
|
||||
/// use uom::si::angle::degree;
|
||||
/// use units::f64::Angle;
|
||||
/// use units::angle::degree;
|
||||
///
|
||||
/// let mut controller = AngularAccelerationPositionController::new_simple(
|
||||
/// Some(Angle::new::<degree>(180.0)),
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
use std::time::Instant;
|
||||
|
||||
use uom::si::{
|
||||
use units::{
|
||||
angular_acceleration::radian_per_second_squared,
|
||||
angular_jerk::radian_per_second_cubed,
|
||||
angular_velocity::radian_per_second,
|
||||
@@ -23,7 +23,7 @@ use super::jerk_speed_controller::JerkSpeedController;
|
||||
///
|
||||
/// # Example
|
||||
/// ```ignore
|
||||
/// use uom::si::{
|
||||
/// use units::{
|
||||
/// angular_velocity::revolution_per_minute,
|
||||
/// angular_acceleration::revolution_per_minute_per_second,
|
||||
/// angular_jerk::revolution_per_minute_per_second_squared,
|
||||
@@ -65,7 +65,7 @@ impl AngularJerkSpeedController {
|
||||
///
|
||||
/// # Example
|
||||
/// ```ignore
|
||||
/// use uom::si::{
|
||||
/// use units::{
|
||||
/// angular_velocity::revolution_per_minute,
|
||||
/// angular_acceleration::revolution_per_minute_per_second,
|
||||
/// angular_jerk::revolution_per_minute_per_second_squared,
|
||||
@@ -127,7 +127,7 @@ impl AngularJerkSpeedController {
|
||||
///
|
||||
/// # Example
|
||||
/// ```ignore
|
||||
/// use uom::si::{
|
||||
/// use units::{
|
||||
/// angular_velocity::revolution_per_minute,
|
||||
/// angular_acceleration::revolution_per_minute_per_second,
|
||||
/// angular_jerk::revolution_per_minute_per_second_squared,
|
||||
@@ -185,7 +185,7 @@ impl AngularJerkSpeedController {
|
||||
/// # Example
|
||||
/// ```ignore
|
||||
/// use std::time::Instant;
|
||||
/// use uom::si::{angular_velocity::revolution_per_minute, f64::AngularVelocity};
|
||||
/// use units::{angular_velocity::revolution_per_minute, f64::AngularVelocity};
|
||||
///
|
||||
/// let mut controller = AngularJerkSpeedController::new_simple(/* ... */);
|
||||
/// let target = AngularVelocity::new::<revolution_per_minute>(1500.0);
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
use std::time::Instant;
|
||||
|
||||
use uom::si::{
|
||||
use units::{
|
||||
acceleration::meter_per_second_squared,
|
||||
f64::{Acceleration, Length, Velocity},
|
||||
length::meter,
|
||||
@@ -22,8 +22,8 @@ use super::acceleration_position_controller::{
|
||||
///
|
||||
/// # Example
|
||||
/// ```ignore
|
||||
/// use uom::si::{length::meter, velocity::meter_per_second, acceleration::meter_per_second_squared};
|
||||
/// use uom::si::f64::{Length, Velocity, Acceleration};
|
||||
/// use units::{length::meter, velocity::meter_per_second, acceleration::meter_per_second_squared};
|
||||
/// use units::f64::{Length, Velocity, Acceleration};
|
||||
///
|
||||
/// let position_limit = Length::new::<meter>(10.0);
|
||||
/// let max_speed = Velocity::new::<meter_per_second>(2.0);
|
||||
@@ -101,8 +101,8 @@ impl LinearAccelerationPositionController {
|
||||
///
|
||||
/// # Example
|
||||
/// ```ignore
|
||||
/// use uom::si::{length::meter, velocity::meter_per_second, acceleration::meter_per_second_squared};
|
||||
/// use uom::si::f64::{Length, Velocity, Acceleration};
|
||||
/// use units::{length::meter, velocity::meter_per_second, acceleration::meter_per_second_squared};
|
||||
/// use units::f64::{Length, Velocity, Acceleration};
|
||||
///
|
||||
/// let position_limit = Length::new::<meter>(5.0); // Creates [-5.0, +5.0] meter range
|
||||
/// let max_speed = Velocity::new::<meter_per_second>(1.0); // Creates [-1.0, +1.0] m/s range
|
||||
@@ -150,7 +150,7 @@ impl LinearAccelerationPositionController {
|
||||
/// # Example
|
||||
/// ```ignore
|
||||
/// use std::time::Instant;
|
||||
/// use uom::si::{length::meter, f64::Length};
|
||||
/// use units::{length::meter, f64::Length};
|
||||
///
|
||||
/// let mut controller = LinearAccelerationPositionController::new_simple(
|
||||
/// Some(Length::new::<meter>(10.0)),
|
||||
@@ -375,7 +375,7 @@ impl LinearAccelerationPositionController {
|
||||
///
|
||||
/// # Example
|
||||
/// ```ignore
|
||||
/// use uom::si::{length::meter, velocity::meter_per_second, f64::{Length, Velocity}};
|
||||
/// use units::{length::meter, velocity::meter_per_second, f64::{Length, Velocity}};
|
||||
///
|
||||
/// let new_position = Length::new::<meter>(0.0);
|
||||
///
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
use std::time::Instant;
|
||||
|
||||
use uom::si::{
|
||||
use units::{
|
||||
acceleration::meter_per_second_squared,
|
||||
f64::{Acceleration, Jerk, Velocity},
|
||||
jerk::meter_per_second_cubed,
|
||||
@@ -23,7 +23,7 @@ use super::jerk_speed_controller::JerkSpeedController;
|
||||
///
|
||||
/// # Example
|
||||
/// ```ignore
|
||||
/// use uom::si::{
|
||||
/// use units::{
|
||||
/// velocity::meter_per_second,
|
||||
/// acceleration::meter_per_second_squared,
|
||||
/// jerk::meter_per_second_cubed,
|
||||
@@ -65,7 +65,7 @@ impl LinearJerkSpeedController {
|
||||
///
|
||||
/// # Example
|
||||
/// ```ignore
|
||||
/// use uom::si::{
|
||||
/// use units::{
|
||||
/// velocity::meter_per_second,
|
||||
/// acceleration::meter_per_second_squared,
|
||||
/// jerk::meter_per_second_cubed,
|
||||
@@ -127,7 +127,7 @@ impl LinearJerkSpeedController {
|
||||
///
|
||||
/// # Example
|
||||
/// ```ignore
|
||||
/// use uom::si::{
|
||||
/// use units::{
|
||||
/// velocity::meter_per_second,
|
||||
/// acceleration::meter_per_second_squared,
|
||||
/// jerk::meter_per_second_cubed,
|
||||
|
||||
@@ -1,4 +1,4 @@
|
||||
use uom::si::angle::radian;
|
||||
use units::{angle::radian, f64::Angle};
|
||||
|
||||
#[derive(Debug, Clone, Copy, PartialEq, Eq)]
|
||||
pub struct AngleConverter {
|
||||
@@ -63,7 +63,7 @@ impl AngleConverter {
|
||||
}
|
||||
|
||||
/// Convert angle from mathematical system to this system (f32)
|
||||
pub fn degrees_encode(&self, math_angle_degrees: f32) -> f32 {
|
||||
pub fn degrees_encode(&self, math_angle_degrees: f64) -> f64 {
|
||||
let normalized_input = self.normalize_angle(math_angle_degrees);
|
||||
|
||||
let mut result = normalized_input;
|
||||
@@ -85,7 +85,7 @@ impl AngleConverter {
|
||||
}
|
||||
|
||||
/// Convert angle from this system to mathematical system (f32)
|
||||
pub fn degrees_decode(&self, system_angle_degrees: f32) -> f32 {
|
||||
pub fn degrees_decode(&self, system_angle_degrees: f64) -> f64 {
|
||||
let normalized_input = self.normalize_angle(system_angle_degrees);
|
||||
|
||||
let mut result = normalized_input;
|
||||
@@ -107,14 +107,14 @@ impl AngleConverter {
|
||||
}
|
||||
|
||||
/// Convert angle in radians from mathematical system to this system (f32)
|
||||
pub fn radians_encode(&self, math_angle_radians: f32) -> f32 {
|
||||
pub fn radians_encode(&self, math_angle_radians: f64) -> f64 {
|
||||
let degrees = math_angle_radians.to_degrees();
|
||||
let converted_degrees = self.degrees_encode(degrees);
|
||||
converted_degrees.to_radians()
|
||||
}
|
||||
|
||||
/// Convert angle in radians from this system to mathematical system (f32)
|
||||
pub fn radians_decode(&self, system_angle_radians: f32) -> f32 {
|
||||
pub fn radians_decode(&self, system_angle_radians: f64) -> f64 {
|
||||
let degrees = system_angle_radians.to_degrees();
|
||||
let converted_degrees = self.degrees_decode(degrees);
|
||||
converted_degrees.to_radians()
|
||||
@@ -179,7 +179,7 @@ impl AngleConverter {
|
||||
}
|
||||
|
||||
/// Normalize angle to [0, 360) range (f32)
|
||||
fn normalize_angle(&self, angle: f32) -> f32 {
|
||||
fn normalize_angle(&self, angle: f64) -> f64 {
|
||||
let mut normalized = angle % 360.0;
|
||||
if normalized < 0.0 {
|
||||
normalized += 360.0;
|
||||
@@ -207,30 +207,12 @@ impl AngleConverterUom {
|
||||
Self { angle_converter }
|
||||
}
|
||||
|
||||
pub fn encode(&self, angle: uom::si::f32::Angle) -> uom::si::f32::Angle {
|
||||
uom::si::f32::Angle::new::<radian>(
|
||||
self.angle_converter.radians_encode(angle.get::<radian>()),
|
||||
)
|
||||
pub fn encode(&self, angle: Angle) -> Angle {
|
||||
Angle::new::<radian>(self.angle_converter.radians_encode(angle.get::<radian>()))
|
||||
}
|
||||
|
||||
pub fn decode(&self, angle: uom::si::f32::Angle) -> uom::si::f32::Angle {
|
||||
uom::si::f32::Angle::new::<radian>(
|
||||
self.angle_converter.radians_decode(angle.get::<radian>()),
|
||||
)
|
||||
}
|
||||
|
||||
pub fn encode_f64(&self, angle: uom::si::f64::Angle) -> uom::si::f64::Angle {
|
||||
uom::si::f64::Angle::new::<radian>(
|
||||
self.angle_converter
|
||||
.radians_encode_f64(angle.get::<radian>()),
|
||||
)
|
||||
}
|
||||
|
||||
pub fn decode_f64(&self, angle: uom::si::f64::Angle) -> uom::si::f64::Angle {
|
||||
uom::si::f64::Angle::new::<radian>(
|
||||
self.angle_converter
|
||||
.radians_decode_f64(angle.get::<radian>()),
|
||||
)
|
||||
pub fn decode(&self, angle: Angle) -> Angle {
|
||||
Angle::new::<radian>(self.angle_converter.radians_decode(angle.get::<radian>()))
|
||||
}
|
||||
}
|
||||
|
||||
@@ -297,8 +279,8 @@ mod tests {
|
||||
let converter = AngleConverter::screen();
|
||||
|
||||
// Test radians_encode
|
||||
let result = converter.radians_encode(PI / 2.0); // 90° in radians
|
||||
let expected = 270.0 * PI / 180.0; // 270° in radians
|
||||
let result = converter.radians_encode(PI as f64 / 2.0) as f64; // 90° in radians
|
||||
let expected: f64 = 270.0f64 * PI as f64 / 180.0f64; // 270° in radians
|
||||
assert!((result - expected).abs() < 1e-6);
|
||||
}
|
||||
|
||||
@@ -306,10 +288,10 @@ mod tests {
|
||||
fn test_roundtrip_conversion() {
|
||||
let converter = AngleConverter::new(true, false, true); // X-flip + CW
|
||||
|
||||
let original = 75.0_f32;
|
||||
let original = 75.0_f64;
|
||||
let converted = converter.degrees_encode(original);
|
||||
let roundtrip = converter.degrees_decode(converted);
|
||||
|
||||
assert!((original - roundtrip).abs() < 1e-6);
|
||||
assert!((original - roundtrip as f64).abs() < 1e-6);
|
||||
}
|
||||
}
|
||||
@@ -1,4 +1,4 @@
|
||||
use uom::si::{
|
||||
use units::{
|
||||
angle::revolution,
|
||||
angular_acceleration::radian_per_second_squared,
|
||||
angular_velocity::revolution_per_second,
|
||||
@@ -90,7 +90,7 @@ mod tests {
|
||||
use super::*;
|
||||
use approx::assert_relative_eq;
|
||||
use std::f64::EPSILON;
|
||||
use uom::si::{
|
||||
use units::{
|
||||
angle::degree, angular_acceleration::degree_per_second_squared,
|
||||
angular_velocity::degree_per_second,
|
||||
};
|
||||
|
||||
@@ -14,14 +14,14 @@
|
||||
//!
|
||||
//! ```rust
|
||||
//! use control_core::converters::circular_converter::CircularConverter;
|
||||
//! use uom::si::{f64::{Length, Velocity}, length::meter, velocity::meter_per_second};
|
||||
//! use units::{f64::{Length, Velocity}, length::meter, velocity::meter_per_second};
|
||||
//!
|
||||
//! let converter = CircularConverter::from_radius(Length::new::<meter>(0.1));
|
||||
//! let velocity = Velocity::new::<meter_per_second>(1.0);
|
||||
//! let angular_velocity = converter.linear_to_angular_velocity(velocity);
|
||||
//! ```
|
||||
|
||||
use uom::si::{
|
||||
use units::{
|
||||
acceleration::meter_per_second_squared,
|
||||
angle::radian,
|
||||
angular_acceleration::radian_per_second_squared,
|
||||
@@ -199,7 +199,7 @@ impl CircularConverter {
|
||||
#[cfg(test)]
|
||||
mod tests {
|
||||
use super::*;
|
||||
use uom::si::length::centimeter;
|
||||
use units::length::centimeter;
|
||||
|
||||
#[test]
|
||||
fn test_constructors() {
|
||||
|
||||
@@ -1,4 +1,4 @@
|
||||
use uom::si::{
|
||||
use units::{
|
||||
angle::revolution,
|
||||
angular_velocity::revolution_per_second,
|
||||
f64::{Acceleration, Angle, AngularAcceleration, AngularVelocity, Length, Velocity},
|
||||
@@ -251,7 +251,7 @@ mod tests {
|
||||
use super::*;
|
||||
use approx::assert_relative_eq;
|
||||
use std::f64::EPSILON;
|
||||
use uom::si::{
|
||||
use units::{
|
||||
acceleration::meter_per_second_squared, angular_acceleration::radian_per_second_squared,
|
||||
length::meter, velocity::meter_per_second,
|
||||
};
|
||||
|
||||
@@ -0,0 +1,36 @@
|
||||
use anyhow::anyhow;
|
||||
use smol::lock::Mutex;
|
||||
use std::any::Any;
|
||||
use std::sync::Arc;
|
||||
|
||||
pub trait Downcast<T> {
|
||||
fn downcast(&self) -> Result<T, anyhow::Error>;
|
||||
}
|
||||
|
||||
pub trait DowncastRef<T> {
|
||||
fn downcast_ref(&self) -> Result<&T, anyhow::Error>;
|
||||
}
|
||||
|
||||
impl<T: 'static, U: Any + 'static> Downcast<Arc<Mutex<T>>> for Arc<Mutex<U>> {
|
||||
fn downcast(&self) -> Result<Arc<Mutex<T>>, anyhow::Error> {
|
||||
// Acquire a read lock on the RwLock
|
||||
let lock = self.lock_blocking();
|
||||
|
||||
// Check if the inner type can be downcasted to T
|
||||
let any: &dyn Any = &*lock;
|
||||
|
||||
if any.is::<T>() {
|
||||
// Clone the Arc and return it as the desired type
|
||||
let cloned: Arc<Mutex<dyn Any>> = self.clone();
|
||||
|
||||
// Transmute the Arc to the desired type
|
||||
unsafe {
|
||||
let arc = Arc::from_raw(Arc::into_raw(cloned) as *const Mutex<T>);
|
||||
|
||||
Ok(arc)
|
||||
}
|
||||
} else {
|
||||
Err(anyhow!("[{}::downcast] Downcast failed", module_path!()))
|
||||
}
|
||||
}
|
||||
}
|
||||
@@ -1,10 +1,9 @@
|
||||
use std::{sync::Arc, time::Duration};
|
||||
|
||||
use ethercrab::{
|
||||
MainDevice, MainDeviceConfig, PduStorage, Timeouts,
|
||||
std::{ethercat_now, tx_rx_task},
|
||||
};
|
||||
use interfaces::Interface;
|
||||
use std::{process::Command, sync::Arc, time::Duration};
|
||||
|
||||
// Constants for EtherCAT configuration
|
||||
const IFACE_DISCOVERY_MAX_SUBDEVICES: usize = 16; // Must be power of 2 > 1
|
||||
@@ -12,14 +11,46 @@ const IFACE_DISCOVERY_MAX_PDU_DATA: usize = PduStorage::element_size(1100);
|
||||
const IFACE_DISCOVERY_MAX_FRAMES: usize = 16;
|
||||
const IFACE_DISCOVERY_MAX_PDI_LEN: usize = 128;
|
||||
|
||||
/// Finds an ethernet interface that is suitable for EtherCAT communication.
|
||||
///
|
||||
/// ```ignore
|
||||
/// match discover_ethercat_interface().await {
|
||||
/// Ok(interface) => println!("Found working interface: {}", interface),
|
||||
/// Err(_) => println!("No working interface found"),
|
||||
/// }
|
||||
/// ```
|
||||
/// Sets a network interface to unmanaged by NetworkManager.
|
||||
/// Returns true if the command succeeded.
|
||||
pub fn set_interface_managed(interface: &str, managed: bool) -> bool {
|
||||
let managed_str = match managed {
|
||||
true => "yes",
|
||||
false => "no",
|
||||
};
|
||||
tracing::info!(
|
||||
"set_interface_managed for {} managed was set to: {}",
|
||||
interface,
|
||||
managed_str
|
||||
);
|
||||
let status = Command::new("nmcli")
|
||||
.args(["dev", "set", interface, "managed", managed_str])
|
||||
.status();
|
||||
|
||||
matches!(status, Ok(s) if s.success())
|
||||
}
|
||||
|
||||
/// Returns true if the given network interface is Ethernet.
|
||||
/// Prevents testing wlan,loopback and other non ethernet devices
|
||||
fn is_ethernet(interface: &str) -> std::io::Result<bool> {
|
||||
#[cfg(target_os = "linux")]
|
||||
{
|
||||
let base_path = format!("/sys/class/net/{}", interface);
|
||||
let type_path = std::path::Path::new(&base_path).join("type");
|
||||
let iface_type = std::fs::read_to_string(&type_path)?.trim().to_string();
|
||||
// 1 means Ethernet
|
||||
let reports_as_ethernet = iface_type == "1";
|
||||
// Double-check that it's not a wireless interface
|
||||
let uevent_path = std::path::Path::new(&base_path).join("uevent");
|
||||
let uevent = std::fs::read_to_string(&uevent_path).unwrap_or_default();
|
||||
// If "DEVTYPE=wlan" appears, it's lying
|
||||
let actually_wifi = uevent.contains("DEVTYPE=wlan");
|
||||
return Ok(reports_as_ethernet && !actually_wifi);
|
||||
}
|
||||
#[cfg(not(target_os = "linux"))]
|
||||
return Ok(true);
|
||||
}
|
||||
|
||||
pub async fn discover_ethercat_interface() -> Result<String, anyhow::Error> {
|
||||
tracing::info!("Discovering EtherCAT interface...");
|
||||
|
||||
@@ -37,7 +68,6 @@ pub async fn discover_ethercat_interface() -> Result<String, anyhow::Error> {
|
||||
} else {
|
||||
tracing::debug!("Suppressed panic in interface test: {}", panic_info);
|
||||
}
|
||||
// Don't call the default hook, which would print the backtrace
|
||||
}));
|
||||
|
||||
// Get eligible interfaces
|
||||
@@ -48,6 +78,7 @@ pub async fn discover_ethercat_interface() -> Result<String, anyhow::Error> {
|
||||
iface.is_up()
|
||||
&& iface.is_running()
|
||||
&& !iface.is_loopback()
|
||||
&& is_ethernet(&iface.name).unwrap_or(false)
|
||||
&& !iface.name.starts_with("bridge")
|
||||
&& !iface.name.starts_with("utun") // Exclude tunnel interfaces
|
||||
&& !iface.name.starts_with("awdl") // Exclude Apple Wireless Direct Link
|
||||
@@ -56,57 +87,39 @@ pub async fn discover_ethercat_interface() -> Result<String, anyhow::Error> {
|
||||
})
|
||||
.collect::<Vec<_>>();
|
||||
|
||||
// Sort interfaces by name
|
||||
interfaces.sort_by(|a, b| a.name.cmp(&b.name));
|
||||
let mut interface: Option<&str> = None;
|
||||
|
||||
// Try all interfaces concurrently
|
||||
let tasks = interfaces
|
||||
.iter()
|
||||
.map(|iface| {
|
||||
let name = iface.name.clone();
|
||||
std::thread::Builder::new()
|
||||
.name(format!("ethercat-test-{}", name))
|
||||
.spawn(move || {
|
||||
std::panic::catch_unwind(|| {
|
||||
smol::block_on(async {
|
||||
match test_interface(&name) {
|
||||
Ok(_) => {
|
||||
tracing::info!("Found working EtherCAT interface: {}", name);
|
||||
Some(name.clone())
|
||||
}
|
||||
Err(_) => {
|
||||
tracing::debug!("Interface {} failed", name);
|
||||
None
|
||||
}
|
||||
}
|
||||
})
|
||||
})
|
||||
.unwrap_or(None)
|
||||
})
|
||||
.expect("Failed to spawn thread")
|
||||
})
|
||||
.collect::<Vec<_>>();
|
||||
for i in 0..interfaces.len() {
|
||||
match test_interface(&interfaces[i].name) {
|
||||
Ok(_) => {
|
||||
// if interface found with ethercat Exit early, we expect only one interface with ethercat
|
||||
interface = Some(&interfaces[i].name);
|
||||
break;
|
||||
}
|
||||
Err(_) => (),
|
||||
}
|
||||
}
|
||||
|
||||
// Wait for all tasks to complete and collect successful results
|
||||
let successful_interfaces: Vec<String> = tasks
|
||||
.into_iter()
|
||||
.filter_map(|task| task.join().expect("Should join thread"))
|
||||
.collect();
|
||||
|
||||
// Return the first successful interface (they're sorted by name)
|
||||
let result = successful_interfaces.into_iter().next();
|
||||
for i in 0..interfaces.len() {
|
||||
if interface.is_some() && interface.unwrap() == &interfaces[i].name {
|
||||
set_interface_managed(&interfaces[i].name, false);
|
||||
} else {
|
||||
set_interface_managed(&interfaces[i].name, true);
|
||||
}
|
||||
}
|
||||
|
||||
// Restore the default panic hook
|
||||
std::panic::set_hook(default_hook);
|
||||
|
||||
match result {
|
||||
Some(name) => Ok(name),
|
||||
None => Err(anyhow::anyhow!("No suitable EtherCAT interface found")),
|
||||
match interface {
|
||||
Some(interface) => return Ok(interface.to_string()),
|
||||
None => return Err(anyhow::anyhow!("No suitable EtherCAT interface found")),
|
||||
}
|
||||
}
|
||||
|
||||
fn test_interface(interface: &str) -> Result<(), anyhow::Error> {
|
||||
tracing::trace!("Testing interface: {}", interface);
|
||||
tracing::info!("Testing interface: {}", interface);
|
||||
|
||||
let pdu_storage = Box::leak(Box::new(PduStorage::<
|
||||
IFACE_DISCOVERY_MAX_FRAMES,
|
||||
@@ -144,7 +157,7 @@ fn test_interface(interface: &str) -> Result<(), anyhow::Error> {
|
||||
// Default 10000
|
||||
dc_static_sync_iterations: 10000,
|
||||
// Default None
|
||||
retry_behaviour: ethercrab::RetryBehaviour::None,
|
||||
retry_behaviour: ethercrab::RetryBehaviour::Count(3),
|
||||
},
|
||||
));
|
||||
|
||||
|
||||
@@ -1,2 +1 @@
|
||||
pub mod eeprom_identification;
|
||||
pub mod interface_discovery;
|
||||
@@ -0,0 +1,65 @@
|
||||
use std::process::Command;
|
||||
|
||||
use anyhow::Result;
|
||||
use interfaces::Interface;
|
||||
|
||||
pub mod modbus_tcp_discovery;
|
||||
|
||||
/// Returns true if the given network interface is Ethernet.
|
||||
/// Prevents testing wlan,loopback and other non ethernet devices
|
||||
fn is_ethernet(interface: &str) -> std::io::Result<bool> {
|
||||
#[cfg(target_os = "linux")]
|
||||
{
|
||||
let base_path = format!("/sys/class/net/{}", interface);
|
||||
let type_path = std::path::Path::new(&base_path).join("type");
|
||||
let iface_type = std::fs::read_to_string(&type_path)?.trim().to_string();
|
||||
// 1 means Ethernet
|
||||
let reports_as_ethernet = iface_type == "1";
|
||||
// Double-check that it's not a wireless interface
|
||||
let uevent_path = std::path::Path::new(&base_path).join("uevent");
|
||||
let uevent = std::fs::read_to_string(&uevent_path).unwrap_or_default();
|
||||
// If "DEVTYPE=wlan" appears, it's lying
|
||||
let actually_wifi = uevent.contains("DEVTYPE=wlan");
|
||||
Ok(reports_as_ethernet && !actually_wifi)
|
||||
}
|
||||
#[cfg(not(target_os = "linux"))]
|
||||
return Ok(true);
|
||||
}
|
||||
|
||||
pub fn get_interfaces() -> Result<Vec<Interface>> {
|
||||
let vec = Interface::get_all()
|
||||
.map_err(|e| anyhow::anyhow!("Failed to get network interfaces: {}", e))?
|
||||
.into_iter()
|
||||
.filter(|iface| {
|
||||
iface.is_up()
|
||||
&& iface.is_running()
|
||||
&& !iface.is_loopback()
|
||||
&& is_ethernet(&iface.name).unwrap_or(false)
|
||||
&& !iface.name.starts_with("bridge")
|
||||
&& !iface.name.starts_with("utun") // Exclude tunnel interfaces
|
||||
&& !iface.name.starts_with("awdl") // Exclude Apple Wireless Direct Link
|
||||
&& !iface.name.starts_with("anpi") // Exclude Apple Network Privacy Interface
|
||||
&& !iface.name.starts_with("llw") // Exclude Apple low-latency WLAN
|
||||
})
|
||||
.collect::<Vec<_>>();
|
||||
Ok(vec)
|
||||
}
|
||||
|
||||
/// Sets a network interface to unmanaged by NetworkManager.
|
||||
/// Returns true if the command succeeded.
|
||||
pub fn set_interface_managed(interface: &str, managed: bool) -> bool {
|
||||
let managed_str = match managed {
|
||||
true => "yes",
|
||||
false => "no",
|
||||
};
|
||||
tracing::info!(
|
||||
"set_interface_managed for {} managed was set to: {}",
|
||||
interface,
|
||||
managed_str
|
||||
);
|
||||
let status = Command::new("nmcli")
|
||||
.args(["dev", "set", interface, "managed", managed_str])
|
||||
.status();
|
||||
|
||||
matches!(status, Ok(s) if s.success())
|
||||
}
|
||||
@@ -0,0 +1,78 @@
|
||||
use crate::ethernet::get_interfaces;
|
||||
use crate::{futures::FutureIteratorExt, modbus::tcp::ModbusTcpDevice};
|
||||
use anyhow::{Result, bail};
|
||||
use interfaces::Interface;
|
||||
use std::cmp::min;
|
||||
use std::net::{IpAddr, Ipv4Addr, SocketAddr};
|
||||
|
||||
pub struct ModbusTcpProbe {
|
||||
pub addr: SocketAddr,
|
||||
pub serial: u16,
|
||||
}
|
||||
|
||||
pub async fn probe_modbus_tcp() -> Vec<ModbusTcpProbe> {
|
||||
let interfaces = match get_interfaces() {
|
||||
Ok(x) => x,
|
||||
Err(_) => return vec![],
|
||||
};
|
||||
|
||||
interfaces
|
||||
.into_iter()
|
||||
.map(probe_modbus_tcp_addresses)
|
||||
.join_all()
|
||||
.await
|
||||
.into_iter()
|
||||
.flatten()
|
||||
.collect()
|
||||
}
|
||||
|
||||
async fn probe_modbus_tcp_addresses(interface: Interface) -> Vec<ModbusTcpProbe> {
|
||||
let out: Vec<ModbusTcpProbe> = interface
|
||||
.addresses
|
||||
.iter()
|
||||
.filter_map(|addr| {
|
||||
let a = addr.addr.map(|a| a.ip());
|
||||
let m = addr.mask.map(|a| a.ip());
|
||||
|
||||
match (a, m) {
|
||||
(Some(IpAddr::V4(addr)), Some(IpAddr::V4(mask))) => Some((addr, mask)),
|
||||
_ => None,
|
||||
}
|
||||
})
|
||||
.flat_map(|(addr, mask)| {
|
||||
let a = u32::from(addr);
|
||||
let m = u32::from(mask);
|
||||
let network = a & m;
|
||||
|
||||
let prefix = min(24, m.count_ones()); // mask → prefix length
|
||||
let size = 1u32 << (32 - prefix); // number of addresses
|
||||
|
||||
(0..size).map(move |i| SocketAddr::new(Ipv4Addr::from(network + i).into(), 502))
|
||||
})
|
||||
.map(|addr| smol::spawn(ping_modbus_device(addr)))
|
||||
.join_all()
|
||||
.await
|
||||
.into_iter()
|
||||
.filter_map(|x| x.ok())
|
||||
.collect();
|
||||
|
||||
out
|
||||
}
|
||||
|
||||
async fn ping_modbus_device(addr: SocketAddr) -> Result<ModbusTcpProbe> {
|
||||
let mut device = ModbusTcpDevice::new(addr).await?;
|
||||
|
||||
let module_number1 = device.get_u32(0x2).await?;
|
||||
let module_number2 = device.get_u32(0x4).await?;
|
||||
|
||||
if module_number1 != 0x2787_2144 || module_number2 != 0x0000_0000 {
|
||||
bail!("Unknown modbus tcp device!");
|
||||
}
|
||||
|
||||
let serial = device.get_u32(0x000A).await?;
|
||||
|
||||
Ok(ModbusTcpProbe {
|
||||
addr,
|
||||
serial: serial as u16,
|
||||
})
|
||||
}
|
||||
@@ -0,0 +1,26 @@
|
||||
use core::future::Future;
|
||||
|
||||
// Extension trait for iterators of futures
|
||||
pub trait FutureIteratorExt<F>: Iterator<Item = F> + Sized
|
||||
where
|
||||
F: Future,
|
||||
{
|
||||
/// Await all futures and return their outputs
|
||||
fn join_all(self) -> impl Future<Output = Vec<F::Output>>;
|
||||
}
|
||||
|
||||
impl<I, F> FutureIteratorExt<F> for I
|
||||
where
|
||||
I: Iterator<Item = F> + Sized,
|
||||
F: Future,
|
||||
{
|
||||
async fn join_all(self) -> Vec<F::Output> {
|
||||
let mut out = Vec::new();
|
||||
|
||||
for fut in self {
|
||||
out.push(fut.await);
|
||||
}
|
||||
|
||||
out
|
||||
}
|
||||
}
|
||||
@@ -1,19 +1,16 @@
|
||||
pub mod controllers;
|
||||
pub mod converters;
|
||||
pub mod downcast;
|
||||
pub mod ethercat;
|
||||
pub mod ethernet;
|
||||
pub mod futures;
|
||||
pub mod helpers;
|
||||
pub mod irq_handling;
|
||||
pub mod machines;
|
||||
pub mod modbus;
|
||||
pub mod realtime;
|
||||
pub mod rest;
|
||||
pub mod serial;
|
||||
pub mod socketio;
|
||||
pub mod transmission;
|
||||
pub mod uom_extensions;
|
||||
|
||||
#[cfg(feature = "video-streaming")]
|
||||
pub mod video_streaming;
|
||||
|
||||
#[macro_use]
|
||||
extern crate uom;
|
||||
@@ -1,25 +0,0 @@
|
||||
use serde_json::Value;
|
||||
|
||||
use crate::socketio::namespace::Namespace;
|
||||
|
||||
pub trait MachineApi {
|
||||
fn api_mutate(&mut self, value: Value) -> Result<(), anyhow::Error>;
|
||||
fn api_event_namespace(&mut self) -> &mut Namespace;
|
||||
|
||||
/// Returns a list of available video stream identifiers for this machine
|
||||
#[cfg(feature = "video-streaming")]
|
||||
fn api_video_streams(&self) -> Vec<String> {
|
||||
Vec::new()
|
||||
}
|
||||
|
||||
/// Get a video stream receiver for the specified stream ID
|
||||
/// Returns None if the stream doesn't exist
|
||||
#[cfg(feature = "video-streaming")]
|
||||
fn api_get_video_stream(
|
||||
&mut self,
|
||||
stream_id: &str,
|
||||
) -> Option<tokio::sync::broadcast::Receiver<Vec<u8>>> {
|
||||
let _ = stream_id;
|
||||
None
|
||||
}
|
||||
}
|
||||
@@ -1,113 +0,0 @@
|
||||
use std::fmt::Display;
|
||||
|
||||
use serde::Deserialize;
|
||||
use serde::Serialize;
|
||||
|
||||
/// Identifies a spacifi machine
|
||||
#[derive(Debug, Clone, Serialize, Deserialize, PartialEq, Eq, Hash)]
|
||||
pub struct MachineIdentificationUnique {
|
||||
pub machine_identification: MachineIdentification,
|
||||
pub serial: u16,
|
||||
}
|
||||
|
||||
impl MachineIdentificationUnique {
|
||||
/// Check if values are non-zero
|
||||
pub const fn is_valid(&self) -> bool {
|
||||
self.machine_identification.is_valid() && self.serial != 0
|
||||
}
|
||||
}
|
||||
|
||||
impl Display for MachineIdentificationUnique {
|
||||
fn fmt(&self, f: &mut std::fmt::Formatter<'_>) -> std::fmt::Result {
|
||||
write!(
|
||||
f,
|
||||
"{}/{}/{}",
|
||||
self.machine_identification.vendor, self.machine_identification.machine, self.serial
|
||||
)
|
||||
}
|
||||
}
|
||||
|
||||
/// Identifies a machine
|
||||
#[derive(Debug, Clone, Serialize, Deserialize, PartialEq, Eq, Hash)]
|
||||
pub struct MachineIdentification {
|
||||
pub vendor: u16,
|
||||
pub machine: u16,
|
||||
}
|
||||
|
||||
impl MachineIdentification {
|
||||
/// Check if values are non-zero
|
||||
pub const fn is_valid(&self) -> bool {
|
||||
self.vendor != 0 && self.machine != 0
|
||||
}
|
||||
}
|
||||
|
||||
#[derive(Debug, Clone, Serialize, Deserialize, PartialEq, Eq)]
|
||||
pub struct DeviceMachineIdentification {
|
||||
pub machine_identification_unique: MachineIdentificationUnique,
|
||||
pub role: u16,
|
||||
}
|
||||
|
||||
impl DeviceMachineIdentification {
|
||||
/// Check if values are non-zero
|
||||
pub const fn is_valid(&self) -> bool {
|
||||
self.machine_identification_unique.is_valid()
|
||||
&& self
|
||||
.machine_identification_unique
|
||||
.machine_identification
|
||||
.machine
|
||||
!= 0
|
||||
}
|
||||
}
|
||||
|
||||
#[derive(Debug, Clone, Serialize, Deserialize, PartialEq, Eq)]
|
||||
pub struct DeviceIdentification {
|
||||
pub device_machine_identification: Option<DeviceMachineIdentification>,
|
||||
pub device_hardware_identification: DeviceHardwareIdentification,
|
||||
}
|
||||
|
||||
impl From<DeviceIdentificationIdentified> for DeviceIdentification {
|
||||
fn from(value: DeviceIdentificationIdentified) -> Self {
|
||||
Self {
|
||||
device_machine_identification: Some(value.device_machine_identification),
|
||||
device_hardware_identification: value.device_hardware_identification,
|
||||
}
|
||||
}
|
||||
}
|
||||
|
||||
#[derive(Debug, Clone, Serialize, Deserialize, PartialEq, Eq)]
|
||||
pub struct DeviceIdentificationIdentified {
|
||||
pub device_machine_identification: DeviceMachineIdentification,
|
||||
pub device_hardware_identification: DeviceHardwareIdentification,
|
||||
}
|
||||
|
||||
impl TryFrom<DeviceIdentification> for DeviceIdentificationIdentified {
|
||||
type Error = anyhow::Error;
|
||||
|
||||
fn try_from(value: DeviceIdentification) -> Result<Self, Self::Error> {
|
||||
let device_machine_identification =
|
||||
value.device_machine_identification.ok_or(anyhow::anyhow!(
|
||||
"[{}::DeviceIdentificationIdentified::try_from] No device machine identification",
|
||||
module_path!()
|
||||
))?;
|
||||
|
||||
Ok(Self {
|
||||
device_machine_identification,
|
||||
device_hardware_identification: value.device_hardware_identification,
|
||||
})
|
||||
}
|
||||
}
|
||||
|
||||
#[derive(Debug, Clone, Serialize, Deserialize, PartialEq, Eq)]
|
||||
pub enum DeviceHardwareIdentification {
|
||||
Ethercat(DeviceHardwareIdentificationEthercat),
|
||||
Serial(DeviceHardwareIdentificationSerial),
|
||||
}
|
||||
|
||||
#[derive(Debug, Clone, Serialize, Deserialize, PartialEq, Eq)]
|
||||
pub struct DeviceHardwareIdentificationEthercat {
|
||||
pub subdevice_index: usize,
|
||||
}
|
||||
#[derive(Debug, Clone, Serialize, Deserialize, PartialEq, Eq)]
|
||||
pub struct DeviceHardwareIdentificationSerial {
|
||||
pub path: String,
|
||||
}
|
||||
@@ -1,275 +0,0 @@
|
||||
use smol::{
|
||||
channel::Sender,
|
||||
lock::{Mutex, RwLock},
|
||||
};
|
||||
use socketioxide::extract::SocketRef;
|
||||
|
||||
use crate::{
|
||||
machines::{
|
||||
identification::MachineIdentificationUnique,
|
||||
new::{MachineNewHardware, MachineNewHardwareEthercat, MachineNewParams},
|
||||
},
|
||||
serial::SerialDevice,
|
||||
socketio::event::GenericEvent,
|
||||
};
|
||||
use std::{
|
||||
collections::HashMap,
|
||||
sync::{Arc, Weak},
|
||||
};
|
||||
|
||||
use super::{
|
||||
Machine,
|
||||
identification::{DeviceIdentification, DeviceIdentificationIdentified},
|
||||
new::MachineNewHardwareSerial,
|
||||
registry::MachineRegistry,
|
||||
};
|
||||
#[derive(Debug)]
|
||||
pub struct MachineManager {
|
||||
pub ethercat_machines:
|
||||
HashMap<MachineIdentificationUnique, Result<Arc<Mutex<dyn Machine>>, anyhow::Error>>,
|
||||
pub serial_machines:
|
||||
HashMap<MachineIdentificationUnique, Result<Arc<Mutex<dyn Machine>>, anyhow::Error>>,
|
||||
}
|
||||
|
||||
impl Default for MachineManager {
|
||||
fn default() -> Self {
|
||||
Self::new()
|
||||
}
|
||||
}
|
||||
|
||||
impl MachineManager {
|
||||
pub fn new() -> Self {
|
||||
Self {
|
||||
ethercat_machines: HashMap::new(),
|
||||
serial_machines: HashMap::new(),
|
||||
}
|
||||
}
|
||||
|
||||
pub fn set_ethercat_devices<const MAX_SUBDEVICES: usize, const MAX_PDI: usize>(
|
||||
&mut self,
|
||||
device_identifications: &Vec<DeviceIdentification>,
|
||||
machine_registry: &MachineRegistry,
|
||||
hardware: &MachineNewHardwareEthercat,
|
||||
socket_queue_tx: Sender<(SocketRef, Arc<GenericEvent>)>,
|
||||
machine_manager: Weak<RwLock<Self>>,
|
||||
) {
|
||||
// empty ethercat machines
|
||||
self.ethercat_machines.clear();
|
||||
|
||||
// group devices by machine device identification
|
||||
let device_grouping_result = group_devices_by_identification(device_identifications);
|
||||
|
||||
tracing::info!(
|
||||
"Device Groups {}",
|
||||
device_grouping_result.device_groups.len()
|
||||
);
|
||||
|
||||
let machine_new_hardware = MachineNewHardware::Ethercat(hardware);
|
||||
|
||||
// iterate over all identified device groups but ignore unaffected machines
|
||||
for device_group in device_grouping_result.device_groups.iter() {
|
||||
// get the machine identification
|
||||
let machine_identification = match device_group.first() {
|
||||
Some(device_identification) => &device_identification.device_machine_identification,
|
||||
None => continue, // Skip this group if empty
|
||||
};
|
||||
|
||||
// create the machine
|
||||
let new_machine = machine_registry.new_machine(&MachineNewParams {
|
||||
device_group,
|
||||
hardware: &machine_new_hardware,
|
||||
socket_queue_tx: socket_queue_tx.clone(),
|
||||
machine_manager: machine_manager.clone(),
|
||||
});
|
||||
|
||||
// insert the machine into the ethercat machines map
|
||||
self.ethercat_machines.insert(
|
||||
machine_identification.machine_identification_unique.clone(),
|
||||
new_machine,
|
||||
);
|
||||
}
|
||||
}
|
||||
|
||||
pub fn get(
|
||||
&self,
|
||||
machine_identification: &MachineIdentificationUnique,
|
||||
) -> Option<&Result<Arc<Mutex<dyn Machine>>, anyhow::Error>> {
|
||||
self.ethercat_machines
|
||||
.get(machine_identification)
|
||||
.or_else(|| self.serial_machines.get(machine_identification))
|
||||
}
|
||||
|
||||
pub fn add_serial_device(
|
||||
&mut self,
|
||||
device_identification: &DeviceIdentification,
|
||||
device: Arc<RwLock<dyn SerialDevice>>,
|
||||
machine_registry: &MachineRegistry,
|
||||
socket_queue_tx: Sender<(SocketRef, Arc<GenericEvent>)>,
|
||||
machine_manager: Weak<RwLock<Self>>,
|
||||
) {
|
||||
let hardware = MachineNewHardwareSerial { device };
|
||||
|
||||
let device_identification_identified: DeviceIdentificationIdentified =
|
||||
device_identification
|
||||
.clone()
|
||||
.try_into()
|
||||
.expect("Serial devices always have machine identification");
|
||||
|
||||
let new_machine = machine_registry.new_machine(&MachineNewParams {
|
||||
device_group: &vec![device_identification_identified.clone()],
|
||||
hardware: &MachineNewHardware::Serial(&hardware),
|
||||
socket_queue_tx,
|
||||
machine_manager,
|
||||
});
|
||||
|
||||
tracing::info!("Adding serial machine {:?}", new_machine);
|
||||
|
||||
self.serial_machines.insert(
|
||||
device_identification_identified
|
||||
.device_machine_identification
|
||||
.machine_identification_unique,
|
||||
new_machine,
|
||||
);
|
||||
}
|
||||
|
||||
pub fn remove_serial_device(&mut self, device_identification: &DeviceIdentification) {
|
||||
let device_identification_identified: DeviceIdentificationIdentified =
|
||||
device_identification
|
||||
.clone()
|
||||
.try_into()
|
||||
.expect("Serial devices always have machine identification");
|
||||
|
||||
tracing::info!(
|
||||
"Removing serial machine {:?}",
|
||||
device_identification_identified
|
||||
);
|
||||
|
||||
self.serial_machines.remove(
|
||||
&device_identification_identified
|
||||
.device_machine_identification
|
||||
.machine_identification_unique,
|
||||
);
|
||||
}
|
||||
|
||||
pub fn get_machine_weak(
|
||||
&self,
|
||||
machine_identification: &MachineIdentificationUnique,
|
||||
) -> Option<Weak<Mutex<dyn Machine>>> {
|
||||
let machine = self.ethercat_machines.get(machine_identification);
|
||||
let machine = match machine {
|
||||
Some(machine) => machine,
|
||||
None => {
|
||||
return None;
|
||||
}
|
||||
};
|
||||
let machine = match machine {
|
||||
Ok(machine) => machine,
|
||||
Err(_) => {
|
||||
return None;
|
||||
}
|
||||
};
|
||||
let machine_weak = Arc::downgrade(machine);
|
||||
Some(machine_weak)
|
||||
}
|
||||
|
||||
pub fn get_serial_weak(
|
||||
&self,
|
||||
machine_identification: &MachineIdentificationUnique,
|
||||
) -> Option<Weak<Mutex<dyn Machine>>> {
|
||||
let machine = self.serial_machines.get(machine_identification);
|
||||
let machine = match machine {
|
||||
Some(machine) => machine,
|
||||
None => {
|
||||
return None;
|
||||
}
|
||||
};
|
||||
let machine = match machine {
|
||||
Ok(machine) => machine,
|
||||
Err(_) => {
|
||||
return None;
|
||||
}
|
||||
};
|
||||
let machine_weak = Arc::downgrade(machine);
|
||||
Some(machine_weak)
|
||||
}
|
||||
}
|
||||
|
||||
/// Groups devices by machine identification
|
||||
///
|
||||
/// Returns a DeviceGroupingResult containing:
|
||||
/// - device_groups: a vector of devices grouped by machine identification
|
||||
/// - unidentified_devices: a vector of devices that could not be identified
|
||||
pub fn group_devices_by_identification(
|
||||
device_identifications: &Vec<DeviceIdentification>,
|
||||
) -> DeviceGroupingResult {
|
||||
let mut device_groups: Vec<Vec<DeviceIdentificationIdentified>> = Vec::new();
|
||||
let mut unidentified_devices: Vec<DeviceIdentification> = Vec::new();
|
||||
|
||||
for device_identification in device_identifications {
|
||||
// if vendor or serial or machine is 0, it is not a valid machine device
|
||||
if let Some(device_machine_identification) =
|
||||
device_identification.device_machine_identification.as_ref()
|
||||
{
|
||||
if !device_machine_identification.is_valid() {
|
||||
unidentified_devices.push(device_identification.clone());
|
||||
|
||||
continue;
|
||||
}
|
||||
} else {
|
||||
unidentified_devices.push(device_identification.clone());
|
||||
continue;
|
||||
}
|
||||
|
||||
// scan over all deice groups
|
||||
// get the first DeviceMachineIdentification
|
||||
// compare and append to the group
|
||||
let mut found = false;
|
||||
for check_group in device_groups.iter_mut() {
|
||||
// get first device in group
|
||||
let first_device = check_group.first().expect("group to not be empty");
|
||||
let first_device_machine_identification = &first_device
|
||||
.device_machine_identification
|
||||
.machine_identification_unique;
|
||||
|
||||
// chek if it has machine identification
|
||||
if let Some(device_machine_identification) =
|
||||
device_identification.device_machine_identification.as_ref()
|
||||
{
|
||||
// compare with the current device
|
||||
if first_device_machine_identification
|
||||
== &device_machine_identification.machine_identification_unique
|
||||
{
|
||||
let device_identification_identified = device_identification
|
||||
.clone()
|
||||
.try_into()
|
||||
.expect("should have Some(DeviceMachineIdentification)");
|
||||
check_group.push(device_identification_identified);
|
||||
found = true;
|
||||
break;
|
||||
}
|
||||
}
|
||||
}
|
||||
|
||||
if !found {
|
||||
let device_identification_identified = device_identification
|
||||
.clone()
|
||||
.try_into()
|
||||
.expect("should have Some(DeviceMachineIdentification)");
|
||||
device_groups.push(vec![device_identification_identified]);
|
||||
}
|
||||
}
|
||||
|
||||
DeviceGroupingResult {
|
||||
device_groups,
|
||||
unidentified_devices,
|
||||
}
|
||||
}
|
||||
|
||||
/// Structure to hold the result of grouping devices by identification
|
||||
#[derive(Debug)]
|
||||
pub struct DeviceGroupingResult {
|
||||
/// Devices grouped by machine identification
|
||||
pub device_groups: Vec<Vec<DeviceIdentificationIdentified>>,
|
||||
/// Devices that could not be identified
|
||||
pub unidentified_devices: Vec<DeviceIdentification>,
|
||||
}
|
||||
@@ -1,82 +0,0 @@
|
||||
use std::{collections::HashMap, sync::Arc};
|
||||
|
||||
use smol::lock::Mutex;
|
||||
|
||||
use super::{Machine, identification::MachineIdentificationUnique, manager::MachineManager};
|
||||
|
||||
pub enum MachineManagerIter<'a> {
|
||||
EthercatMachines {
|
||||
iter: std::collections::hash_map::Iter<
|
||||
'a,
|
||||
MachineIdentificationUnique,
|
||||
Result<Arc<Mutex<dyn Machine>>, anyhow::Error>,
|
||||
>,
|
||||
},
|
||||
SerialMachines {
|
||||
iter: std::collections::hash_map::Iter<
|
||||
'a,
|
||||
MachineIdentificationUnique,
|
||||
Result<Arc<Mutex<dyn Machine>>, anyhow::Error>,
|
||||
>,
|
||||
},
|
||||
Done,
|
||||
}
|
||||
|
||||
pub struct MachineManagerIterator<'a> {
|
||||
iter: MachineManagerIter<'a>,
|
||||
serial_machines:
|
||||
&'a HashMap<MachineIdentificationUnique, Result<Arc<Mutex<dyn Machine>>, anyhow::Error>>,
|
||||
}
|
||||
|
||||
impl<'a> Iterator for MachineManagerIterator<'a> {
|
||||
type Item = (
|
||||
&'a MachineIdentificationUnique,
|
||||
&'a Result<Arc<Mutex<dyn Machine>>, anyhow::Error>,
|
||||
);
|
||||
|
||||
fn next(&mut self) -> Option<Self::Item> {
|
||||
loop {
|
||||
match &mut self.iter {
|
||||
MachineManagerIter::EthercatMachines { iter } => {
|
||||
// Try to get the next item from ethercat_machines
|
||||
if let Some(item) = iter.next() {
|
||||
return Some(item);
|
||||
} else {
|
||||
// If ethercat_machines is exhausted, move to serial_machines
|
||||
self.iter = MachineManagerIter::SerialMachines {
|
||||
iter: self.serial_machines.iter(),
|
||||
};
|
||||
// Continue to the next iteration of the loop
|
||||
continue;
|
||||
}
|
||||
}
|
||||
MachineManagerIter::SerialMachines { iter } => {
|
||||
// Return the next item from serial_machines or None if exhausted
|
||||
if let Some(item) = iter.next() {
|
||||
return Some(item);
|
||||
} else {
|
||||
// If serial_machines is also exhausted, we're done
|
||||
self.iter = MachineManagerIter::Done;
|
||||
return None;
|
||||
}
|
||||
}
|
||||
MachineManagerIter::Done => {
|
||||
// We've exhausted both collections
|
||||
return None;
|
||||
}
|
||||
}
|
||||
}
|
||||
}
|
||||
}
|
||||
|
||||
impl MachineManager {
|
||||
// Returns an iterator over all machines (both ethercat and serial)
|
||||
pub fn iter(&'_ self) -> MachineManagerIterator<'_> {
|
||||
MachineManagerIterator {
|
||||
iter: MachineManagerIter::EthercatMachines {
|
||||
iter: self.ethercat_machines.iter(),
|
||||
},
|
||||
serial_machines: &self.serial_machines,
|
||||
}
|
||||
}
|
||||
}
|
||||
@@ -1,83 +0,0 @@
|
||||
use anyhow::anyhow;
|
||||
use api::MachineApi;
|
||||
use new::MachineNewTrait;
|
||||
use serde::Serialize;
|
||||
use smol::lock::Mutex;
|
||||
use std::any::Any;
|
||||
use std::fmt::Debug;
|
||||
use std::sync::{Arc, Weak};
|
||||
|
||||
use crate::machines::identification::MachineIdentificationUnique;
|
||||
use crate::machines::new::MachineAct;
|
||||
pub mod api;
|
||||
pub mod identification;
|
||||
pub mod manager;
|
||||
pub mod manager_iter;
|
||||
pub mod new;
|
||||
pub mod registry;
|
||||
|
||||
pub trait Machine: MachineAct + MachineNewTrait + MachineApi + AnyGetters + Debug + Send {}
|
||||
pub trait AnyGetters: Any {
|
||||
fn as_any(&self) -> &dyn Any;
|
||||
fn as_any_mut(&mut self) -> &mut dyn Any;
|
||||
}
|
||||
|
||||
/// Casts a `dyn Machine` to a specific machine type
|
||||
pub async fn downcast_machine<T: Machine>(
|
||||
machine: Arc<Mutex<dyn Machine>>,
|
||||
) -> Result<Arc<Mutex<T>>, anyhow::Error> {
|
||||
// Acquire a read lock on the RwLock
|
||||
let read_lock = machine.lock().await;
|
||||
|
||||
// Check if the inner type can be downcasted to T
|
||||
if read_lock.as_any().is::<T>() {
|
||||
// Clone the Arc and return it as the desired type
|
||||
let cloned_machine = Arc::clone(&machine);
|
||||
// Transmute the Arc to the desired type
|
||||
unsafe {
|
||||
Ok(Arc::from_raw(
|
||||
Arc::into_raw(cloned_machine) as *const Mutex<T>
|
||||
))
|
||||
}
|
||||
} else {
|
||||
Err(anyhow!(
|
||||
"[{}::downcast_machine] Downcast failed",
|
||||
module_path!()
|
||||
))
|
||||
}
|
||||
}
|
||||
|
||||
/// Trait to get strong count to see if Weak has reference
|
||||
pub trait GetStrongCount {
|
||||
fn get_strong_count(&self) -> usize;
|
||||
}
|
||||
|
||||
impl<T> GetStrongCount for Weak<Mutex<T>> {
|
||||
fn get_strong_count(&self) -> usize {
|
||||
self.strong_count()
|
||||
}
|
||||
}
|
||||
|
||||
#[derive(Debug)]
|
||||
pub struct ConnectedMachine<T: GetStrongCount> {
|
||||
pub machine_identification_unique: MachineIdentificationUnique,
|
||||
pub machine: T,
|
||||
}
|
||||
|
||||
#[derive(Serialize, Debug, Clone, PartialEq, Eq)]
|
||||
pub struct ConnectedMachineData {
|
||||
pub machine_identification_unique: MachineIdentificationUnique,
|
||||
pub is_available: bool,
|
||||
}
|
||||
|
||||
impl<T> From<&ConnectedMachine<T>> for ConnectedMachineData
|
||||
where
|
||||
T: GetStrongCount,
|
||||
{
|
||||
fn from(value: &ConnectedMachine<T>) -> Self {
|
||||
Self {
|
||||
machine_identification_unique: value.machine_identification_unique.clone(),
|
||||
is_available: value.machine.get_strong_count() != 0,
|
||||
}
|
||||
}
|
||||
}
|
||||
@@ -1,259 +0,0 @@
|
||||
use crate::{machines::manager::MachineManager, serial::SerialDevice};
|
||||
|
||||
use super::identification::DeviceIdentificationIdentified;
|
||||
use anyhow::Error;
|
||||
use ethercat_hal::{
|
||||
devices::EthercatDevice, helpers::ethercrab_types::EthercrabSubDevicePreoperational,
|
||||
};
|
||||
use ethercrab::{SubDevice, SubDeviceRef};
|
||||
use smol::{channel::Sender, lock::RwLock};
|
||||
use socketioxide::extract::SocketRef;
|
||||
use std::{
|
||||
sync::{Arc, Weak},
|
||||
time::Instant,
|
||||
};
|
||||
|
||||
use crate::socketio::event::GenericEvent;
|
||||
|
||||
pub trait MachineNewTrait {
|
||||
fn new(params: &MachineNewParams<'_, '_, '_, '_, '_, '_, '_>) -> Result<Self, Error>
|
||||
where
|
||||
Self: Sized;
|
||||
}
|
||||
|
||||
pub trait MachineAct {
|
||||
fn act(&mut self, now: Instant);
|
||||
}
|
||||
|
||||
pub struct MachineNewParams<
|
||||
'maindevice,
|
||||
'subdevices,
|
||||
'device_identifications_identified,
|
||||
'ethercat_devices,
|
||||
'machine_new_hardware_etehrcat,
|
||||
'machine_new_hardware_serial,
|
||||
'machine_new_hardware,
|
||||
> where
|
||||
'maindevice: 'machine_new_hardware,
|
||||
'subdevices: 'machine_new_hardware,
|
||||
'ethercat_devices: 'machine_new_hardware,
|
||||
'machine_new_hardware_etehrcat: 'machine_new_hardware,
|
||||
{
|
||||
pub device_group: &'device_identifications_identified Vec<DeviceIdentificationIdentified>,
|
||||
pub hardware: &'machine_new_hardware MachineNewHardware<
|
||||
'maindevice,
|
||||
'subdevices,
|
||||
'ethercat_devices,
|
||||
'machine_new_hardware_etehrcat,
|
||||
'machine_new_hardware_serial,
|
||||
>,
|
||||
pub socket_queue_tx: Sender<(SocketRef, Arc<GenericEvent>)>,
|
||||
pub machine_manager: Weak<RwLock<MachineManager>>,
|
||||
}
|
||||
|
||||
pub enum MachineNewHardware<
|
||||
'maindevice,
|
||||
'subdevices,
|
||||
'ethercat_devices,
|
||||
'machine_new_hardware_etehrcat,
|
||||
'machine_new_hardware_serial,
|
||||
> where
|
||||
'maindevice: 'machine_new_hardware_etehrcat,
|
||||
'subdevices: 'machine_new_hardware_etehrcat,
|
||||
'ethercat_devices: 'machine_new_hardware_etehrcat,
|
||||
{
|
||||
Ethercat(
|
||||
&'machine_new_hardware_etehrcat MachineNewHardwareEthercat<
|
||||
'maindevice,
|
||||
'subdevices,
|
||||
'ethercat_devices,
|
||||
>,
|
||||
),
|
||||
Serial(&'machine_new_hardware_serial MachineNewHardwareSerial),
|
||||
}
|
||||
|
||||
pub struct MachineNewHardwareEthercat<'maindevice, 'subdevices, 'ethercat_devices> {
|
||||
pub subdevices:
|
||||
&'subdevices Vec<&'subdevices SubDeviceRef<'maindevice, &'subdevices SubDevice>>,
|
||||
pub ethercat_devices: &'ethercat_devices Vec<Arc<RwLock<dyn EthercatDevice>>>,
|
||||
}
|
||||
|
||||
pub struct MachineNewHardwareSerial {
|
||||
pub device: Arc<RwLock<dyn SerialDevice>>,
|
||||
}
|
||||
|
||||
// validates that all devices in the group have the same machine identification
|
||||
pub fn validate_same_machine_identification_unique(
|
||||
identified_device_group: &Vec<DeviceIdentificationIdentified>,
|
||||
) -> Result<(), Error> {
|
||||
let machine_identification_unique = &identified_device_group
|
||||
.first()
|
||||
.ok_or_else(|| {
|
||||
anyhow::anyhow!(
|
||||
"[{}::validate_same_machine_identification] No devices in group",
|
||||
module_path!()
|
||||
)
|
||||
})?
|
||||
.device_machine_identification
|
||||
.machine_identification_unique;
|
||||
for device in identified_device_group.iter() {
|
||||
if device
|
||||
.device_machine_identification
|
||||
.machine_identification_unique
|
||||
!= *machine_identification_unique
|
||||
{
|
||||
return Err(anyhow::anyhow!(
|
||||
"[{}::validate_same_machine_identification] Different machine identifications",
|
||||
module_path!()
|
||||
));
|
||||
}
|
||||
}
|
||||
Ok(())
|
||||
}
|
||||
|
||||
/// validates that every role is unique
|
||||
pub fn validate_no_role_dublicates(
|
||||
identified_device_group: &Vec<DeviceIdentificationIdentified>,
|
||||
) -> Result<(), Error> {
|
||||
let mut roles = vec![];
|
||||
for device in identified_device_group.iter() {
|
||||
if roles.contains(&device.device_machine_identification.role) {
|
||||
return Err(anyhow::anyhow!(
|
||||
"[{}::validate_no_role_dublicates] Role dublicate",
|
||||
module_path!(),
|
||||
));
|
||||
}
|
||||
roles.push(device.device_machine_identification.role);
|
||||
}
|
||||
Ok(())
|
||||
}
|
||||
|
||||
// Inside control_core::machines::new module:
|
||||
pub fn get_device_identification_by_role(
|
||||
identified_device_group: &Vec<DeviceIdentificationIdentified>,
|
||||
role: u16,
|
||||
) -> Result<&DeviceIdentificationIdentified, Error> {
|
||||
for device in identified_device_group.iter() {
|
||||
if device.device_machine_identification.role == role {
|
||||
return Ok(device);
|
||||
}
|
||||
}
|
||||
Err(anyhow::anyhow!(
|
||||
"[{}::get_device_identification_by_role] Role {} not found",
|
||||
module_path!(),
|
||||
role
|
||||
))
|
||||
}
|
||||
|
||||
pub fn get_device_by_index<'maindevice>(
|
||||
devices: &Vec<Arc<RwLock<dyn EthercatDevice>>>,
|
||||
subdevice_index: usize,
|
||||
) -> Result<Arc<RwLock<dyn EthercatDevice>>, Error> {
|
||||
Ok(devices
|
||||
.get(subdevice_index)
|
||||
.ok_or(anyhow::anyhow!(
|
||||
"[{}::get_device_by_index] Index {} out of bounds for devices",
|
||||
module_path!(),
|
||||
subdevice_index
|
||||
))?
|
||||
.clone())
|
||||
}
|
||||
|
||||
pub fn get_subdevice_by_index<'subdevices, 'maindevice>(
|
||||
subdevices: &'subdevices Vec<&EthercrabSubDevicePreoperational<'maindevice>>,
|
||||
subdevice_index: usize,
|
||||
) -> Result<&'subdevices EthercrabSubDevicePreoperational<'maindevice>, Error> {
|
||||
Ok(subdevices.get(subdevice_index).ok_or(anyhow::anyhow!(
|
||||
"Index {} out of bounds for subdevices",
|
||||
subdevice_index
|
||||
))?)
|
||||
}
|
||||
|
||||
pub fn get_ethercat_device_by_index<'maindevice>(
|
||||
ethercat_devices: &Vec<Arc<RwLock<dyn EthercatDevice>>>,
|
||||
subdevice_index: usize,
|
||||
) -> Result<Arc<RwLock<dyn EthercatDevice>>, Error> {
|
||||
Ok(ethercat_devices
|
||||
.get(subdevice_index)
|
||||
.ok_or(anyhow::anyhow!(
|
||||
"[{}::get_ethercat_device_by_index] Index {} out of bounds for ethercat devices",
|
||||
module_path!(),
|
||||
subdevice_index
|
||||
))?
|
||||
.clone())
|
||||
}
|
||||
|
||||
#[cfg(test)]
|
||||
mod tests {
|
||||
use crate::machines::identification::{
|
||||
DeviceHardwareIdentification, DeviceHardwareIdentificationEthercat,
|
||||
DeviceMachineIdentification, MachineIdentification, MachineIdentificationUnique,
|
||||
};
|
||||
|
||||
pub use super::*;
|
||||
|
||||
#[test]
|
||||
fn test_get_device_identification_by_role() {
|
||||
let device_identifications = vec![
|
||||
// role 0
|
||||
DeviceIdentificationIdentified {
|
||||
device_machine_identification: DeviceMachineIdentification {
|
||||
machine_identification_unique: MachineIdentificationUnique {
|
||||
machine_identification: MachineIdentification {
|
||||
vendor: 1,
|
||||
machine: 1,
|
||||
},
|
||||
serial: 1,
|
||||
},
|
||||
role: 0,
|
||||
},
|
||||
device_hardware_identification: DeviceHardwareIdentification::Ethercat(
|
||||
DeviceHardwareIdentificationEthercat { subdevice_index: 0 },
|
||||
),
|
||||
},
|
||||
// role 1
|
||||
DeviceIdentificationIdentified {
|
||||
device_machine_identification: DeviceMachineIdentification {
|
||||
machine_identification_unique: MachineIdentificationUnique {
|
||||
machine_identification: MachineIdentification {
|
||||
vendor: 2,
|
||||
machine: 2,
|
||||
},
|
||||
serial: 2,
|
||||
},
|
||||
role: 2,
|
||||
},
|
||||
device_hardware_identification: DeviceHardwareIdentification::Ethercat(
|
||||
DeviceHardwareIdentificationEthercat { subdevice_index: 1 },
|
||||
),
|
||||
},
|
||||
// role 2
|
||||
DeviceIdentificationIdentified {
|
||||
device_machine_identification: DeviceMachineIdentification {
|
||||
machine_identification_unique: MachineIdentificationUnique {
|
||||
machine_identification: MachineIdentification {
|
||||
vendor: 3,
|
||||
machine: 3,
|
||||
},
|
||||
serial: 3,
|
||||
},
|
||||
role: 1,
|
||||
},
|
||||
device_hardware_identification: DeviceHardwareIdentification::Ethercat(
|
||||
DeviceHardwareIdentificationEthercat { subdevice_index: 2 },
|
||||
),
|
||||
},
|
||||
];
|
||||
|
||||
// search for role 0
|
||||
let result = get_device_identification_by_role(&device_identifications, 0);
|
||||
assert_eq!(result.unwrap().device_machine_identification.role, 0,);
|
||||
|
||||
// search for role 1
|
||||
let result = get_device_identification_by_role(&device_identifications, 1);
|
||||
assert_eq!(result.unwrap().device_machine_identification.role, 1,);
|
||||
// search for role 2
|
||||
let result = get_device_identification_by_role(&device_identifications, 2);
|
||||
assert_eq!(result.unwrap().device_machine_identification.role, 2,);
|
||||
}
|
||||
}
|
||||
@@ -1,74 +0,0 @@
|
||||
use super::{Machine, identification::MachineIdentification, new::MachineNewParams};
|
||||
use anyhow::Error;
|
||||
use smol::lock::Mutex;
|
||||
use std::{any::TypeId, collections::HashMap, sync::Arc};
|
||||
|
||||
pub type MachineNewClosure =
|
||||
Box<dyn Fn(&MachineNewParams) -> Result<Arc<Mutex<dyn Machine>>, Error> + Send + Sync>;
|
||||
|
||||
pub struct MachineRegistry {
|
||||
type_map: HashMap<TypeId, (MachineIdentification, MachineNewClosure)>,
|
||||
}
|
||||
|
||||
impl Default for MachineRegistry {
|
||||
fn default() -> Self {
|
||||
Self::new()
|
||||
}
|
||||
}
|
||||
|
||||
impl MachineRegistry {
|
||||
pub fn new() -> Self {
|
||||
Self {
|
||||
type_map: HashMap::new(),
|
||||
}
|
||||
}
|
||||
|
||||
pub fn register<T: Machine + 'static>(
|
||||
&mut self,
|
||||
machine_identficiation: MachineIdentification,
|
||||
) {
|
||||
self.type_map.insert(
|
||||
TypeId::of::<T>(),
|
||||
(
|
||||
machine_identficiation.clone(),
|
||||
// create a machine construction closure
|
||||
Box::new(|machine_new_params| {
|
||||
Ok(Arc::new(Mutex::new(T::new(machine_new_params)?)))
|
||||
}),
|
||||
),
|
||||
);
|
||||
}
|
||||
|
||||
pub fn new_machine(
|
||||
&self,
|
||||
machine_new_params: &MachineNewParams,
|
||||
) -> Result<Arc<Mutex<dyn Machine>>, anyhow::Error> {
|
||||
// get machiine identification
|
||||
let device_identification =
|
||||
&machine_new_params
|
||||
.device_group
|
||||
.first()
|
||||
.ok_or(anyhow::anyhow!(
|
||||
"[{}::MachineConstructor::new_machine] No device in group",
|
||||
module_path!()
|
||||
))?;
|
||||
|
||||
// find machine new function by comparing MachineIdentification
|
||||
let (_, machine_new_closure) = self
|
||||
.type_map
|
||||
.values()
|
||||
.find(|(mi, _)| {
|
||||
mi == &device_identification
|
||||
.device_machine_identification
|
||||
.machine_identification_unique
|
||||
.machine_identification
|
||||
})
|
||||
.ok_or(anyhow::anyhow!(
|
||||
"[{}::MachineConstructor::new_machine] Machine not found",
|
||||
module_path!()
|
||||
))?;
|
||||
|
||||
// call machine new function by reference
|
||||
(machine_new_closure)(machine_new_params)
|
||||
}
|
||||
}
|
||||
@@ -1,4 +1,5 @@
|
||||
pub mod modbus_serial_interface;
|
||||
pub mod tcp;
|
||||
|
||||
use anyhow::Error;
|
||||
use crc::{CRC_16_MODBUS, Crc};
|
||||
|
||||
@@ -0,0 +1,263 @@
|
||||
use std::fmt::Debug;
|
||||
use std::io::ErrorKind;
|
||||
use std::net::SocketAddr;
|
||||
use std::time::Duration;
|
||||
|
||||
use anyhow::Context;
|
||||
use anyhow::Result;
|
||||
use anyhow::bail;
|
||||
use smol::Timer;
|
||||
use smol::future::FutureExt;
|
||||
use smol::io;
|
||||
use smol::io::AsyncReadExt;
|
||||
use smol::io::AsyncWriteExt;
|
||||
use smol::net::TcpStream;
|
||||
|
||||
const PROTOCOL_ID: u16 = 0;
|
||||
const UNIT_ID: u8 = 0;
|
||||
const READ_HOLDING_FUNCTION_CODE: u8 = 3;
|
||||
const WRITE_HOLDING_FUNCTION_CODE: u8 = 16;
|
||||
const READ_HOLDING_LENGTH: u16 = 6; // Unit ID 00 + Func Code 03 + Start Address XXXX + Quantity XXXX = 6 bytes
|
||||
const WRITE_HOLDING_LENGTH_WITHOUT_DATA: u16 = 7; // Unit ID 00 + Func Code 16 + Start Address XXXX + Quantity XXXX + Num Data Bytes XX = 7 bytes
|
||||
|
||||
struct Packet {
|
||||
buf: Vec<u8>,
|
||||
}
|
||||
|
||||
impl Packet {
|
||||
pub const fn new() -> Self {
|
||||
Self { buf: Vec::new() }
|
||||
}
|
||||
|
||||
pub fn add_u8(&mut self, x: u8) {
|
||||
self.buf.push(x);
|
||||
}
|
||||
|
||||
pub fn add_u16(&mut self, x: u16) {
|
||||
let buf = x.to_be_bytes();
|
||||
self.buf.push(buf[0]);
|
||||
self.buf.push(buf[1]);
|
||||
}
|
||||
|
||||
pub fn as_bytes(&self) -> &[u8] {
|
||||
&self.buf
|
||||
}
|
||||
}
|
||||
|
||||
pub struct ModbusTcpDevice {
|
||||
stream: TcpStream,
|
||||
transactions: u16,
|
||||
}
|
||||
|
||||
impl Debug for ModbusTcpDevice {
|
||||
fn fmt(&self, f: &mut std::fmt::Formatter<'_>) -> std::fmt::Result {
|
||||
match self.stream.peer_addr() {
|
||||
Ok(addr) => write!(f, "ModbusTcpDevice({:?})", addr),
|
||||
Err(_) => std::fmt::Result::Err(std::fmt::Error),
|
||||
}
|
||||
}
|
||||
}
|
||||
|
||||
impl ModbusTcpDevice {
|
||||
pub async fn new(addr: SocketAddr) -> Result<Self> {
|
||||
let timeout = async {
|
||||
Timer::after(Duration::from_millis(10)).await;
|
||||
Err(io::Error::from(ErrorKind::TimedOut))
|
||||
};
|
||||
|
||||
let stream = TcpStream::connect(addr)
|
||||
.or(timeout)
|
||||
.await
|
||||
.context("Could not connect to modbus device!")?;
|
||||
|
||||
Ok(Self {
|
||||
stream,
|
||||
transactions: 0,
|
||||
})
|
||||
}
|
||||
|
||||
async fn read_and_check_responce_header(&mut self, func_code: u8) -> Result<()> {
|
||||
if self.read_u16().await? != self.transactions {
|
||||
bail!("Modbus device sent unexpected transaction id!");
|
||||
}
|
||||
|
||||
if self.read_u16().await? != PROTOCOL_ID {
|
||||
bail!("Modbus device sent unexpected protocol id!");
|
||||
}
|
||||
|
||||
let length = self.read_u16().await?;
|
||||
if length < 2 {
|
||||
bail!("Modbus device will send too few bytes to understand the response!");
|
||||
}
|
||||
|
||||
if self.read_u8().await? != UNIT_ID {
|
||||
bail!("Modbus device sent unexpected unit id!");
|
||||
}
|
||||
|
||||
let func_code_res = self.read_u8().await?;
|
||||
if func_code != func_code_res {
|
||||
let error_code = self.read_u8().await?;
|
||||
bail!(
|
||||
"Modbus device sent unexpected function code 0x{:x}! It probably encountered an error. Error code: 0x{:x}",
|
||||
func_code_res,
|
||||
error_code
|
||||
);
|
||||
}
|
||||
|
||||
Ok(())
|
||||
}
|
||||
|
||||
async fn send_read_holding_request(&mut self, addr: u16, count: u16) -> Result<u16> {
|
||||
let mut packet = Packet::new();
|
||||
|
||||
self.transactions += 1;
|
||||
packet.add_u16(self.transactions);
|
||||
packet.add_u16(PROTOCOL_ID);
|
||||
packet.add_u16(READ_HOLDING_LENGTH);
|
||||
|
||||
packet.add_u8(UNIT_ID);
|
||||
packet.add_u8(READ_HOLDING_FUNCTION_CODE);
|
||||
|
||||
packet.add_u16(addr);
|
||||
packet.add_u16(count);
|
||||
|
||||
self.send(packet).await?;
|
||||
self.read_and_check_responce_header(READ_HOLDING_FUNCTION_CODE)
|
||||
.await?;
|
||||
|
||||
let num_data_bytes = self.read_u8().await? as u16;
|
||||
if count * 2 != num_data_bytes {
|
||||
bail!(
|
||||
"Modbus device wants to send only a portion of the requested range - UNIMPLEMENTED!"
|
||||
);
|
||||
}
|
||||
|
||||
Ok(num_data_bytes)
|
||||
}
|
||||
|
||||
pub async fn get_holding_registers(&mut self, addr: u16, count: u16) -> Result<Vec<u16>> {
|
||||
self.send_read_holding_request(addr, count).await?;
|
||||
|
||||
let mut res: Vec<u16> = Vec::new();
|
||||
while res.len() < count as usize {
|
||||
res.push(self.read_u16().await?);
|
||||
}
|
||||
|
||||
Ok(res)
|
||||
}
|
||||
|
||||
pub async fn set_holding_registers(&mut self, addr: u16, values: &[u16]) -> Result<()> {
|
||||
let count = values.len();
|
||||
let num_bytes = count * 2;
|
||||
assert!(
|
||||
count <= 128,
|
||||
"Cannot send that many bytes to modbus device in one go! Trying to send {} bytes of data.",
|
||||
num_bytes
|
||||
);
|
||||
|
||||
let mut packet = Packet::new();
|
||||
|
||||
self.transactions += 1;
|
||||
packet.add_u16(self.transactions);
|
||||
packet.add_u16(PROTOCOL_ID);
|
||||
packet.add_u16(WRITE_HOLDING_LENGTH_WITHOUT_DATA + num_bytes as u16);
|
||||
|
||||
packet.add_u8(UNIT_ID);
|
||||
packet.add_u8(WRITE_HOLDING_FUNCTION_CODE);
|
||||
|
||||
packet.add_u16(addr);
|
||||
packet.add_u16(count as u16);
|
||||
|
||||
packet.add_u8(num_bytes as u8);
|
||||
|
||||
for value in values {
|
||||
packet.add_u16(value.to_owned());
|
||||
}
|
||||
|
||||
self.send(packet).await?;
|
||||
self.read_and_check_responce_header(WRITE_HOLDING_FUNCTION_CODE)
|
||||
.await?;
|
||||
|
||||
if self.read_u16().await? != addr {
|
||||
bail!("Modbus device wrote to wrong register address!");
|
||||
}
|
||||
|
||||
if self.read_u16().await? != count as u16 {
|
||||
bail!("Modbus device wrote wrong number of registers!");
|
||||
}
|
||||
|
||||
Ok(())
|
||||
}
|
||||
|
||||
pub async fn get_string<const N: usize>(&mut self, addr: u16) -> Result<String> {
|
||||
assert!(N % 2 == 0, "Strings are always of even length!");
|
||||
assert!(N <= 256, "Cannot read long strings in a single swoop!");
|
||||
let count = N / 2;
|
||||
|
||||
self.send_read_holding_request(addr, count as u16).await?;
|
||||
let buf = self.read_bytes::<N>().await?;
|
||||
|
||||
let s = String::from_utf8_lossy(&buf);
|
||||
let s = match s.split_once('\0') {
|
||||
None => s.to_string(),
|
||||
Some((l, _)) => l.to_string(),
|
||||
};
|
||||
|
||||
Ok(s)
|
||||
}
|
||||
|
||||
pub async fn set_string<const N: usize>(&mut self, _addr: u16, s: &str) -> Result<()> {
|
||||
assert!(s.len() <= N, "String is too long to fit!");
|
||||
|
||||
todo!()
|
||||
}
|
||||
|
||||
pub async fn get_u16(&mut self, addr: u16) -> Result<u16> {
|
||||
let length = self.send_read_holding_request(addr, 1).await?;
|
||||
assert_eq!(
|
||||
length, 2,
|
||||
"Expected modbus device to send exactly 2 bytes of data!"
|
||||
);
|
||||
|
||||
self.read_u16().await
|
||||
}
|
||||
|
||||
pub async fn get_u32(&mut self, addr: u16) -> Result<u32> {
|
||||
let length = self.send_read_holding_request(addr, 2).await?;
|
||||
assert_eq!(
|
||||
length, 4,
|
||||
"Expected modbus device to send exactly 4 bytes of data!"
|
||||
);
|
||||
|
||||
let buf = self.read_bytes::<4>().await?;
|
||||
Ok(u32::from_be_bytes(buf))
|
||||
}
|
||||
|
||||
// We have to send the request in a single packet,
|
||||
// otherwise the device may fail to respond correctly.
|
||||
async fn send(&mut self, packet: Packet) -> Result<()> {
|
||||
self.stream
|
||||
.write_all(packet.as_bytes())
|
||||
.await
|
||||
.context("Could write to modbus device!")
|
||||
}
|
||||
|
||||
async fn read_u8(&mut self) -> Result<u8> {
|
||||
let buf = self.read_bytes::<1>().await?;
|
||||
Ok(u8::from_be_bytes(buf))
|
||||
}
|
||||
|
||||
async fn read_u16(&mut self) -> Result<u16> {
|
||||
let buf = self.read_bytes::<2>().await?;
|
||||
Ok(u16::from_be_bytes(buf))
|
||||
}
|
||||
|
||||
async fn read_bytes<const N: usize>(&mut self) -> Result<[u8; N]> {
|
||||
let mut buf = [0; N];
|
||||
self.stream
|
||||
.read_exact(&mut buf)
|
||||
.await
|
||||
.context("Could not read from modbus device!")?;
|
||||
Ok(buf)
|
||||
}
|
||||
}
|
||||
@@ -1 +0,0 @@
|
||||
pub mod mutation;
|
||||
@@ -1,14 +1,10 @@
|
||||
use std::{any::Any, sync::Arc};
|
||||
/*use std::{any::Any, sync::Arc};
|
||||
|
||||
use smol::{channel::Sender, lock::RwLock};
|
||||
use smol::lock::RwLock;
|
||||
use std::fmt::Debug;
|
||||
|
||||
use crate::{
|
||||
machines::identification::DeviceIdentification, serial::serial_detection::SerialDeviceRemoval,
|
||||
};
|
||||
use crate::machines::identification::DeviceIdentification;
|
||||
|
||||
pub mod panic;
|
||||
pub mod registry;
|
||||
pub mod serial_detection;
|
||||
|
||||
pub trait SerialDevice: Any + Send + Sync + SerialDeviceNew + Debug {}
|
||||
@@ -27,11 +23,11 @@ pub trait SerialDeviceThread {
|
||||
|
||||
pub struct SerialDeviceNewParams {
|
||||
pub path: String,
|
||||
pub device_thread_panic_tx: Sender<SerialDeviceRemoval<String>>,
|
||||
}
|
||||
|
||||
#[derive(PartialEq, Eq, Clone, Debug)]
|
||||
#[derive(PartialEq, Eq, Clone, Debug, Hash)]
|
||||
pub struct SerialDeviceIdentification {
|
||||
pub vendor_id: u16,
|
||||
pub product_id: u16,
|
||||
}
|
||||
*/
|
||||
@@ -1,53 +0,0 @@
|
||||
use smol::channel::Sender;
|
||||
|
||||
use crate::serial::serial_detection::SerialDeviceRemoval;
|
||||
|
||||
/// Device-level panic handler for individual device crashes
|
||||
/// Sends device identifier and error information for cleanup
|
||||
/// Used by serial devices and other individual components that need to be removed on panic
|
||||
pub fn send_serial_device_panic<T>(
|
||||
device_identifier: T,
|
||||
thread_panic_tx: Sender<SerialDeviceRemoval<T>>,
|
||||
) where
|
||||
T: Send + Sync + Clone + 'static,
|
||||
{
|
||||
// Ensure backtrace is enabled for panics
|
||||
if std::env::var("RUST_BACKTRACE").is_err() {
|
||||
unsafe {
|
||||
std::env::set_var("RUST_BACKTRACE", "full");
|
||||
}
|
||||
}
|
||||
|
||||
std::panic::set_hook(Box::new(move |panic_info| {
|
||||
let thread_name = std::thread::current()
|
||||
.name()
|
||||
.unwrap_or("unnamed")
|
||||
.to_string();
|
||||
let location = panic_info.location().map_or("unknown".to_string(), |loc| {
|
||||
format!("{}:{}:{}", loc.file(), loc.line(), loc.column())
|
||||
});
|
||||
let message = panic_info
|
||||
.payload()
|
||||
.downcast_ref::<&str>()
|
||||
.unwrap_or(&"Box<dyn Any>")
|
||||
.to_string();
|
||||
|
||||
let panic_message = format!(
|
||||
"Device panicked in thread '{}' at {}: {}",
|
||||
thread_name, location, message
|
||||
);
|
||||
|
||||
// Send device panic info through channel
|
||||
smol::block_on(async {
|
||||
let _ = thread_panic_tx
|
||||
.send(SerialDeviceRemoval::Error(
|
||||
device_identifier.clone(),
|
||||
anyhow::anyhow!("{}", panic_message),
|
||||
))
|
||||
.await;
|
||||
});
|
||||
|
||||
// Note: We don't call old_hook to avoid duplicate logging
|
||||
// All logging is handled in the main thread when receiving panic details
|
||||
}));
|
||||
}
|
||||
@@ -7,194 +7,70 @@
|
||||
*/
|
||||
|
||||
use serialport::{SerialPortInfo, SerialPortType, UsbPortInfo};
|
||||
use smol::{
|
||||
channel::{Receiver, Sender, unbounded},
|
||||
lock::RwLock,
|
||||
};
|
||||
use std::{collections::HashMap, sync::Arc};
|
||||
use std::collections::HashMap;
|
||||
|
||||
use crate::{
|
||||
helpers::compare_lists::compare_lists, machines::identification::DeviceIdentification,
|
||||
};
|
||||
use super::SerialDeviceIdentification;
|
||||
/// Handles scanning and caching of connected USB serial devices.
|
||||
pub struct SerialDetection {}
|
||||
|
||||
use super::{
|
||||
SerialDevice, SerialDeviceIdentification, SerialDeviceNewParams, registry::SerialDeviceRegistry,
|
||||
};
|
||||
|
||||
pub enum SerialDeviceRemoval<T> {
|
||||
Disconnect(T),
|
||||
Error(T, anyhow::Error),
|
||||
}
|
||||
|
||||
pub struct SerialDetection<'serialdeviceregistry> {
|
||||
pub serial_device_registry: &'serialdeviceregistry SerialDeviceRegistry,
|
||||
pub ports: HashMap<
|
||||
String,
|
||||
(
|
||||
UsbPortInfo,
|
||||
DeviceIdentification,
|
||||
Arc<RwLock<dyn SerialDevice>>,
|
||||
),
|
||||
>,
|
||||
pub device_removal_signal_rx: Receiver<SerialDeviceRemoval<String>>,
|
||||
pub device_removal_signal_tx: Sender<SerialDeviceRemoval<String>>,
|
||||
}
|
||||
|
||||
impl<'serialdeviceregistry> SerialDetection<'serialdeviceregistry> {
|
||||
pub fn new(serial_device_registry: &'serialdeviceregistry SerialDeviceRegistry) -> Self {
|
||||
let (device_removal_signal_tx, device_removal_signal_rx) = unbounded();
|
||||
SerialDetection {
|
||||
serial_device_registry,
|
||||
ports: HashMap::new(),
|
||||
device_removal_signal_rx,
|
||||
device_removal_signal_tx,
|
||||
impl SerialDetection {
|
||||
/// Returns all serial ports on the system (minus macOS "cu" noise).
|
||||
fn get_ports() -> Vec<SerialPortInfo> {
|
||||
match serialport::available_ports() {
|
||||
Ok(ports) => ports
|
||||
.into_iter()
|
||||
.filter(|port| !port.port_name.contains("cu"))
|
||||
.collect(),
|
||||
Err(_) => Vec::new(),
|
||||
}
|
||||
}
|
||||
|
||||
/*
|
||||
*@return: Option::None if there are no available ports on device
|
||||
*@return: Option::Some(Vec) with all available ports
|
||||
*
|
||||
*@description: detects all available ports and returns them as list
|
||||
*/
|
||||
fn get_ports() -> Vec<SerialPortInfo> {
|
||||
let all = match serialport::available_ports() {
|
||||
Ok(ports) => ports,
|
||||
Err(_) => return Vec::new(),
|
||||
};
|
||||
|
||||
// exclude ports that contai "cu" in their name
|
||||
all.into_iter()
|
||||
.filter(|port| !port.port_name.contains("cu"))
|
||||
.collect::<Vec<_>>()
|
||||
}
|
||||
|
||||
/* @param: port_list -> list of available ports
|
||||
*
|
||||
* @return: Vec<(String, UsbPortInfo)> -> list of ports with their names and usb information
|
||||
*
|
||||
* @description: This function extracts the USB serial devices from the given list of ports.
|
||||
*/
|
||||
fn extract_usb_serial_devices(
|
||||
&self,
|
||||
port_list: Vec<SerialPortInfo>,
|
||||
) -> Vec<(String, UsbPortInfo)> {
|
||||
let mut usb_ports: Vec<(String, UsbPortInfo)> = Vec::new();
|
||||
/// Extracts only USB serial devices from the port list.
|
||||
fn extract_usb_serial_devices(port_list: Vec<SerialPortInfo>) -> HashMap<String, UsbPortInfo> {
|
||||
let mut map = HashMap::new();
|
||||
|
||||
for port in port_list {
|
||||
if let SerialPortType::UsbPort(usb_info) = &port.port_type {
|
||||
usb_ports.push((port.port_name.to_string(), usb_info.clone()));
|
||||
};
|
||||
if let SerialPortType::UsbPort(usb_info) = port.port_type {
|
||||
map.insert(port.port_name, usb_info);
|
||||
}
|
||||
}
|
||||
|
||||
usb_ports
|
||||
map
|
||||
}
|
||||
|
||||
pub async fn check_ports(&mut self) -> CheckPortsResult {
|
||||
// get available ports
|
||||
/// Scans for connected USB serial devices and updates the internal map.
|
||||
/// Returns a clone of the map for quick access.
|
||||
pub fn detect_devices() -> HashMap<String, UsbPortInfo> {
|
||||
let ports = Self::get_ports();
|
||||
|
||||
// extract all ports that are usb ports
|
||||
let usb_ports = self.extract_usb_serial_devices(ports);
|
||||
|
||||
let last_usb_ports = self
|
||||
.ports
|
||||
.iter()
|
||||
.map(|last_usb_port| (last_usb_port.0.clone(), last_usb_port.1.0.clone()))
|
||||
.collect::<Vec<_>>();
|
||||
|
||||
let usb_ports_diff = compare_lists(&last_usb_ports, &usb_ports);
|
||||
|
||||
let mut result = CheckPortsResult {
|
||||
added: Vec::new(),
|
||||
removed: Vec::new(),
|
||||
};
|
||||
|
||||
// reamove ports
|
||||
for removed in usb_ports_diff.removed {
|
||||
if let Some((_, device_identification, _)) = self.ports.remove(&removed.0) {
|
||||
result.removed.push(device_identification);
|
||||
}
|
||||
|
||||
tracing::trace!("Removed port: {}", removed.0);
|
||||
}
|
||||
|
||||
// add new ports
|
||||
for added in usb_ports_diff.added {
|
||||
// add the port to the list
|
||||
let serial_device_identification = SerialDeviceIdentification {
|
||||
vendor_id: added.1.vid,
|
||||
product_id: added.1.pid,
|
||||
};
|
||||
|
||||
let device_result = self.serial_device_registry.new_serial_device(
|
||||
&SerialDeviceNewParams {
|
||||
path: added.0.clone(),
|
||||
device_thread_panic_tx: self.device_removal_signal_tx.clone(),
|
||||
},
|
||||
&serial_device_identification,
|
||||
);
|
||||
|
||||
// only if created device driver sucessfully
|
||||
if let Ok((device_identification, device)) = device_result {
|
||||
// add the device to the ports list
|
||||
self.ports.insert(
|
||||
added.0.clone(),
|
||||
(
|
||||
added.1.clone(),
|
||||
device_identification.clone(),
|
||||
device.clone(),
|
||||
),
|
||||
);
|
||||
|
||||
// add to result list
|
||||
result.added.push((device_identification, device.clone()));
|
||||
|
||||
tracing::trace!("Added port: {}", added.0);
|
||||
}
|
||||
}
|
||||
|
||||
result
|
||||
let usb_devices = Self::extract_usb_serial_devices(ports);
|
||||
usb_devices
|
||||
}
|
||||
|
||||
pub async fn check_remove_signals(&mut self) -> Vec<DeviceIdentification> {
|
||||
let mut removed_signals: Vec<DeviceIdentification> = Vec::new();
|
||||
pub fn device_port_exists(device_path: &str) -> bool {
|
||||
let ports = Self::get_ports();
|
||||
return ports.iter().any(|p| p.port_name == device_path);
|
||||
}
|
||||
|
||||
let mut add_removal_signal = |path: &String| {
|
||||
if let Some(info) = self.ports.get(path) {
|
||||
removed_signals.push(info.1.clone());
|
||||
};
|
||||
self.ports.remove(path);
|
||||
};
|
||||
|
||||
if self.device_removal_signal_rx.is_empty() {
|
||||
return removed_signals;
|
||||
}
|
||||
|
||||
let removal = self
|
||||
.device_removal_signal_rx
|
||||
.recv()
|
||||
.await
|
||||
.expect("Failed to receive removal signals");
|
||||
|
||||
match removal {
|
||||
SerialDeviceRemoval::Disconnect(path) => {
|
||||
add_removal_signal(&path);
|
||||
tracing::trace!("Removed serial device after disconnect: {:?}", path);
|
||||
}
|
||||
|
||||
SerialDeviceRemoval::Error(path, error) => {
|
||||
add_removal_signal(&path);
|
||||
tracing::error!("Removed erroring serial device: {:?}: {}", path, error);
|
||||
pub fn device_id_exists(sdevid: SerialDeviceIdentification) -> bool {
|
||||
let ports = Self::get_ports();
|
||||
for port in ports {
|
||||
if let SerialPortType::UsbPort(usb_info) = port.port_type {
|
||||
if usb_info.vid == sdevid.vendor_id && usb_info.pid == sdevid.product_id {
|
||||
return true;
|
||||
}
|
||||
}
|
||||
}
|
||||
return false;
|
||||
}
|
||||
|
||||
removed_signals
|
||||
pub fn get_path_by_id(
|
||||
sdevid: SerialDeviceIdentification,
|
||||
map: HashMap<String, UsbPortInfo>,
|
||||
) -> Option<String> {
|
||||
for (port, usbport) in map.iter() {
|
||||
if usbport.vid == sdevid.vendor_id && usbport.pid == sdevid.product_id {
|
||||
return Some(port.clone());
|
||||
}
|
||||
}
|
||||
return None;
|
||||
}
|
||||
}
|
||||
|
||||
#[derive(Debug)]
|
||||
pub struct CheckPortsResult {
|
||||
pub added: Vec<(DeviceIdentification, Arc<RwLock<dyn SerialDevice>>)>,
|
||||
pub removed: Vec<DeviceIdentification>,
|
||||
}
|
||||
@@ -1,3 +1,2 @@
|
||||
pub mod event;
|
||||
pub mod namespace;
|
||||
pub mod namespace_id;
|
||||
@@ -4,7 +4,7 @@ use socketioxide::extract::SocketRef;
|
||||
use std::{collections::HashMap, sync::Arc, time::Duration};
|
||||
use tracing::instrument;
|
||||
|
||||
#[derive(Debug)]
|
||||
#[derive(Debug, Clone)]
|
||||
pub struct Namespace {
|
||||
pub sockets: Vec<SocketRef>,
|
||||
pub events: HashMap<String, Vec<Arc<GenericEvent>>>,
|
||||
@@ -118,7 +118,6 @@ impl Namespace {
|
||||
) {
|
||||
// cache the event
|
||||
self.cache(event.clone(), buffer_fn);
|
||||
|
||||
// emit the event - inlined from emit function
|
||||
// Send to global queue for each socket in the namespace
|
||||
for socket in self.sockets.clone() {
|
||||
@@ -168,7 +167,7 @@ impl Namespace {
|
||||
|
||||
impl Drop for Namespace {
|
||||
fn drop(&mut self) {
|
||||
self.disconnect_all();
|
||||
//self.disconnect_all();
|
||||
}
|
||||
}
|
||||
|
||||
|
||||
@@ -1,4 +1,4 @@
|
||||
use uom::si::{
|
||||
use units::{
|
||||
angle::radian,
|
||||
angular_velocity::radian_per_second,
|
||||
f64::{Angle, AngularVelocity, Length, Velocity},
|
||||
|
||||
@@ -1,7 +0,0 @@
|
||||
unit! {
|
||||
system: uom::si;
|
||||
quantity: uom::si::acceleration;
|
||||
|
||||
@meter_per_minute_per_second: 0.016_666_666_666_666_67; "m/min/s", "meters per minute per second",
|
||||
"meters per minute per second";
|
||||
}
|
||||
@@ -1,7 +0,0 @@
|
||||
unit! {
|
||||
system: uom::si;
|
||||
quantity: uom::si::angular_acceleration;
|
||||
|
||||
@revolution_per_minute_per_second: 0.104_719_755_119_659_77; "rev/min/s", "revolutions per minute per second",
|
||||
"revolutions per minute per second";
|
||||
}
|
||||
@@ -1,7 +0,0 @@
|
||||
unit! {
|
||||
system: uom::si;
|
||||
quantity: uom::si::angular_jerk;
|
||||
|
||||
@revolution_per_minute_per_second_squared: 0.104_719_755_119_659_77; "rev/min/s²", "revolution per minute per second squared",
|
||||
"revolution per minute per second squared";
|
||||
}
|
||||
@@ -1,7 +0,0 @@
|
||||
unit! {
|
||||
system: uom::si;
|
||||
quantity: uom::si::jerk;
|
||||
|
||||
@meter_per_minute_per_second_squared: 0.016_666_666_666_666_666_67; "m/min/s²", "meters per minute per second squared",
|
||||
"meters per minute per second squared";
|
||||
}
|
||||
@@ -1,5 +0,0 @@
|
||||
pub mod acceleration;
|
||||
pub mod angular_acceleration;
|
||||
pub mod angular_jerk;
|
||||
pub mod jerk;
|
||||
pub mod velocity;
|
||||
@@ -1,7 +0,0 @@
|
||||
unit! {
|
||||
system: uom::si;
|
||||
quantity: uom::si::velocity;
|
||||
|
||||
@meter_per_minute: 0.016_666_666_666_666_67; "m/min", "meters per minute",
|
||||
"meters per minute";
|
||||
}
|
||||

|
After Width: | Height: | Size: 29 KiB |

|
After Width: | Height: | Size: 4.2 MiB |

|
After Width: | Height: | Size: 557 KiB |

|
After Width: | Height: | Size: 110 KiB |

|
After Width: | Height: | Size: 108 KiB |

|
After Width: | Height: | Size: 51 KiB |

|
After Width: | Height: | Size: 102 KiB |

|
After Width: | Height: | Size: 4.2 MiB |

|
After Width: | Height: | Size: 212 KiB |

|
After Width: | Height: | Size: 1.4 MiB |

|
After Width: | Height: | Size: 2.1 MiB |

|
After Width: | Height: | Size: 32 KiB |

|
After Width: | Height: | Size: 68 KiB |

|
After Width: | Height: | Size: 6.6 MiB |

|
After Width: | Height: | Size: 72 KiB |

|
After Width: | Height: | Size: 5.2 MiB |

|
After Width: | Height: | Size: 4.3 MiB |

|
After Width: | Height: | Size: 28 KiB |

|
After Width: | Height: | Size: 29 KiB |

|
After Width: | Height: | Size: 37 KiB |

|
After Width: | Height: | Size: 5.9 MiB |

|
After Width: | Height: | Size: 203 KiB |

|
After Width: | Height: | Size: 74 KiB |

|
After Width: | Height: | Size: 83 KiB |

|
After Width: | Height: | Size: 5.4 MiB |

|
After Width: | Height: | Size: 5.9 MiB |

|
After Width: | Height: | Size: 1.3 MiB |

|
After Width: | Height: | Size: 2.2 MiB |

|
After Width: | Height: | Size: 66 KiB |

|
After Width: | Height: | Size: 2.3 MiB |

|
After Width: | Height: | Size: 2.0 MiB |

|
After Width: | Height: | Size: 2.1 MiB |

|
After Width: | Height: | Size: 30 KiB |

|
After Width: | Height: | Size: 47 KiB |

|
After Width: | Height: | Size: 40 KiB |

|
After Width: | Height: | Size: 2.4 MiB |

|
After Width: | Height: | Size: 2.3 MiB |

|
After Width: | Height: | Size: 2.5 MiB |

|
After Width: | Height: | Size: 206 KiB |

|
After Width: | Height: | Size: 38 KiB |

|
After Width: | Height: | Size: 39 KiB |

|
After Width: | Height: | Size: 55 KiB |

|
After Width: | Height: | Size: 74 KiB |
@@ -0,0 +1,139 @@
|
||||
# XTREM Communication Protocol
|
||||
|
||||
**Version:** 3.007
|
||||
**Device:** XTREM / XTREM-S Weighing Module
|
||||
**Standard:** OIML R76:2006 / EN45501:2015 compliant
|
||||
|
||||
---
|
||||
|
||||
## Overview
|
||||
|
||||
The **XTREM communication protocol** allows a terminal or host controller to exchange data and commands with the XTREM weighing module.
|
||||
The device transmits and receives ASCII-coded frames over a serial interface (RS232, RS485, Wi-Fi, or Ethernet, depending on configuration).
|
||||
|
||||
Since we are using the Ethernet interface we need to provide some kind of DHCP to assign an IP - Address to each XTREM Device.
|
||||
They then may be addressed via a **broadcast** IP (e.g.: 192.168.4.255/24).
|
||||
A **Unicast** communication is applied through the device ID inside the XTREM Frame.
|
||||
|
||||
---
|
||||
|
||||
## Frame Structure
|
||||
|
||||
Each message—both query and response—has the same format:
|
||||
|
||||
```
|
||||
STX ID_O ID_D F D_ADDRESS D_L DATA LRC ETX
|
||||
```
|
||||
|
||||
| Field | Description | Length (bytes) |
|
||||
| :------------ | :------------------------------------------------ | :------------: |
|
||||
| **STX** | Start of message (ASCII `02h`) | 1 |
|
||||
| **ID_O** | Sender address (2 ASCII hex chars) | 2 |
|
||||
| **ID_D** | Destination address (2 ASCII hex chars) | 2 |
|
||||
| **F** | Function code (`R`, `W`, `E`, etc.) | 1 |
|
||||
| **D_ADDRESS** | Data address (register, 4 ASCII hex chars) | 4 |
|
||||
| **D_L** | Data length (2 ASCII hex chars) | 2 |
|
||||
| **DATA** | Optional data field | Variable |
|
||||
| **LRC** | Longitudinal Redundancy Check (2 ASCII hex chars) | 2 |
|
||||
| **ETX** | End of message (ASCII `03h`) | 1 |
|
||||
|
||||
In the default configuration the Frame also requires a CRLF at the end.
|
||||
|
||||
**Example:**
|
||||
|
||||
```
|
||||
STX ‘1’ ‘7’ ‘0’ ‘1’ ‘R’ ‘0’ ‘1’ ‘0’ ‘1’ ‘0’ ‘0’ LRC ETX CR LF
|
||||
```
|
||||
|
||||
---
|
||||
|
||||
## Function Codes
|
||||
|
||||
| Function | ASCII | Hex | Description |
|
||||
| :------- | :---- | :---| :-------------- |
|
||||
| **R** | R | 52h | Read request |
|
||||
| **r** | r | 72h | Read response |
|
||||
| **W** | W | 57h | Write request |
|
||||
| **w** | w | 77h | Write response |
|
||||
| **E** | E | 45h | Execute command |
|
||||
| **e** | e | 65h | Execute response|
|
||||
|
||||
### Write response codes
|
||||
|
||||
* `'0'` – OK
|
||||
* `'1'` – Write denied (sealed)
|
||||
* `'2'` – Read-only register
|
||||
* `'3'` – Invalid value / out of range
|
||||
|
||||
### Execute response codes
|
||||
|
||||
* `'0'` – Executed successfully
|
||||
* `'1'` – Blocked by seal switch
|
||||
|
||||
---
|
||||
|
||||
## LRC Calculation
|
||||
|
||||
The **Longitudinal Redundancy Check** is a one-byte XOR of all message bytes, excluding:
|
||||
|
||||
* `STX`
|
||||
* `ETX`
|
||||
* The LRC itself
|
||||
|
||||
Example C function:
|
||||
|
||||
```c
|
||||
unsigned char LRC(unsigned char* s) {
|
||||
unsigned char lrc = 0;
|
||||
while (*s) {
|
||||
lrc ^= *(s++);
|
||||
}
|
||||
return lrc;
|
||||
}
|
||||
```
|
||||
|
||||
Example Rust function:
|
||||
```rust
|
||||
pub fn compute_lrc(data: &[u8]) -> u8 {
|
||||
data.iter().fold(0u8, |acc, &b| acc ^ b)
|
||||
}
|
||||
|
||||
```
|
||||
|
||||
---
|
||||
|
||||
## Key Data Registers
|
||||
|
||||
| Address (hex) | Description | Type | Notes |
|
||||
| :------------ | :------------------------- | :--: | :------------------------------------ |
|
||||
| **0000h** | Serial number | R | Factory-set |
|
||||
| **0001h** | Device ID | RW | Network address |
|
||||
| **0007h** | Hardware version | R | Read-only |
|
||||
| **0008h** | Software version | R | Read-only |
|
||||
| **0009h** | Sealing switch status | R | `0=UNLOCK`, `1=LOCK` |
|
||||
| **0010h** | Baud rate | RW | `0–4` → 9600–115200 baud |
|
||||
| **0013h** | Stream mode output rate | RW | Time in ms |
|
||||
| **0100h** | Device state | R | Status bits (power, Wi-Fi, ADC, etc.) |
|
||||
| **0101h** | Weight value | R | Gross weight |
|
||||
| **0102h** | Tare value | RE | Read/Execute |
|
||||
| **0103h** | Net weight | R | Gross − Tare |
|
||||
| **0110h** | ADC counts (instant) | R | Raw ADC data |
|
||||
| **0111h** | ADC counts (filtered) | R | Post-filter data |
|
||||
| **1010h** | Stop stream mode | E | Execute |
|
||||
| **1011h** | Start stream mode (weight) | E | Continuous output |
|
||||
| **9999h** | Device reset | E | Software reset |
|
||||
| **EEEEh** | Factory reset | E | Restores defaults |
|
||||
|
||||
---
|
||||
|
||||
## Post-Factory Reset Configuration
|
||||
|
||||
After performing a factory reset, several registers must be configured to ensure proper operation of the device.
|
||||
|
||||
Note: The unit may remain set to 'g' after a factory reset, but the values received may be in 'kg' depending on the device configuration.
|
||||
|
||||
The following registers should be reviewed and set as required:
|
||||
1. **Address: 0022 | Max (Max1) (scale maximum capacity)**
|
||||
The default value for this register may vary between devices (e.g., 60000 or 6000). Set this value to 6000 to ensure correct operation.
|
||||
2. **Address: 0023 | e (e1) (scale interval)**
|
||||
3. **Address: 0026 | Decimal position**
|
||||
@@ -82,3 +82,93 @@ git push
|
||||
# Recommended Editor Setup
|
||||
|
||||
We recommend you to use an Editor with rust-analyzer support like VSCode to speed up development and detect errors before compiling.
|
||||
|
||||
# Minimal Hardware Examples
|
||||
|
||||
To get started with actual hardware, check out these step-by-step tutorials:
|
||||
|
||||
- **[LED Control with EL2004](./minimal-example-el2004.md)** - Digital output control, the simplest possible hardware setup
|
||||
- **[Analog Input with EL3021](./minimal-example-el3021.md)** - Reading analog current measurements
|
||||
- **[Stepper Motor Control with EL7031-0030](./minimal-example-el7031-motor.md)** - Complete motor control integration with velocity control
|
||||
|
||||
These examples provide complete hardware wiring diagrams and software setup instructions.
|
||||
|
||||
|
||||
# More Docs
|
||||
|
||||
- [x] [Architecture & Data Flow](./docs/architecture-overview.md)
|
||||
|
||||
- [x] Example Winder V2
|
||||
|
||||
- [ ] Electron
|
||||
|
||||
- Folder Structure
|
||||
- Routing with TanStack Router
|
||||
- Design with Tailwind & Shadcn
|
||||
- ...
|
||||
|
||||
- [ ] Interfacing with Electron/Server
|
||||
|
||||
- [ ] SocketIO
|
||||
- Machine Namespace
|
||||
- Main Namespace
|
||||
- [ ] REST
|
||||
- Machine Mutations
|
||||
- Write Device Identification
|
||||
|
||||
- Server
|
||||
|
||||
- [x] [Threading](./docs/control-loop.md)
|
||||
- [x] [Logging](./docs/logging.md)
|
||||
- [ ] Control Loop Setup
|
||||
- Control Loop Thread
|
||||
- [ ] realtime
|
||||
- Maindevice
|
||||
- Group
|
||||
- Extracting Device Identifications
|
||||
- Identifying Groups
|
||||
- Validating Machines
|
||||
- Run Control Loop
|
||||
- [x] [Control Loop](./docs/control-loop.md)
|
||||
- [x] [Machine/Device Identification](./docs/identification.md)
|
||||
- [ ] Machines
|
||||
- When to create a new Machine?
|
||||
- Versioning
|
||||
- Code sharing
|
||||
- Creating/Validating a Machine
|
||||
- Validation
|
||||
- Configuration
|
||||
- [ ] Machine Implementation Guide
|
||||
- Link: How to create a Device
|
||||
- Link: How to create an Actor
|
||||
- Link: How to create a Machine
|
||||
- API (SocketIO + REST)
|
||||
- Creation/Validation Logic
|
||||
- Optional/Mandatory Devices
|
||||
- Validate Devices
|
||||
- Business Logic
|
||||
- Link: How to create Machine Abstraction (Like Traverse/Puller/...)
|
||||
- Forward `act` in winder.
|
||||
|
||||
- [ ] Control Core
|
||||
|
||||
- [x] [Actors](./docs/actors.md)
|
||||
- [ ] SocketIO
|
||||
- Namespaces & Caching
|
||||
- Joining leaving namespaces
|
||||
- NamespaceId
|
||||
- Caching
|
||||
- Serverside Caching
|
||||
- Clientside Caching
|
||||
- [ ] REST
|
||||
|
||||
- [x] Ethercat HAL
|
||||
|
||||
- [x] [Devices](./docs/devices.md)
|
||||
- [x] [Configuration (CoE)](./docs/coe.md)
|
||||
- [x] [IO](./docs/io.md)
|
||||
- [x] [PDO](./docs/pdo.md)
|
||||
|
||||
- [x] [Ethercat Basics](./docs/ethercat-basics.md)
|
||||
|
||||
- [x] [NixOS Operating System](./docs/nixos/README.md)
|
||||
@@ -0,0 +1,224 @@
|
||||
# Minimal Example — LED Control on the EL2004
|
||||
A complete hardware + software walkthrough
|
||||
|
||||
---
|
||||
|
||||
## Table of Contents
|
||||
1. [Introduction](#1-introduction)
|
||||
2. [Requirements](#2-requirements)
|
||||
3. [Hardware Setup](#3-hardware-setup)
|
||||
4. [Software Setup](#4-software-setup)
|
||||
5. [Demo](#5-demo)
|
||||
6. [References](#6-references)
|
||||
7. [Acknowledgements](#7-acknowledgements)
|
||||
|
||||
---
|
||||
|
||||
## 1. Introduction
|
||||
|
||||
The EL2004 LED Toggle Example is a minimal demonstration showing how to control digital outputs on a **Beckhoff EL2004 EtherCAT terminal** using the QiTech machine framework.
|
||||
It represents the simplest possible hardware interaction in the system:
|
||||
**toggling LED outputs using the QiTech Control Dashboard.**
|
||||
|
||||
---
|
||||
|
||||
## 2. Requirements
|
||||
|
||||
### Hardware
|
||||
- Beckhoff **EL2004 EtherCAT Terminal** (4-channel digital output)
|
||||
- Beckhoff **EK1100 EtherCAT Coupler**
|
||||
- **24 V DC power supply** (AC/DC adapter + DC hollow plug)
|
||||
- Jumper / bridge wires (0.5–1.5 mm² recommended)
|
||||
- A **Linux PC** (Ubuntu/Debian recommended)
|
||||
- Standard Ethernet cable
|
||||
- Flat screwdriver
|
||||
|
||||
### Software
|
||||
*(Installation steps in Section 4)*
|
||||
- Rust toolchain
|
||||
- Node.js + npm
|
||||
- Git
|
||||
- QiTech Control repository
|
||||
- EtherCAT HAL (included inside repo)
|
||||
|
||||
---
|
||||
|
||||
## 3. Hardware Setup
|
||||
|
||||
### 3.1 Schematic
|
||||
|
||||

|
||||
|
||||
---
|
||||
|
||||
### 3.2 EK1100 Wiring
|
||||
|
||||
This wiring configuration powers the EL2004 and prepares it for LED control.
|
||||
It is not the only possible wiring but is the **simplest functional setup**.
|
||||
|
||||
#### ⚠️ Safety Warning
|
||||
Always disconnect power before wiring.
|
||||
Working on live EtherCAT terminals can cause serious damage or electrical shock.
|
||||
|
||||
---
|
||||
|
||||
#### 3.2.1 Safe Wiring Procedure (Beckhoff Recommended)
|
||||
|
||||
1. Insert a screwdriver **straight** into the square release hole.
|
||||
2. Insert the stripped wire into the round opening.
|
||||
3. Remove the screwdriver — the spring clamp locks the wire.
|
||||
|
||||

|
||||
|
||||
---
|
||||
|
||||
#### 3.2.2 Wiring Steps (Used in This Example)
|
||||
|
||||
We supply power using a **DC hollow-plug adapter**, like this one:
|
||||
https://www.amazon.de/dp/B093FTFZ8Q
|
||||
|
||||
Perform the following wiring on the EK1100:
|
||||
|
||||
1. Red wire **(+24 V)** → Terminal **2**
|
||||
2. Black wire **(0 V)** → Terminal **3**
|
||||
3. Jumper wire from **Terminal 1 → Terminal 6**
|
||||
4. Jumper wire from **Terminal 5 → Terminal 7**
|
||||
|
||||
After wiring, your module should look like **Figure 1**.
|
||||
|
||||
---
|
||||
|
||||
#### **Figure 1 — EK1100 Minimal Wiring**
|
||||
<img src="../assets/ek1100.jpeg" width="400">
|
||||
|
||||
|
||||
---
|
||||
|
||||
### 3.3 EL2004 Integration
|
||||
|
||||
Slide the EL2004 onto the **right side of the EK1100** until it locks.
|
||||
The EtherCAT E-Bus and power contacts connect automatically — **no wiring required**.
|
||||
|
||||
#### **Figure 2 — EL2004 Terminal**
|
||||
<img src="../assets/el2004.jpeg" width="400">
|
||||
|
||||
---
|
||||
|
||||
### 3.4 Final Assembled Setup
|
||||
|
||||
#### **Figure 3 — EK1100 + EL2004 Connected**
|
||||
<img src="../assets/complete.jpeg" width="400">
|
||||
|
||||
---
|
||||
|
||||
### 3.5 Power & Ethernet
|
||||
|
||||
#### Power
|
||||
Connect the 24 V adapter to the hollow plug used earlier.
|
||||
**Example AC/DC Adapter (Figure 4):**
|
||||
|
||||
<img src="../assets/adapter.jpeg" width="400">
|
||||
|
||||
|
||||
#### Ethernet
|
||||
Use a standard LAN cable to connect your PC → EK1100.
|
||||
The final powered up and connected setup should look like this:
|
||||
|
||||
<img src="../assets/power.jpeg" width="400">
|
||||
|
||||
---
|
||||
|
||||
## 4. Software Setup
|
||||
|
||||
### 4.1 Installing on Ubuntu/Debian
|
||||
|
||||
Paste this into your terminal:
|
||||
|
||||
```bash
|
||||
# Press Enter when prompted
|
||||
curl --proto '=https' --tlsv1.2 -sSf https://sh.rustup.rs | sh
|
||||
|
||||
sudo apt update
|
||||
sudo apt install -y npm nodejs git
|
||||
|
||||
git clone git@github.com:qitechgmbh/control.git
|
||||
cd control/electron
|
||||
npm install
|
||||
```
|
||||
### 4.2 Running the Backend
|
||||
```bash
|
||||
./cargo_run_linux.sh
|
||||
```
|
||||
This script:
|
||||
|
||||
- Builds the backend
|
||||
|
||||
- Grants required system capabilities (raw sockets)
|
||||
|
||||
- Starts EtherCAT communication
|
||||
|
||||
Ensure the EK1100 is connected.
|
||||
|
||||
### 4.3 Running the Frontend
|
||||
```bash
|
||||
cd electron
|
||||
npm run start
|
||||
```
|
||||
This launches the QiTech Control dashboard.
|
||||
|
||||
## 5. Demo
|
||||
|
||||
### 5.1 Assigning Devices in the Dashboard
|
||||
|
||||
Once the backend + frontend are running, you should see:
|
||||
|
||||
- EK1100 Coupler
|
||||
|
||||
- EL2004 Digital Output Terminal
|
||||

|
||||
|
||||
Steps:
|
||||
|
||||
- Click Assign on the EK1100
|
||||
|
||||
- Select TestMachine V1
|
||||
|
||||

|
||||
|
||||
|
||||
- Enter a serial number (use the same for EK1100 + EL2004)
|
||||
|
||||

|
||||
|
||||
- Click Write
|
||||
|
||||
- Repeat for the EL2004
|
||||
|
||||
### 5.2 Testing LED Control
|
||||
Navigate to:
|
||||
|
||||
Machines → TestMachine
|
||||

|
||||
You will see this interface:
|
||||
|
||||

|
||||
|
||||
**You can now toggle the four digital outputs of the EL2004.**
|
||||
|
||||
## 6. References
|
||||
|
||||
This guide incorporates information from official Beckhoff documentation.
|
||||
All diagrams, product names, and figures belong to Beckhoff Automation GmbH & Co. KG and are used here solely for educational purposes.
|
||||
|
||||
Referenced Manuals
|
||||
|
||||
[Beckhoff EK1100 Documentation](https://download.beckhoff.com/download/Document/io/ethercat-terminals/ek110x_ek15xx_en.pdf)
|
||||
|
||||
[Beckhoff EL2004 Documentation](https://download.beckhoff.com/download/Document/io/ethercat-terminals/el20xx_el2124_de.pdf)
|
||||
|
||||
## 7. Acknowledgements
|
||||
|
||||
This tutorial is inspired by the clarity and educational quality of Beckhoff manuals.
|
||||
All wiring illustrations and hardware descriptions in this guide are provided for demonstration purposes only and do not replace official Beckhoff installation guidelines.
|
||||
|
||||
Special thanks to the QiTech engineering team for providing the backend architecture, EtherCAT HAL abstraction, and the TestMachine framework that makes this example possible.
|
||||
@@ -0,0 +1,178 @@
|
||||
# Minimal Example — Analog Input EL3021
|
||||
|
||||
## Table of Contents
|
||||
1. [Introduction](#1-introduction)
|
||||
2. [Requirements](#2-requirements)
|
||||
3. [Hardware Setup](#3-hardware-setup)
|
||||
4. [Software Setup](#4-software-setup)
|
||||
5. [Demo](#5-demo)
|
||||
6. [References](#6-references)
|
||||
|
||||
## 1. Introduction
|
||||
The EL3021 Analog Input example demonstrates how to measure analog current on a **Beckhoff EL3021 EtherCAT terminal** using the QiTech machine framework.
|
||||
|
||||
## 2. Requirements
|
||||
|
||||
### Hardware
|
||||
- Beckhoff **EL3021 EtherCAT Terminal** (1-channel analog input)
|
||||
- Beckhoff **EK1100 EtherCAT Coupler**
|
||||
- **24 V DC power supply** (AC/DC adapter + DC hollow plug)
|
||||
- **Adjustable DC power supply** (or any other means of producing 4-20mA DC @ <10V )
|
||||
- Jumper / bridge wires (0.5–1.5 mm² recommended)
|
||||
- A **Linux PC** (Ubuntu/Debian recommended)
|
||||
- Standard Ethernet cable
|
||||
- Flat screwdriver
|
||||
|
||||
## 3. Hardware Setup
|
||||
|
||||
### 3.1 Schematic
|
||||

|
||||
The 24V supply powers the EL2004, while the adjustable power supply generates the analog input signal for the EL3021.
|
||||
|
||||
#### ⚠️ Safety Warning
|
||||
Always disconnect power before wiring.
|
||||
Working on live EtherCAT terminals can cause serious damage or electrical shock.
|
||||
|
||||
### 3.2.1 Safe Wiring Procedure (Beckhoff Recommended)
|
||||
|
||||
1. Insert a screwdriver **straight** into the square release hole.
|
||||
2. Insert the stripped wire into the round opening.
|
||||
3. Remove the screwdriver — the spring clamp locks the wire.
|
||||
|
||||

|
||||
|
||||
---
|
||||
|
||||
### 3.2.2 Wiring Steps (Used in This Example)
|
||||
|
||||
We supply power using a **DC hollow-plug adapter**, like this one:
|
||||
https://www.amazon.de/dp/B093FTFZ8Q
|
||||
|
||||
Perform the following wiring on the EK1100:
|
||||
|
||||
1. Red wire **(+24 V)** → Terminal **2**
|
||||
2. Black wire **(0 V)** → Terminal **3**
|
||||
3. Jumper wire from **Terminal 1 → Terminal 6**
|
||||
4. Jumper wire from **Terminal 5 → Terminal 7**
|
||||
|
||||
After wiring, your module should look like **Figure 1**.
|
||||
|
||||
---
|
||||
|
||||
#### **Figure 1 — EK1100 Minimal Wiring**
|
||||
<img src="../assets/ek1100.jpeg" width="400">
|
||||
|
||||
|
||||
---
|
||||
|
||||
### 3.3 EL3021 Integration
|
||||
|
||||
Slide the EL3021 onto the **right side of the EK1100** until it locks.
|
||||
The EtherCAT E-Bus and power contacts connect automatically.
|
||||
Then you need to wire the adjustable power supply to the EL3021.
|
||||
|
||||
#### **Figure 2 — EL3021 Terminal**
|
||||
<img src="../assets/EL3021.jpg" width="400">
|
||||
|
||||
1. Wire ⊕ to **Terminal 1**
|
||||
2. Wire ⊖ to **Terminal 2**
|
||||
---
|
||||
|
||||
### 3.4 Final Assembled Setup
|
||||
|
||||
#### **Figure 3 — EK1100 + EL3021 Connected**
|
||||
<img src="../assets/EK1100+EL3021.jpg" width="400">
|
||||
|
||||
---
|
||||
|
||||
## 3.5 Power & Ethernet
|
||||
|
||||
### 3.5.1 Power
|
||||
Connect the 24 V adapter to the hollow plug used earlier.
|
||||
|
||||
#### Example AC/DC Adapter (Figure 4):
|
||||
|
||||
<img src="../assets/adapter.jpeg" width="400">
|
||||
|
||||
|
||||
### 3.5.2 Ethernet
|
||||
Use a standard LAN cable to connect your PC → EK1100.
|
||||
The final powered up and connected setup should look like this:
|
||||
|
||||
<img src="../assets/EL3021_power+eth.jpg" width="400">
|
||||
|
||||
---
|
||||
|
||||
## 4. Software Setup
|
||||
|
||||
### 4.1 Installing on Ubuntu/Debian
|
||||
|
||||
Paste this into your terminal:
|
||||
|
||||
```bash
|
||||
# Press Enter when prompted
|
||||
curl --proto '=https' --tlsv1.2 -sSf https://sh.rustup.rs | sh
|
||||
|
||||
sudo apt update
|
||||
sudo apt install -y npm nodejs git
|
||||
|
||||
git clone git@github.com:qitechgmbh/control.git
|
||||
cd control/electron
|
||||
npm install
|
||||
```
|
||||
### 4.2 Running the Backend
|
||||
```bash
|
||||
./cargo_run_linux.sh
|
||||
```
|
||||
This script:
|
||||
|
||||
- Builds the backend
|
||||
|
||||
- Grants required system capabilities (raw sockets)
|
||||
|
||||
- Starts EtherCAT communication
|
||||
|
||||
Ensure the EK1100 is connected.
|
||||
|
||||
### 4.3 Running the Frontend
|
||||
```bash
|
||||
cd electron
|
||||
npm run start
|
||||
```
|
||||
This launches the QiTech Control dashboard.
|
||||
|
||||
## 5. Demo
|
||||
|
||||
### 5.1 Assigning Devices in the Dashboard
|
||||
Once both backend and frontend are running, the Setup -> EtherCat page should look something like this:
|
||||

|
||||
Listing the EK1100 and the EL3021.
|
||||
|
||||
To assign the two devices to a machine, click "Assign" on both devices. This should open the following pop-up modal:
|
||||
|
||||
**EK1100**
|
||||

|
||||
1. Select "AnalogTest V1" under "Machine"
|
||||
2. Choose a serial number to uniquely identify the machine (1 in this example)
|
||||
3. Under "Device Role" select "0 - Bus Coupler"
|
||||
|
||||
**EL3021**
|
||||

|
||||
1. Select "AnalogTest V1" under "Machine"
|
||||
2. Use the same serial number you chose for the EK1100
|
||||
3. Under "Device Role" select "1 - EL3021"
|
||||
---
|
||||
The machine is now configured.
|
||||
A new Tab "AnalogTest" should appear in the right sidebar. Clicking that tab should show the machine control interface:
|
||||

|
||||
Results should show the current measured by the analog input - the current set on the adjustable power supply.
|
||||
|
||||
|
||||
## 6. References
|
||||
This guide incorporates information from official Beckhoff documentation.
|
||||
All diagrams, product names, and figures belong to Beckhoff Automation GmbH & Co. KG and are used here solely for educational purposes.
|
||||
|
||||
Referenced Manuals
|
||||
|
||||
[Beckhoff EK1100 Documentation](https://download.beckhoff.com/download/Document/io/ethercat-terminals/ek110x_ek15xx_en.pdf)
|
||||
[Beckhoff EL3021 Documentation](https://download.beckhoff.com/download/Document/io/ethercat-terminals/el30xx_de.pdf)
|
||||
@@ -0,0 +1,236 @@
|
||||
# Minimal Example — Beckhoff EL7031-0030 Stepper Motor Integration
|
||||
A complete hardware + software walkthrough
|
||||
|
||||
---
|
||||
|
||||
## Table of Contents
|
||||
1. [Introduction](#1-introduction)
|
||||
2. [Requirements](#2-requirements)
|
||||
3. [Hardware Setup](#3-hardware-setup)
|
||||
- [3.2 EK1100 Wiring](#32-ek1100-wiring)
|
||||
- [3.2.1 Safe Wiring Procedure](#321-safe-wiring-procedure-beckhoff-recommended)
|
||||
- [3.2.2 Wiring (EL7031-0030)](#322-wiring-el7031-0030)
|
||||
- [3.3 Safety Warning](#33--safety-warning)
|
||||
4. [Software Setup](#4-software-setup)
|
||||
- [4.1 Installing on Linux](#41-installing-on-linux-this-depends-on-your-distro)
|
||||
- [4.2 Running the Backend](#42-running-the-backend)
|
||||
- [4.3 Running the Frontend](#43-running-the-frontend)
|
||||
5. [Demo](#5-demo)
|
||||
- [5.1 Assigning Devices in the Dashboard](#51-assigning-devices-in-the-dashboard)
|
||||
6. [Documentation](#6-documentation)
|
||||
7. [Software Architecture](#7-software-architecture)
|
||||
|
||||
---
|
||||
|
||||
## 1. Introduction
|
||||
|
||||
This project documents the successful integration of a **Beckhoff EL7031-0030 Stepper Motor Terminal** into the QiTech control software stack.
|
||||
The goal was to control a 24V stepper motor via EtherCAT using a custom Rust backend and a React/Electron frontend.
|
||||
|
||||
---
|
||||
|
||||
## 2. Requirements
|
||||
|
||||
### Software
|
||||
- Rust toolchain
|
||||
- Node.js + npm
|
||||
- Git
|
||||
- QiTech Control repository
|
||||
- EtherCAT HAL (included inside repo)
|
||||
|
||||
### Hardware
|
||||
- **EtherCAT Master:** Linux PC
|
||||
- **Bus Coupler:** EtherCAT Beckhoff EK1100
|
||||
- **Stepper Driver:** Beckhoff EL7031-0030 (THIS IS DIFFERENT FROM EL7031)
|
||||
- **Motor:** Standard 4-wire Stepper Motor
|
||||
- **Power Supply:** 24V DC
|
||||
- **Ethernet Cable:** Standard Ethernet cable
|
||||
- **Wiring Tools:** Screwdriver, wires
|
||||
|
||||
---
|
||||
|
||||
## 3. Hardware Setup
|
||||
|
||||
### 3.2 EK1100 Wiring
|
||||
|
||||
This wiring configuration powers the EL7031-0030.
|
||||
It is not the only possible wiring but is the **simplest functional setup**.
|
||||
|
||||
#### ⚠️ Safety Warning
|
||||
Always disconnect power before wiring.
|
||||
Working on live EtherCAT terminals can cause serious damage or electrical shock.
|
||||
|
||||
---
|
||||
|
||||
#### 3.2.1 Safe Wiring Procedure (Beckhoff Recommended)
|
||||
|
||||
1. Insert a screwdriver **straight** into the square release hole.
|
||||
2. Insert the stripped wire into the round opening.
|
||||
3. Remove the screwdriver — the spring clamp locks the wire.
|
||||
|
||||

|
||||
|
||||
---
|
||||
|
||||
We supply power using a **DC hollow-plug adapter**, like this one:
|
||||
https://www.amazon.de/dp/B093FTFZ8Q
|
||||
|
||||
Perform the following wiring on the EK1100:
|
||||
|
||||
1. Red wire **(+24 V)** → Terminal **2**
|
||||
2. Black wire **(0 V)** → Terminal **3**
|
||||
3. Jumper wire from **Terminal 1 → Terminal 6**
|
||||
4. Jumper wire from **Terminal 5 → Terminal 7**
|
||||
|
||||
After wiring, your module should look like **Figure 1**.
|
||||
|
||||
---
|
||||
|
||||
#### **Figure 1 — EK1100 Minimal Wiring**
|
||||
<img src="../assets/ek1100.jpeg" width="400">
|
||||
|
||||
---
|
||||
|
||||
#### **Figure 2 — EL7031-0030 Terminal**
|
||||
|
||||
<img src="../assets/EL7031_0030.jpg" width="300">
|
||||
|
||||
Slide the EL7031-0030 onto the right side of the EK1100 until it locks.
|
||||
The EtherCAT E-Bus and power contacts connect automatically — **no wiring required**.
|
||||
|
||||
---
|
||||
|
||||
#### **Figure 3 — Motor**
|
||||
<img src="../assets/motor.jpg" width="300">
|
||||
|
||||
---
|
||||
|
||||
#### **Figure 4 — Motor Wiring**
|
||||
<img src="../assets/motor_wiring.jpg" width="300">
|
||||
|
||||
Now the motor is wired via the pins 4, 5, 12, 13 on the EL7031-0030.
|
||||
|
||||
---
|
||||
|
||||
#### **Figure 5 — EL7031 Integration Connected**
|
||||
|
||||
<img src="../assets/EL7031_0030_connected.jpg" width="400">
|
||||
|
||||
That's what the pin should look like.
|
||||
|
||||
---
|
||||
|
||||
### 3.2.2 Wiring (EL7031-0030)
|
||||
|
||||
**Crucial:** The EL7031 requires two power sources: E-Bus (side contacts) for logic, and Front Terminal (6 & 14) for motor power.
|
||||
|
||||
| Terminal Point | Function | Cable Color (Example) |
|
||||
| :------------- | :--------------- | :-------------------- |
|
||||
| **4** | Motor Coil A1 | Red |
|
||||
| **12** | Motor Coil A2 | Blue |
|
||||
| **5** | Motor Coil B1 | Green |
|
||||
| **13** | Motor Coil B2 | Black |
|
||||
| **6** | **Power +24V** | PSU Red (+) |
|
||||
| **14** | **Power 0V/GND** | PSU Black (-) |
|
||||
|
||||
---
|
||||
|
||||
### 3.3 ⚠️ Safety Warning
|
||||
|
||||
- **Mandatory Power Supply:** Without 24V connected to **Pin 6 (+24V)** and **Pin 14 (GND)**, the terminal will remain in `PREOP` state or show a "Warning" LED (No Power). The motor will **not** move without this external supply.
|
||||
|
||||
#### Risk of Destruction (Short Circuit):
|
||||
- **Never** connect the 24V Power Supply to the Motor Output pins (**4, 5, 12, 13**). This will instantly destroy the terminal (causing pins 12 & 13 to glow red/burn).
|
||||
- Ensure strict separation: **Pins 4/5/12/13 are for the MOTOR ONLY**.
|
||||
- **Pins 6/14 are for POWER ONLY**.
|
||||
|
||||
Also, see the documentation of the EtherCAT terminal ([EL7031-0030](https://download.beckhoff.com/download/document/io/ethercat-terminals/el7031-0030de.pdf)) for the different power modes (page 46 ff.)
|
||||
|
||||
---
|
||||
|
||||
## 4. Software Setup
|
||||
|
||||
### 4.1 Installing on Linux (this depends on your distro)
|
||||
|
||||
Paste this into your terminal:
|
||||
|
||||
```bash
|
||||
# Press Enter when prompted
|
||||
curl --proto '=https' --tlsv1.2 -sSf https://sh.rustup.rs | sh
|
||||
|
||||
sudo apt update
|
||||
sudo apt install -y npm nodejs git
|
||||
|
||||
git clone git@github.com:qitechgmbh/control.git
|
||||
cd control/electron
|
||||
npm install
|
||||
```
|
||||
|
||||
### 4.2 Running the Backend
|
||||
|
||||
```bash
|
||||
./cargo_run_linux.sh
|
||||
```
|
||||
|
||||
This script:
|
||||
- Builds the backend
|
||||
- Grants required system capabilities (raw sockets)
|
||||
- Starts EtherCAT communication
|
||||
|
||||
### 4.3 Running the Frontend
|
||||
|
||||
```bash
|
||||
# move to the control directory
|
||||
cd electron
|
||||
npm run start
|
||||
```
|
||||
|
||||
This launches the QiTech Control dashboard.
|
||||
|
||||
---
|
||||
|
||||
## 5. Demo
|
||||
|
||||
### 5.1 Assigning Devices in the Dashboard
|
||||
|
||||
Once the backend + frontend are running, you should see:
|
||||
|
||||

|
||||
|
||||
Make sure that under "Assign" → "Machine Assignment"
|
||||
the correct serial number is selected (each device should have the same one, here it is 1).
|
||||
Under "Machine" select your new Machine however you named it (I named it "TestMotor V1"), else it will detect that there is something connected to it but the connection won't work.
|
||||
|
||||

|
||||
|
||||
**NOW THE MOTOR SHOULD TURN!**
|
||||
|
||||
In the interface "TestMotor" on the left side, you can now control the motor (its state and its speed).
|
||||
|
||||

|
||||
|
||||
---
|
||||
|
||||
## 6. Documentation
|
||||
|
||||
Use the official documentation of the EL7031-0030 for more information:
|
||||
[Beckhoff EL7031-0030 Documentation](https://download.beckhoff.com/download/document/io/ethercat-terminals/el7031-0030de.pdf)
|
||||
|
||||
---
|
||||
|
||||
## 7. Software Architecture
|
||||
|
||||
### Backend (Rust)
|
||||
Located in [machines/src/motor_test_machine/](/machines/src/motor_test_machine/).
|
||||
|
||||
1. **`mod.rs`**: Defines the `MotorTestMachine` struct and holds the state (driver wrapper, enabled state, target velocity).
|
||||
2. **`api.rs`**: Handles incoming JSON commands from the frontend (Enable/Disable, Set Velocity) via WebSockets/SocketIO.
|
||||
3. **`act.rs`**: The real-time control loop. It updates the `StepperVelocityEL70x1` driver wrapper in every cycle based on the current state.
|
||||
4. **`new.rs`**: Initializes the hardware.
|
||||
|
||||
### Frontend (TypeScript/React)
|
||||
Located in [electron/src/machines/motor_test_machine/](/electron/src/machines/motor_test_machine/) and [electron/src/routes/routes.tsx](/electron/src/routes/routes.tsx).
|
||||
|
||||
1. **`useTestMotor.ts`**: Custom hook managing the optimistic state and communication with the backend.
|
||||
2. **`TestMotorControlPage.tsx`**: The UI using QiTech UI components (`ControlCard`, `EditValue`, `SelectionGroupBoolean`) to match the look and feel of the Winder2.
|
||||
3. **Routing**: Integrated into `routes.tsx` using TanStack Router, ensuring the machine appears in the sidebar and navigation works correctly.
|
||||
@@ -0,0 +1,196 @@
|
||||
# Minimal Example — Analog Input Wago 750-455
|
||||
|
||||
## Table of Contents
|
||||
1. [Introduction](#1-introduction)
|
||||
2. [Requirements](#2-requirements)
|
||||
3. [Hardware Setup](#3-hardware-setup)
|
||||
4. [Software Setup](#4-software-setup)
|
||||
5. [Demo](#5-demo)
|
||||
6. [References](#6-references)
|
||||
|
||||
## 1. Introduction
|
||||
The Wago 750-455 Analog Input example demonstrates how to measure analog current on a **Wago 750-455 EtherCAT module** using the QiTech machine framework. This module provides 4 independent analog input channels that can read 4-20mA signals.
|
||||
|
||||
## 2. Requirements
|
||||
|
||||
### Hardware
|
||||
- **Wago 750-354 EtherCAT Coupler**
|
||||
- **Wago 750-602 Power Supply** (24V VDC)
|
||||
- **Wago 750-455 EtherCAT Module** (4-channel analog input, 4-20mA)
|
||||
- **Wago 750-600 End Module**
|
||||
- **24 V DC power supply** for the Wago system
|
||||
- **Adjustable DC power supply** (or any other means of producing 4-20mA DC @ <10V)
|
||||
- Jumper / bridge wires (0.5–1.5 mm² recommended)
|
||||
- A **Linux PC** (Ubuntu/Debian recommended)
|
||||
- Standard Ethernet cable
|
||||
- Flat screwdriver
|
||||
|
||||
### Software
|
||||
*(Installation steps in Section 4)*
|
||||
- Rust toolchain
|
||||
- Node.js + npm
|
||||
- Git
|
||||
- QiTech Control repository
|
||||
- EtherCAT HAL (included inside repo)
|
||||
|
||||
## 3. Hardware Setup
|
||||
|
||||
### 3.1 Overview
|
||||
The Wago 750-455 is a 4-channel analog input module that measures current signals in the 4-20mA range. Each channel has its own input terminals and can operate independently.
|
||||
|
||||
#### ⚠️ Safety Warning
|
||||
Always disconnect power before wiring.
|
||||
Working on live EtherCAT modules can cause serious damage or electrical shock.
|
||||
|
||||
### 3.2 Wiring Procedure
|
||||
|
||||
#### 3.2.1 Safe Wiring (Wago Spring Clamp)
|
||||
1. Insert a screwdriver **straight** into the square release hole.
|
||||
2. Insert the stripped wire into the round opening.
|
||||
3. Remove the screwdriver — the spring clamp locks the wire.
|
||||
|
||||

|
||||
|
||||
---
|
||||
|
||||
### 3.3 Wago 750-455 Module Wiring
|
||||
|
||||
The Wago 750-455 has 4 analog input channels. Each channel requires two terminals:
|
||||
|
||||
**Channel 1 (AI1):**
|
||||
- Terminal 1: ⊕ (Positive input)
|
||||
- Terminal 2: ⊖ (Negative input/Ground)
|
||||
|
||||
**Channel 2 (AI2):**
|
||||
- Terminal 3: ⊕ (Positive input)
|
||||
- Terminal 4: ⊖ (Negative input/Ground)
|
||||
|
||||
**Channel 3 (AI3):**
|
||||
- Terminal 5: ⊕ (Positive input)
|
||||
- Terminal 6: ⊖ (Negative input/Ground)
|
||||
|
||||
**Channel 4 (AI4):**
|
||||
- Terminal 7: ⊕ (Positive input)
|
||||
- Terminal 8: ⊖ (Negative input/Ground)
|
||||
|
||||
For this minimal example, we'll connect at least one channel to an adjustable power supply:
|
||||
|
||||
1. Wire adjustable power supply ⊕ to **Terminal 1** (Channel 1 positive)
|
||||
2. Wire adjustable power supply ⊖ to **Terminal 2** (Channel 1 negative)
|
||||
|
||||
*Repeat for additional channels as needed.*
|
||||
|
||||
---
|
||||
|
||||
### 3.4 Wago I/O System Integration
|
||||
|
||||
The Wago 750-455 module plugs into a Wago fieldbus system. Consult your specific Wago controller/coupler documentation for:
|
||||
- Power supply requirements
|
||||
- Network configuration
|
||||
- Module placement in the I/O rack
|
||||
|
||||
The module automatically connects to the backplane for EtherCAT communication and power.
|
||||
|
||||
---
|
||||
|
||||
### 3.5 Power & Ethernet
|
||||
|
||||
#### Power
|
||||
Ensure your Wago system has adequate 24V DC power connected per manufacturer specifications.
|
||||
|
||||
#### Ethernet
|
||||
Connect your PC to the Wago controller/coupler using a standard Ethernet cable.
|
||||
|
||||
---
|
||||
|
||||
## 4. Software Setup
|
||||
|
||||
### 4.1 Installing on Ubuntu/Debian
|
||||
|
||||
Paste this into your terminal:
|
||||
|
||||
```bash
|
||||
# Press Enter when prompted
|
||||
curl --proto '=https' --tlsv1.2 -sSf https://sh.rustup.rs | sh
|
||||
|
||||
sudo apt update
|
||||
sudo apt install -y npm nodejs git
|
||||
|
||||
git clone git@github.com:qitechgmbh/control.git
|
||||
cd control/electron
|
||||
npm install
|
||||
```
|
||||
|
||||
### 4.2 Running the Backend
|
||||
|
||||
```bash
|
||||
./cargo_run_linux.sh
|
||||
```
|
||||
|
||||
This script:
|
||||
- Builds the backend
|
||||
- Grants required system capabilities (raw sockets)
|
||||
- Starts EtherCAT communication
|
||||
|
||||
Ensure the Wago controller is connected and powered.
|
||||
|
||||
### 4.3 Running the Frontend
|
||||
|
||||
```bash
|
||||
cd electron
|
||||
npm run start
|
||||
```
|
||||
|
||||
This launches the QiTech Control dashboard.
|
||||
|
||||
---
|
||||
|
||||
## 5. Demo
|
||||
|
||||
### 5.1 Assigning Devices in the Dashboard
|
||||
|
||||
Once both backend and frontend are running:
|
||||
|
||||
1. Navigate to **Setup → EtherCAT** page
|
||||
2. You should see your Wago controller and the 750-455 module listed
|
||||
3. Select the Device called 750-354 and assign the Wago AI Test V1 Machine, set the Serial to 1 and set the device role to 0 (Wago Bus Coupler)
|
||||
4. Press write thn restart the backend to load the changes
|
||||
|
||||
### 5.2 Testing Analog Input
|
||||
|
||||
1. Set your adjustable power supply to output a current in the 4-20mA range
|
||||
2. In the dashboard, navigate to the monitoring view
|
||||
3. Observe the analog input value for the connected channel(s)
|
||||
|
||||
### 5.3 Channel Specifications
|
||||
|
||||
The Wago 750-455 provides:
|
||||
- **Input Range:** 4-20mA
|
||||
- **Wiring Error Detection:** Built-in detection for open/short circuit conditions
|
||||
- **4 Independent Channels:** Each can be read separately
|
||||
|
||||
### 5.4 Error Detection
|
||||
|
||||
The module includes wiring error detection. If you see a wiring error flag:
|
||||
- Check that your current source is within the 4-20mA range
|
||||
- Verify all wire connections are secure
|
||||
- Ensure the current loop is properly closed
|
||||
|
||||
---
|
||||
|
||||
## 6. References
|
||||
|
||||
### Wago Documentation
|
||||
- [Wago 750-455 Product Page](https://www.wago.com/de-en/io-systems/4-channel-analog-input/p/750-455)
|
||||
- Wago I/O System manual
|
||||
- EtherCAT configuration guide for Wago systems
|
||||
|
||||
### QiTech Control
|
||||
- [Architecture Overview](../architecture-overview.md)
|
||||
- [EtherCAT Basics](../ethercat-basics.md)
|
||||
- [Device Documentation](../devices.md)
|
||||
- [Getting Started Guide](getting-started.md)
|
||||
|
||||
### Related Examples
|
||||
- [Minimal Example — EL3021](minimal-example-el3021.md) (Single channel analog input)
|
||||
- [Minimal Example — EL2004](minimal-example-el2004.md) (Digital output)
|
||||